

Spring-loaded inverted pendulum modeling improves neural network estimation of ground reaction forces
Bumjoon Kim1, Hyerim Lim1, Sukyung Park1
1Department of Mechanical Engineering, Korea Advanced Institute of Science and Technology (KAIST), Daejeon, Republic of Korea.

Abstract:
Inertial-measurement-unit (IMU)-based wearable gait-monitoring systems provide kinematic information but kinetic information, such as ground reaction force (GRF) are often needed to assess gait symmetry and joint loading. Recent studies have reported methods for predicting GRFs from IMU measurement data by using artificial neural networks (ANNs). To obtain reliable predictions, the ANN requires a large number of measurement inputs at the cost of wearable convenience. Recognizing that the dynamic relationship between the center of mass (CoM) and GRF can be well represented by using spring mechanics, in this study we propose two GRF prediction methods based on the implementation of walking dynamics in a neural network. Method 1 takes inputs to the network that were CoM kinematics data and Method 2 employs forces approximated from CoM kinematics by applying spring mechanics. The gait data of seven young healthy subjects were collected at various walking speeds. Leave-one-subject-out cross-validation was performed with normalized root mean square error and r as quantitative measures of prediction performance. The vertical and anteroposterior (AP) GRFs obtained using both methods agreed well with the experimental data, but Method 2 yielded improved predictions of AP GRF compared to Method 1 (p = 0.005). These results imply that knowledge of the dynamic characteristics of walking, combined with a neural network, could enhance the efficiency and accuracy of GRF prediction and help resolve the tradeoff between information richness and wearable convenience of wearable technologies.


Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
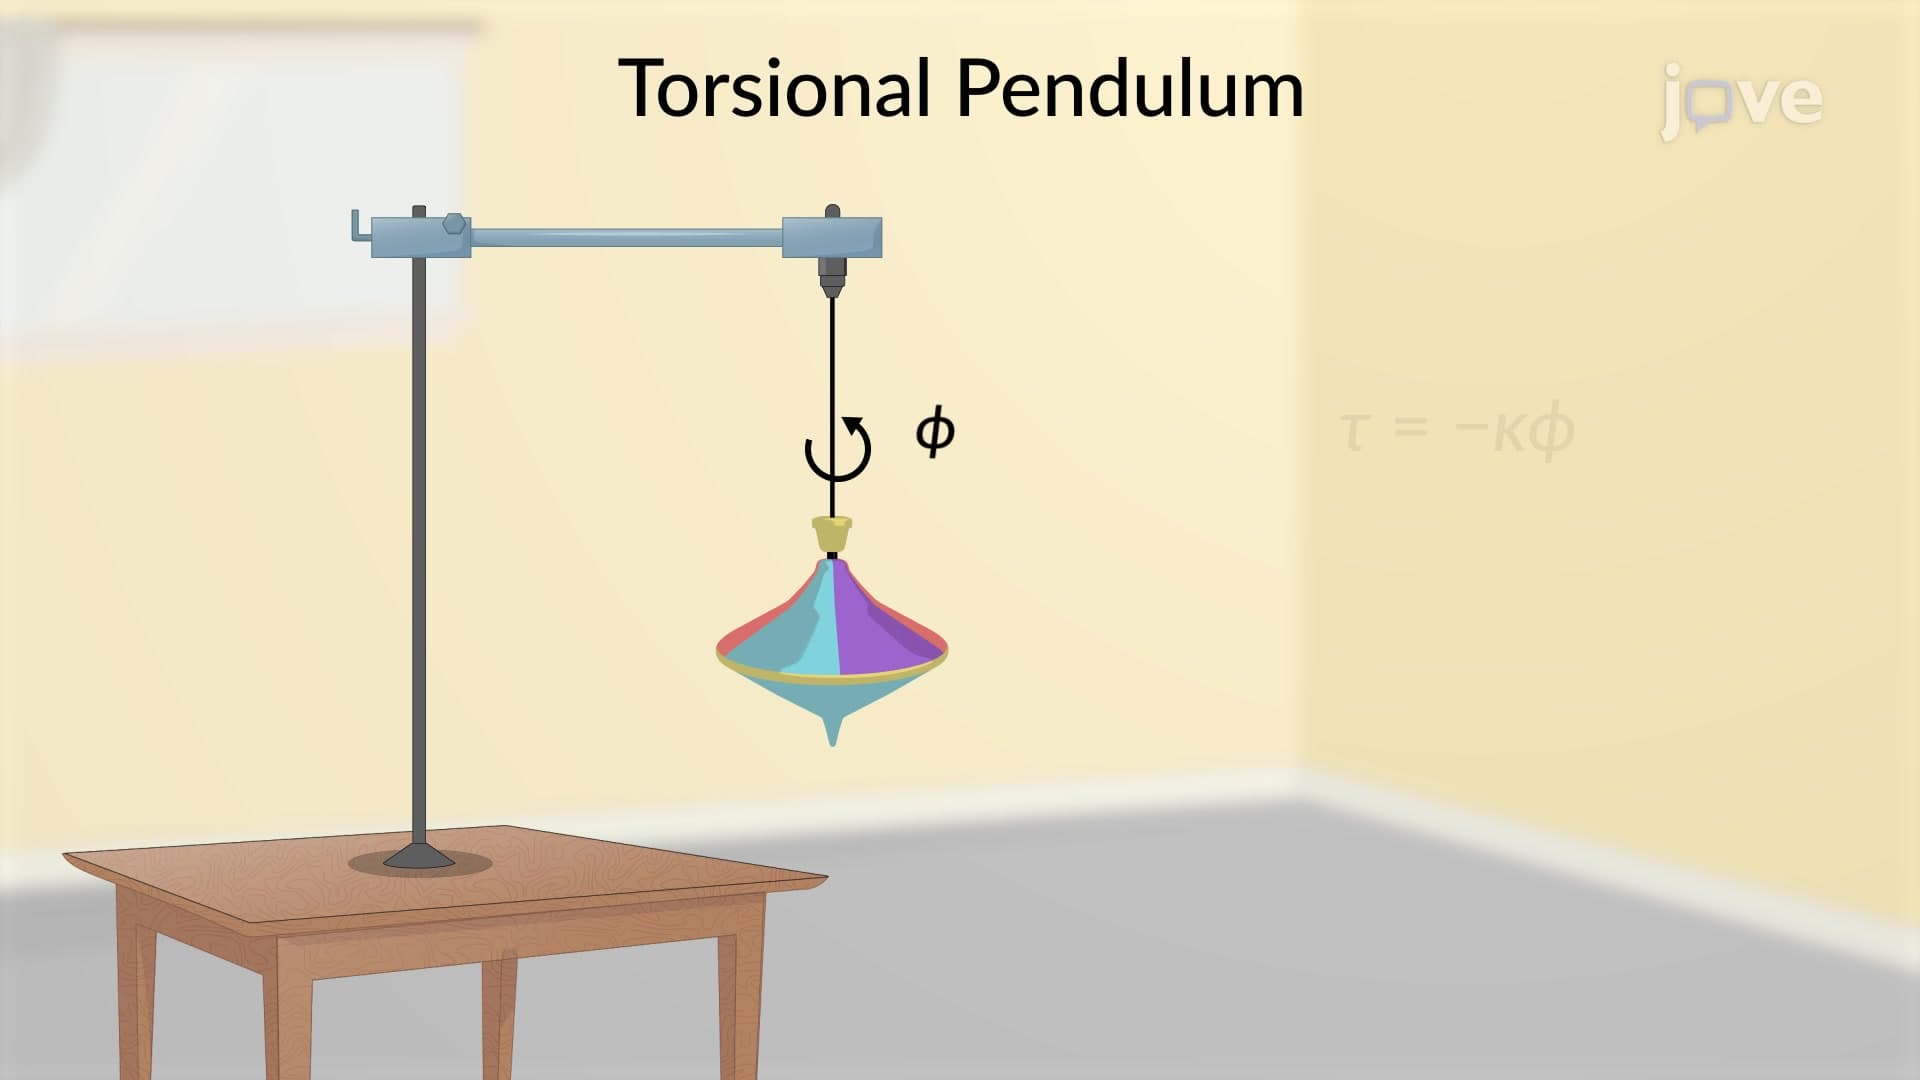
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:06
Forced Oscillations