Related Experiment Video
Updated: Dec 1, 2025

Using Virtual Reality to Transfer Motor Skill Knowledge from One Hand to Another
Published on: September 18, 2017
Motor learning affects car-to-driver handover in automated vehicles
Holly E B Russell1, Lene K Harbott2, Ilana Nisky3
1Department of Mechanical Engineering, Stanford University, Stanford, CA 94305, USA.

Abstract:
Vehicles in the foreseeable future will be required to transition between autonomous driving (without human involvement) and full human control. During this transition period, the human, who has not been actively engaged in the driving process, must resume the motor control necessary to steer the car. The in-car study presented here demonstrates that when human drivers are presented with a steering behavior that is different from the last time they were in control, specifically the ratio of hand wheel angle to road wheel angle (emulating a change in vehicle speed), they undergo a significant period of adaptation before they return to their previous steering behavior. However, drivers do not require an adaptation period to return to previous driving behavior after changes in steering torque. These findings have implications for the design of vehicles that transition from automated to manual driving and for understanding of human motor control in real-world tasks.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 00:46
Motor Units
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:11
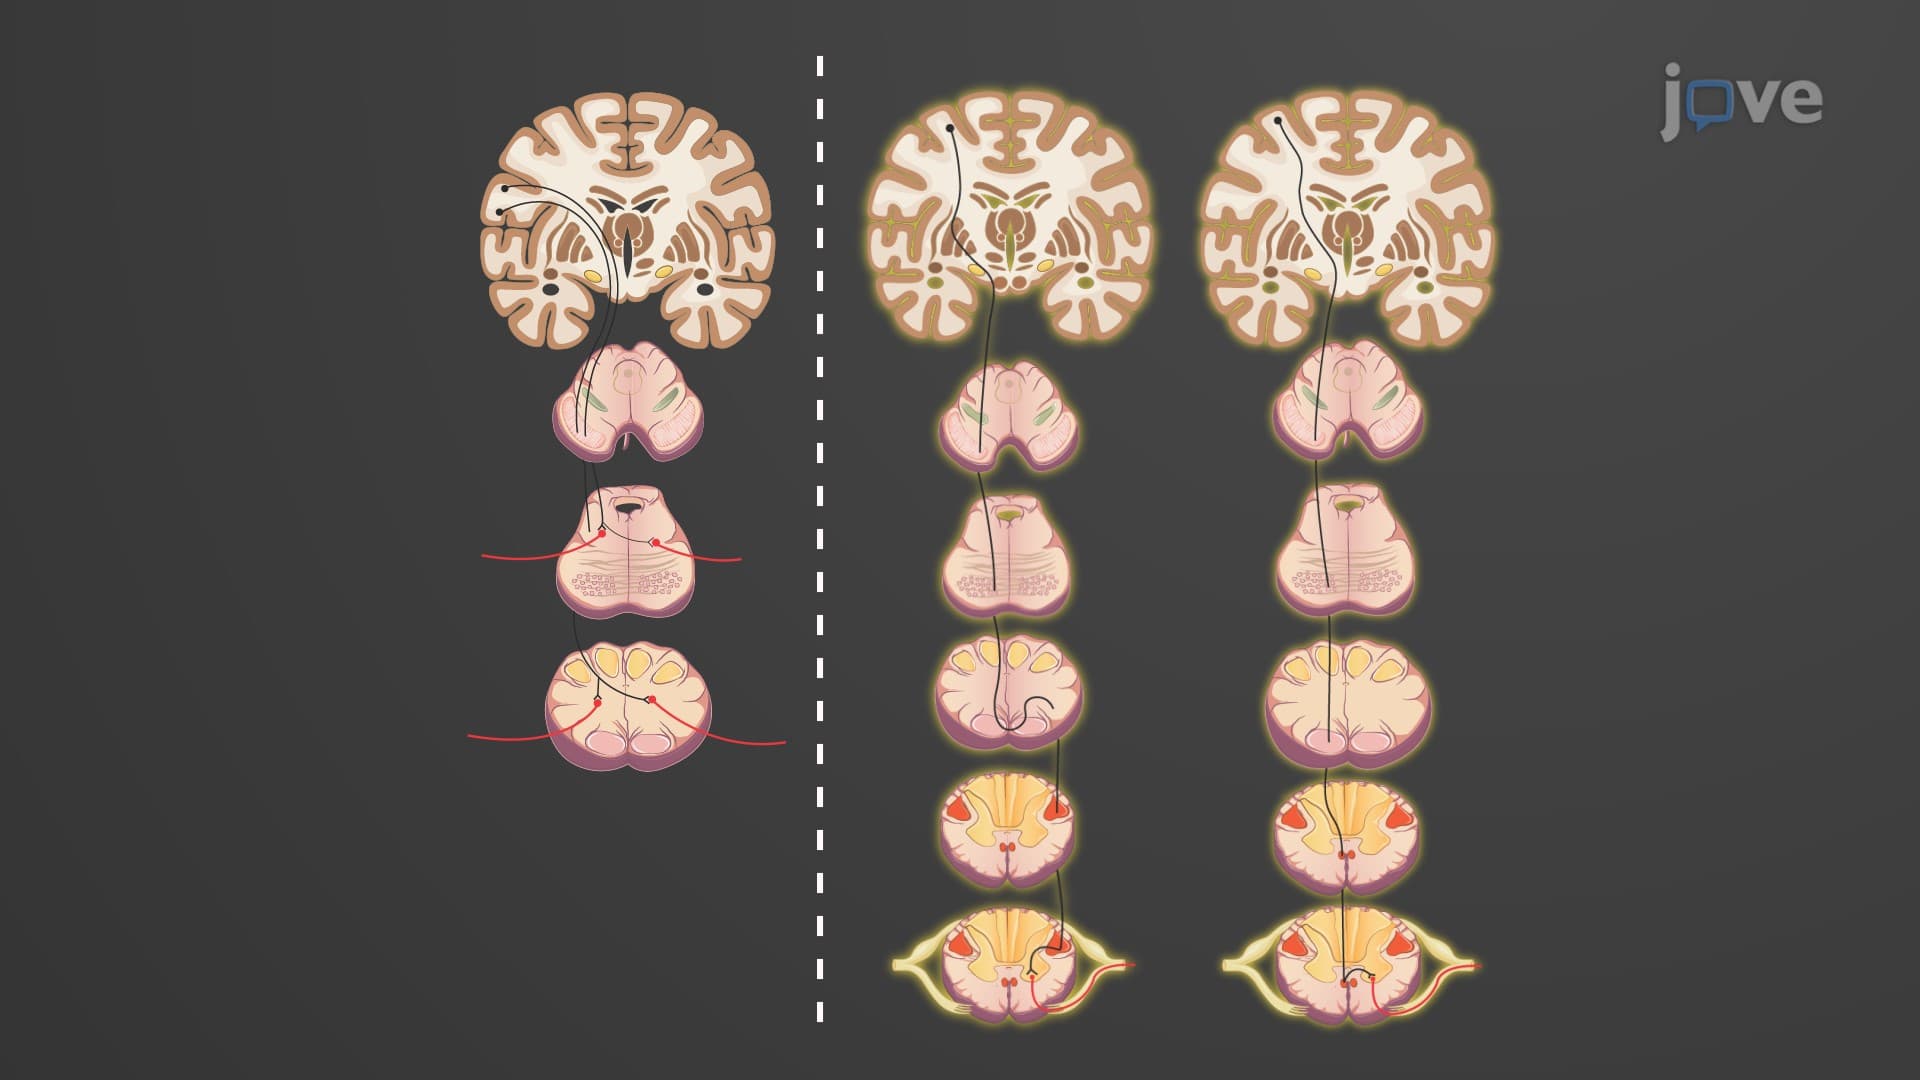
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...