Related Experiment Video
Updated: Dec 1, 2025

A View of Their Own: Capturing the Egocentric View of Infants and Toddlers with Head-Mounted Cameras
Published on: October 5, 2018
Limits of Object Persistence: Young Infants Perceive Continuity of Vertical and Horizontal Trajectories, But Not
J Gavin Bremner1, Alan M Slater2, Uschi C Mason1
1Lancaster University.

Abstract:
Previous research indicated that 4-month-old infants perceive continuity of objects moving on horizontal trajectories but appear to have difficulty processing occlusion events involving oblique trajectories. However, because perception of continuity of vertical trajectories has not been tested, it is uncertain whether this indicates a specific deficit for oblique trajectories or a specific advantage for horizontal trajectories. We evaluated the contribution of trajectory orientation and the form of occlusion in three experiments with one hundred and forty-four 4-month-olds. Infants perceived continuity of horizontal and vertical trajectories under all conditions presented. However, they did not perceive continuity of an oblique (45°) trajectory under any condition. Thus, 4-month-olds appear unable to process continuity of a 45° trajectory. In a fourth experiment with forty-eight 6- and 8-month-old infants, we demonstrated that by 6 months, infants' difficulty with oblique trajectories is overcome. We suggest that young infants' difficulty with markedly oblique trajectories likely relates to immature eye movement control.
Related Concept Videos
 01:12
Perceptual Constancy
Size constancy is the recognition that an object remains the same size, even when its image on the retina changes. For instance, a bus is perceived to be large enough to carry people, even if it looks tiny from...
 01:14
Piaget's Stage 1 of Cognitive Development
Exploration...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
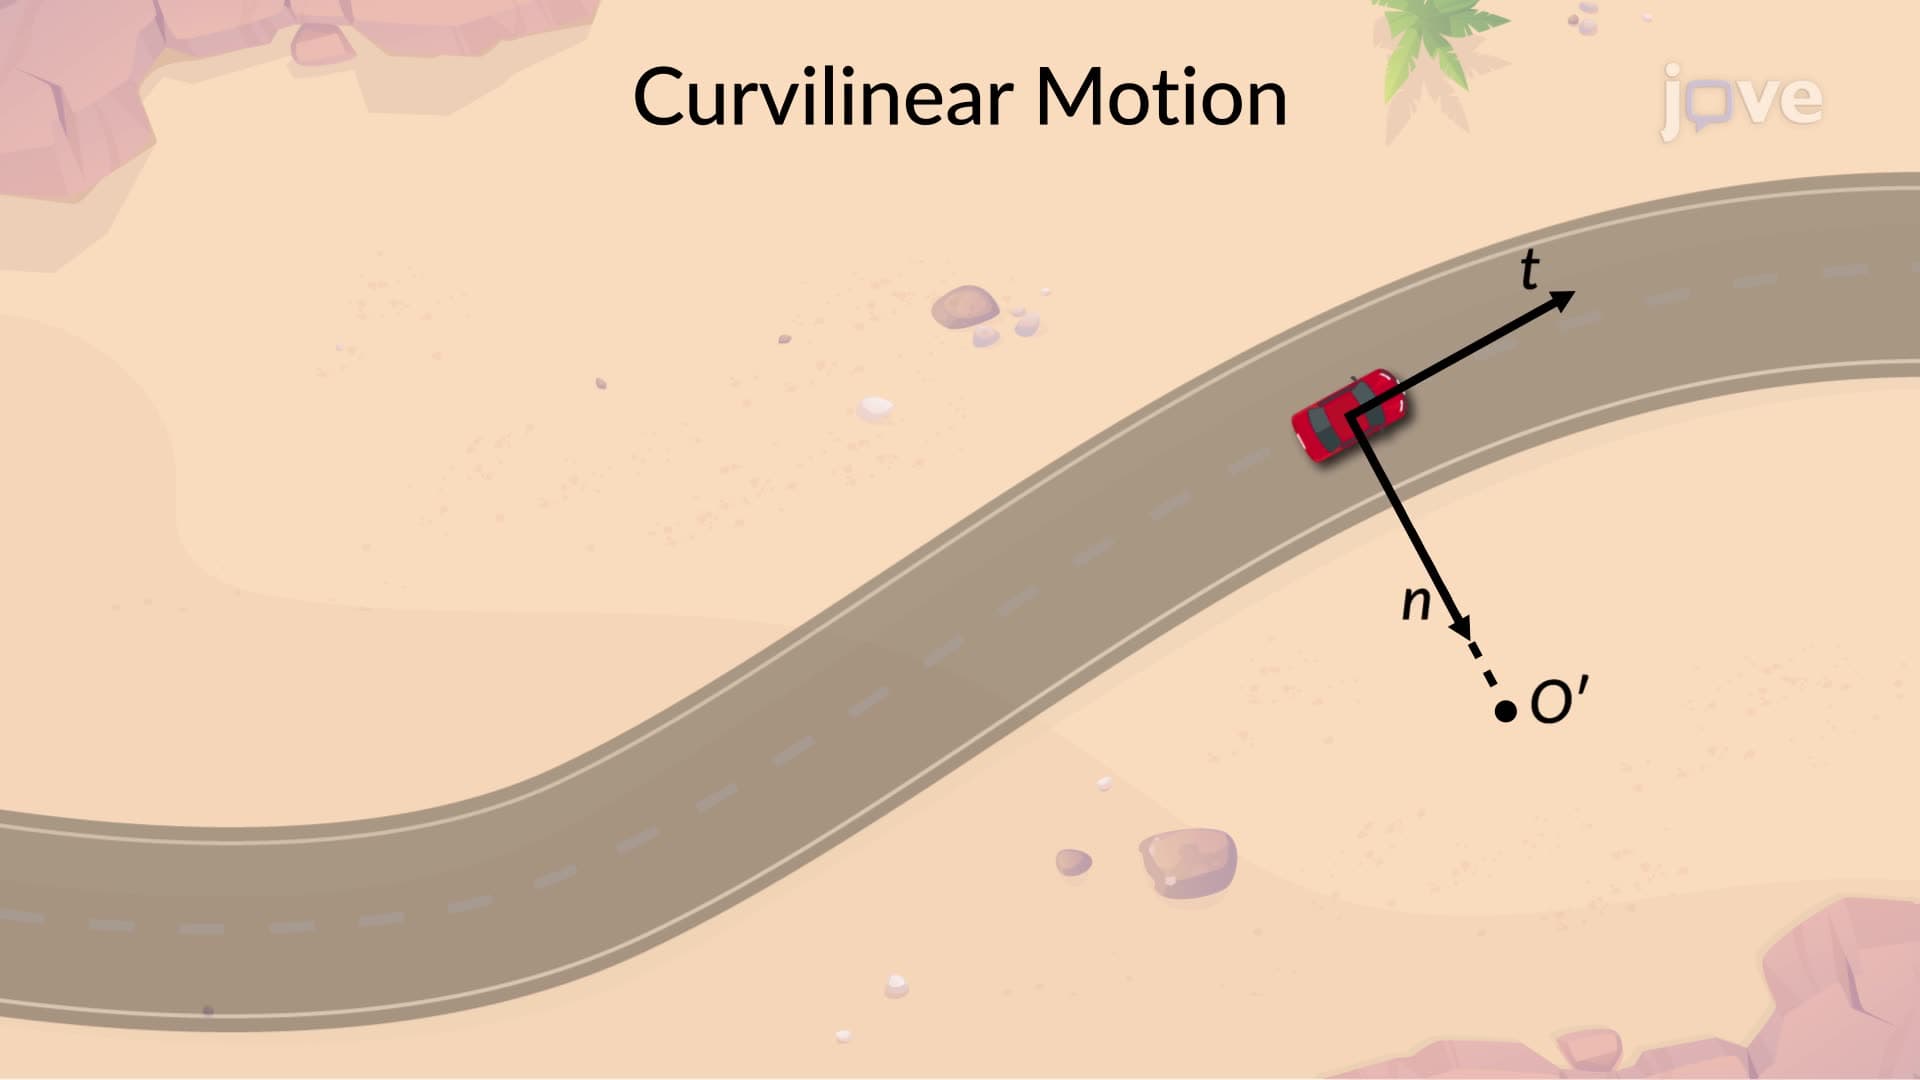
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:15
Depth Perception and Spatial Vision