Related Experiment Video
Updated: Nov 30, 2025


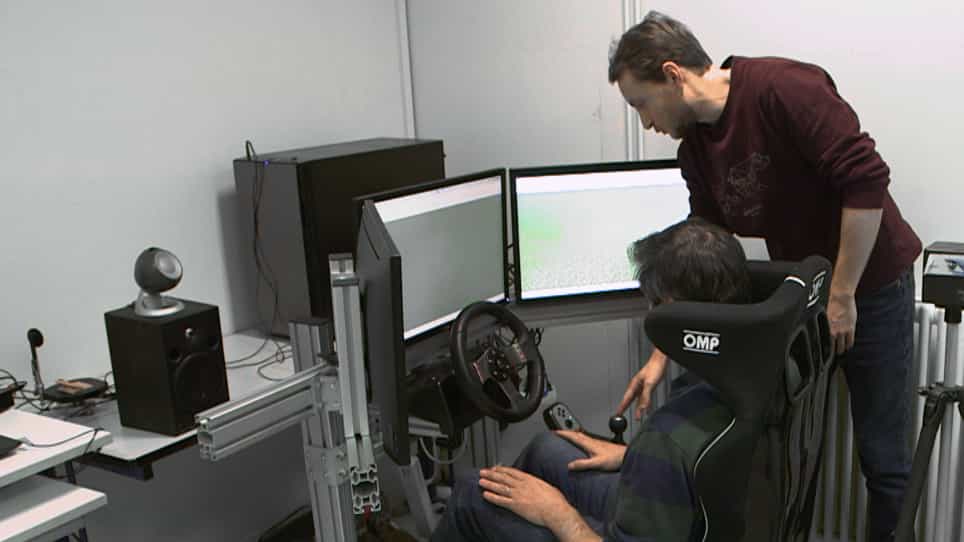
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Driver Characteristics Oriented Autonomous Longitudinal Driving System in Car-Following Situation
Haksu Kim1, Kyunghan Min2, Myoungho Sunwoo1
1Department of Automotive Engineering, Hanyang University, Seoul 04763, Korea.

Abstract:
Advanced driver assistance system such as adaptive cruise control, traffic jam assistance, and collision warning has been developed to reduce the driving burden and increase driving comfort in the car-following situation. These systems provide automated longitudinal driving to ensure safety and driving performance to satisfy unspecified individuals. However, drivers can feel a sense of heterogeneity when autonomous longitudinal control is performed by a general speed planning algorithm. In order to solve heterogeneity, a speed planning algorithm that reflects individual driving behavior is required to guarantee harmony with the intention of the driver. In this paper, we proposed a personalized longitudinal driving system in a car-following situation, which mimics personal driving behavior. The system is structured by a multi-layer framework composed of a speed planner and driver parameter manager. The speed planner generates an optimal speed profile by parametric cost function and constraints that imply driver characteristics. Furthermore, driver parameters are determined by the driver parameter manager according to individual driving behavior based on real driving data. The proposed algorithm was validated through driving simulation. The results show that the proposed algorithm mimics the driving style of an actual driver while maintaining safety against collisions with the preceding vehicle.
More Related Videos
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...