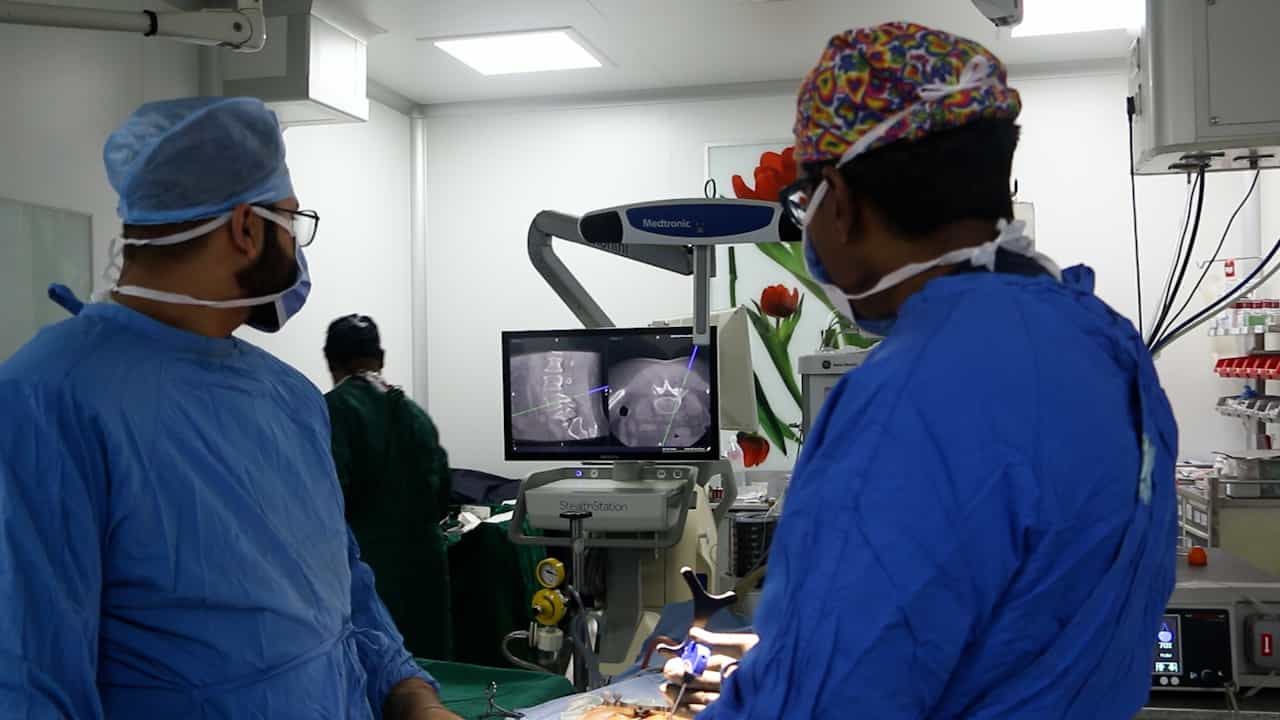
Related Experiment Video
Updated: Nov 29, 2025
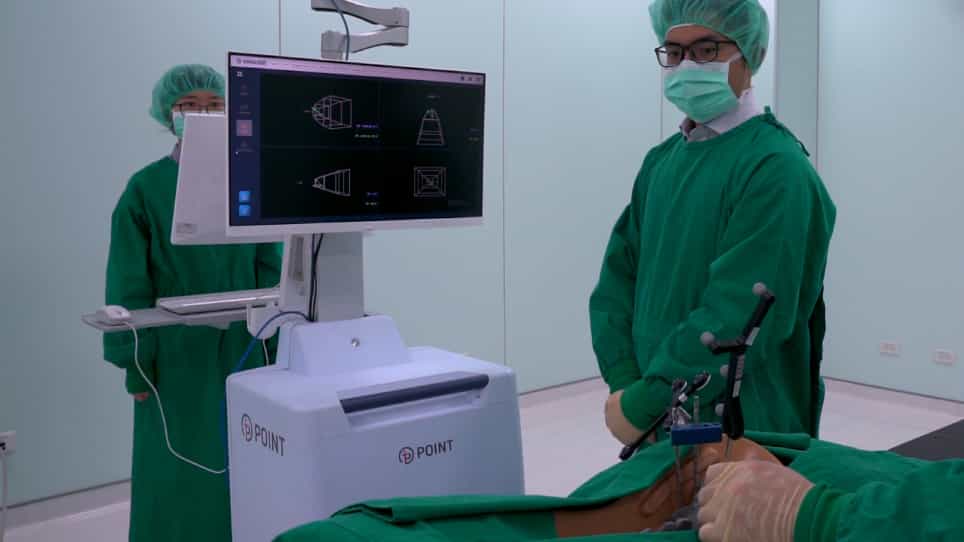

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Evaluation of a new spinal surgical robotic system of Kirschner wire placement for lumbar fusion: A multi-centre,
Junyu Li1, Lin Huang2, Wenyu Zhou3
1Department of Orthopedics, Peking University Third Hospital, Beijing, China.

Background:
To introduce a novel robotic system 'Orthbot' that has been developed and tested as a surgical assistant for auto-placement of the K-wire in lumbar fusion.
Methods:
This is a multi-centre, randomized controlled clinical study that includes 56 patients (robot group, RG: 27, free-hand group, FG: 29). Following the pre-operative planning and intra-operative fluoroscopic images, the 'Orthbot' automatically completed registration and K-wire placement under the supervision of the surgeon. Deviation distance (DD) and deviation angle (DA) were used as the primary parameters to evaluate the accuracy of the robotic system.
Results:
The average DD was 0.95 ± 0.377 mm and 4.35 ± 2.01 mm, respectively in the RG and FG (p < 0.001). The average DA of the K-wire in the coronal plane and the sagittal plane in X-Ray was respectively 6.80 ± 7.79° and 1.27 ± 2.32° in the RG (p < 0.001), and 22.22 ± 16.85° and 4.57 ± 3.86° in the FG (p < 0.001), which showed a higher accuracy rate in the robotic-assisted cases compared to the free-hand cases.
Conclusions:
The novel robotic system could achieve accurate K-wire insertions as indicated by the radiological results.