Related Experiment Video
Updated: Nov 28, 2025


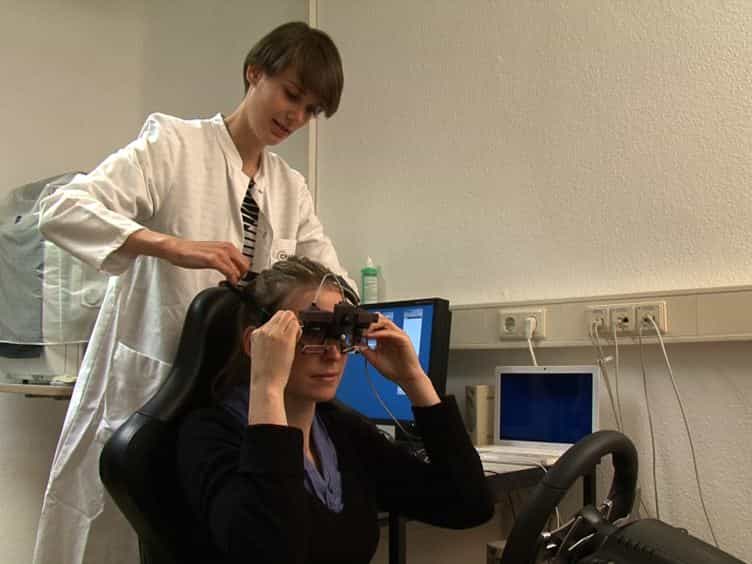
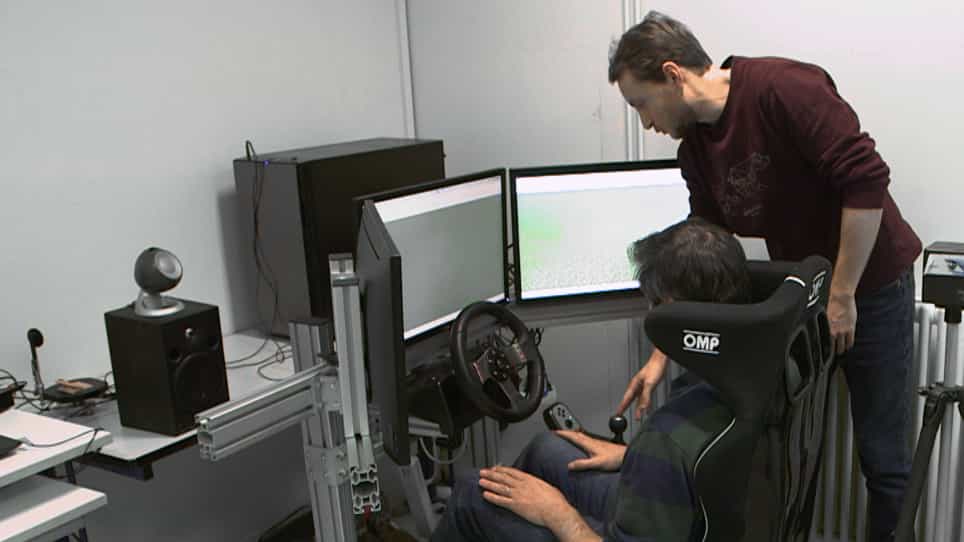
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Predicting takeover response to silent automated vehicle failures
Callum Mole1, Jami Pekkanen1,2, William Sheppard1
1School of Psychology, University of Leeds, Leeds, United Kingdom.

Abstract:
Current and foreseeable automated vehicles are not able to respond appropriately in all circumstances and require human monitoring. An experimental examination of steering automation failure shows that response latency, variability and corrective manoeuvring systematically depend on failure severity and the cognitive load of the driver. The results are formalised into a probabilistic predictive model of response latencies that accounts for failure severity, cognitive load and variability within and between drivers. The model predicts high rates of unsafe outcomes in plausible automation failure scenarios. These findings underline that understanding variability in failure responses is crucial for understanding outcomes in automation failures.
More Related Videos
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:25
Distribution Reliability and Automation
 01:28
Automatic Processing and Automatic Social Behavior
 01:16
Response Surface Methodology
The process of RSM involves several key steps:
 01:21
Distributed Loads: Problem Solving
 02:16
Stereotype Content Model