Related Experiment Video
Updated: Nov 27, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Information Theory in Formation Control: An Error Analysis to Multi-Robot Formation
Shuo Wan1, Jiaxun Lu1, Pingyi Fan1
1Tsinghua National Laboratory for Information Science and Technology (TNList), Department of Electronic Engineering, Tsinghua University, Beijing 100084, China.

Abstract:
Multi-robot formation control makes prerequisites for a team of robots to execute complex tasks cooperatively, which has been widely applied in both civilian and military scenarios. However, the limited precision of sensors and controllers may inevitably cause position errors in the finally achieved formation, which will affect the tasks undertaken. In this paper, the formation error is analyzed from the viewpoint of information theory. The desired position and the actually achieved position are viewed as two random variables. By calculating the mutual information between them, a lower bound of the formation error is derived. The results provide insights for the estimation of possible formation errors in the multi-robot system, which can assist designers to choose sensors and controllers with proper precision.


Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:10
Propagation of Uncertainty from Systematic Error
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:25
Transformers with Off-Nominal Turns Ratios
 01:21
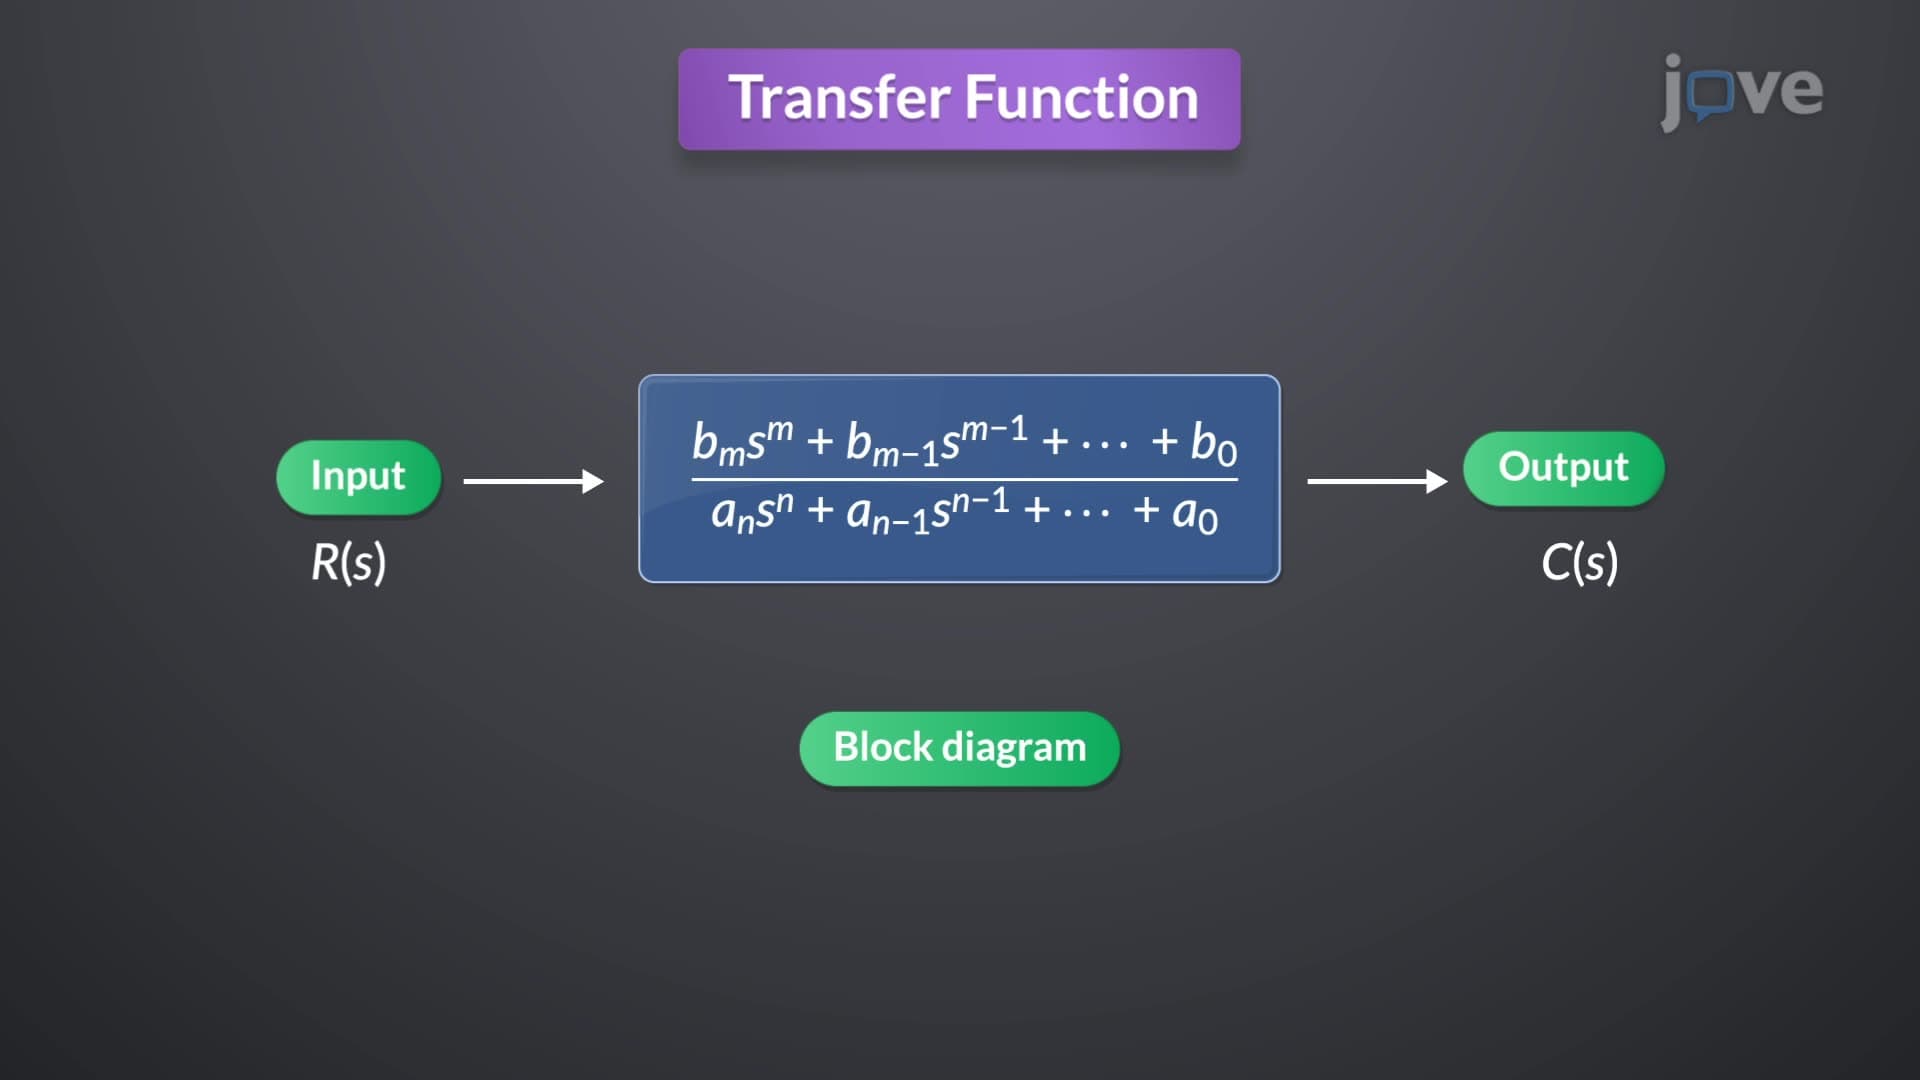
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...