Related Experiment Video
Updated: Nov 27, 2025

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
On obstacle avoidance path planning in unknown 3D environments: A fluid-based framework
Jianfa Wu1, Honglun Wang2, Menghua Zhang2
1School of Automation Science and Electrical Engineering, Beihang University, Beijing 100191, China; Shenyuan Honors College of Beihang University, Beijing 100191, China; Science and Technology on Aircraft Control Laboratory, Beihang University, Beijing 100191, China.

Abstract:
Compared with preprocessed obstacle environments, unknown environments are more challenging for path planning. In unknown environments, an agent can make decisions only by relying on the obstacle information detected by its onboard sensors. However, when facing non-convex obstacles, this limited detection information can easily trap the agent in a local optimum. In this paper, a nature-inspired methodology called Interfered Fluid Dynamic System (IFDS) is extended to anti-local-optimum obstacle avoidance in unknown 3D environments for the first time and a novel fluid-based path planning framework is proposed. First, the detection region of the agent is discretized. Then, spherical virtual obstacles (SVOs) located at detected discrete points are generated and memorized. Thus, obstacle avoidance in unknown environments is transformed into the avoidance of known SVOs. Next, the currently generated and memorized SVOs are input to the core of the framework, the IFDS algorithm, to produce repulsive effects, and the corresponding 3D avoidance path is resolved. On this basis, to address local optimum in cases with non-convex obstacles, and considering compatibility with the IFDS, the direction coefficient and sink-heading angular rate adjustment strategies, which belong to the same system as the IFDS, are introduced to modify the IFDS in this framework. Finally, receding horizon control is introduced to improve the obstacle avoidance performance. Simulations show that the proposed framework can enable the agent to autonomously jump out of the 3D non-convex obstacle environments with typical features of the local optimum, including wall-like and cave-like obstacles, and safely reach the destination.
More Related Videos
 06:28
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
 09:29
A Standardized Obstacle Course for Assessment of Visual Function in Ultra Low Vision and Artificial Vision
Published on: February 11, 2014
Related Concept Videos
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:18
Newtonian Fluid: Problem Solving
A velocity gradient forms within the fluid when a Newtonian fluid is placed between two parallel plates, with...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:09
Turbulent Flow: Problem Solving
Temperature is a key factor in CO2 solubility. In this case, the CO2 gas and the liquid are cooled to 20°C. Lower temperatures enhance...
 01:24
Laminar Flow: Problem Solving
 01:16
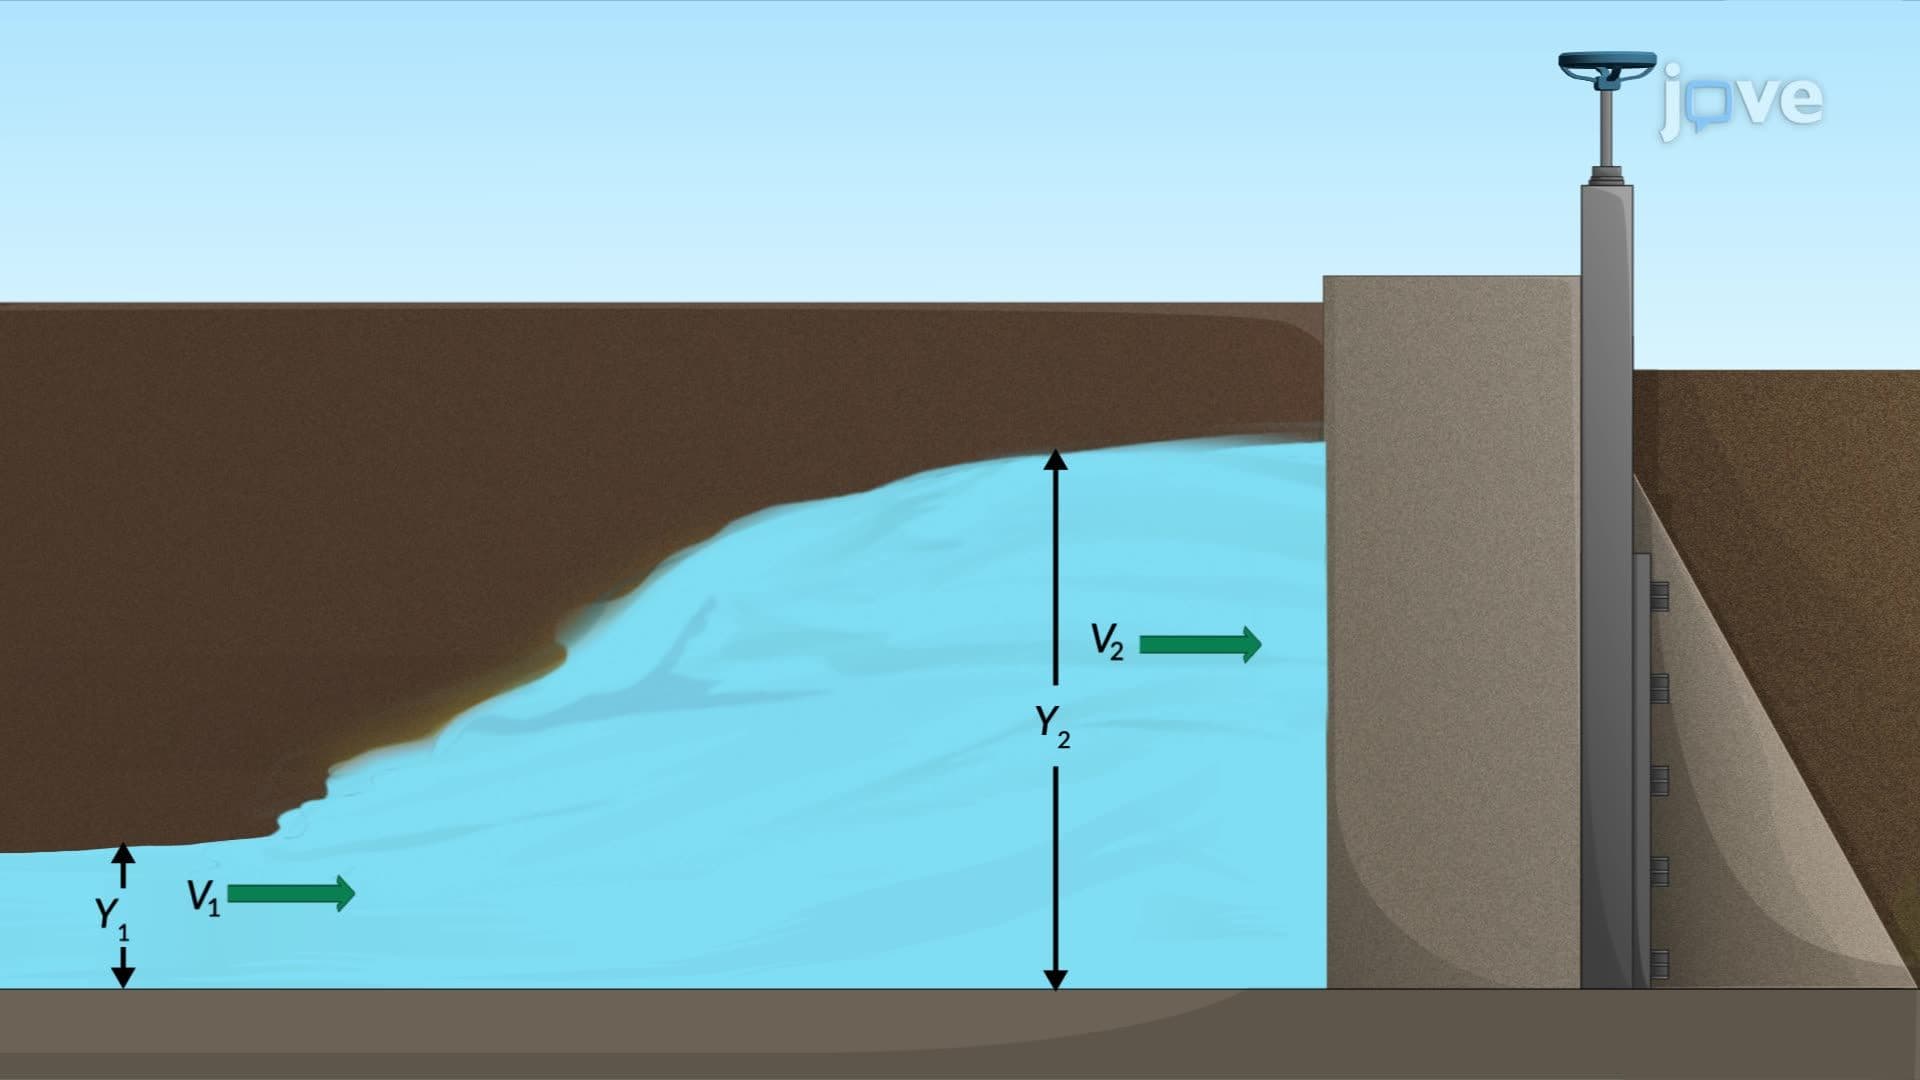
Hydraulic Jump: Problem Solving