Related Experiment Video
Updated: Nov 27, 2025


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Optimal Digital Implementation of Fractional-Order Models in a Microcontroller
Mariusz Matusiak1, Marcin Bąkała1, Rafał Wojciechowski1
1Institute of Applied Computer Science, Łódź University of Technology, ul. Stefanowskiego 18/22, 90-924 Lodz, Poland.

Abstract:
The growing number of operations in implementations of the non-local fractional differentiation operator is cumbersome for real applications with strict performance and memory storage requirements. This demands use of one of the available approximation methods. In this paper, the analysis of the classic integer- (IO) and fractional-order (FO) models of the brushless DC (BLDC) micromotor mounted on a steel rotating arms, and next, the discretization and efficient implementation of the models in a microcontroller (MCU) is performed. Two different methods for the FO model are examined, including the approximation of the fractional-order operator s ν ( ν ∈ R ) using the Oustaloup Recursive filter and the numerical evaluation of the fractional differintegral operator based on the Grünwald-Letnikov definition and Short Memory Principle. The models are verified against the results of several experiments conducted on an ARM Cortex-M7-based STM32F746ZG unit. Additionally, some software optimization techniques for the Cortex-M microcontroller family are discussed. The described steps are universal and can also be easily adapted to any other microcontroller. The values for integral absolute error (IAE) and integral square error (ISE) performance indices, calculated on the basis of simulations performed in MATLAB, are used to evaluate accuracy.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 09:08
Three-dimensional Printing of Thermoplastic Materials to Create Automated Syringe Pumps with Feedback Control for Microfluidic Applications
Published on: August 30, 2018
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
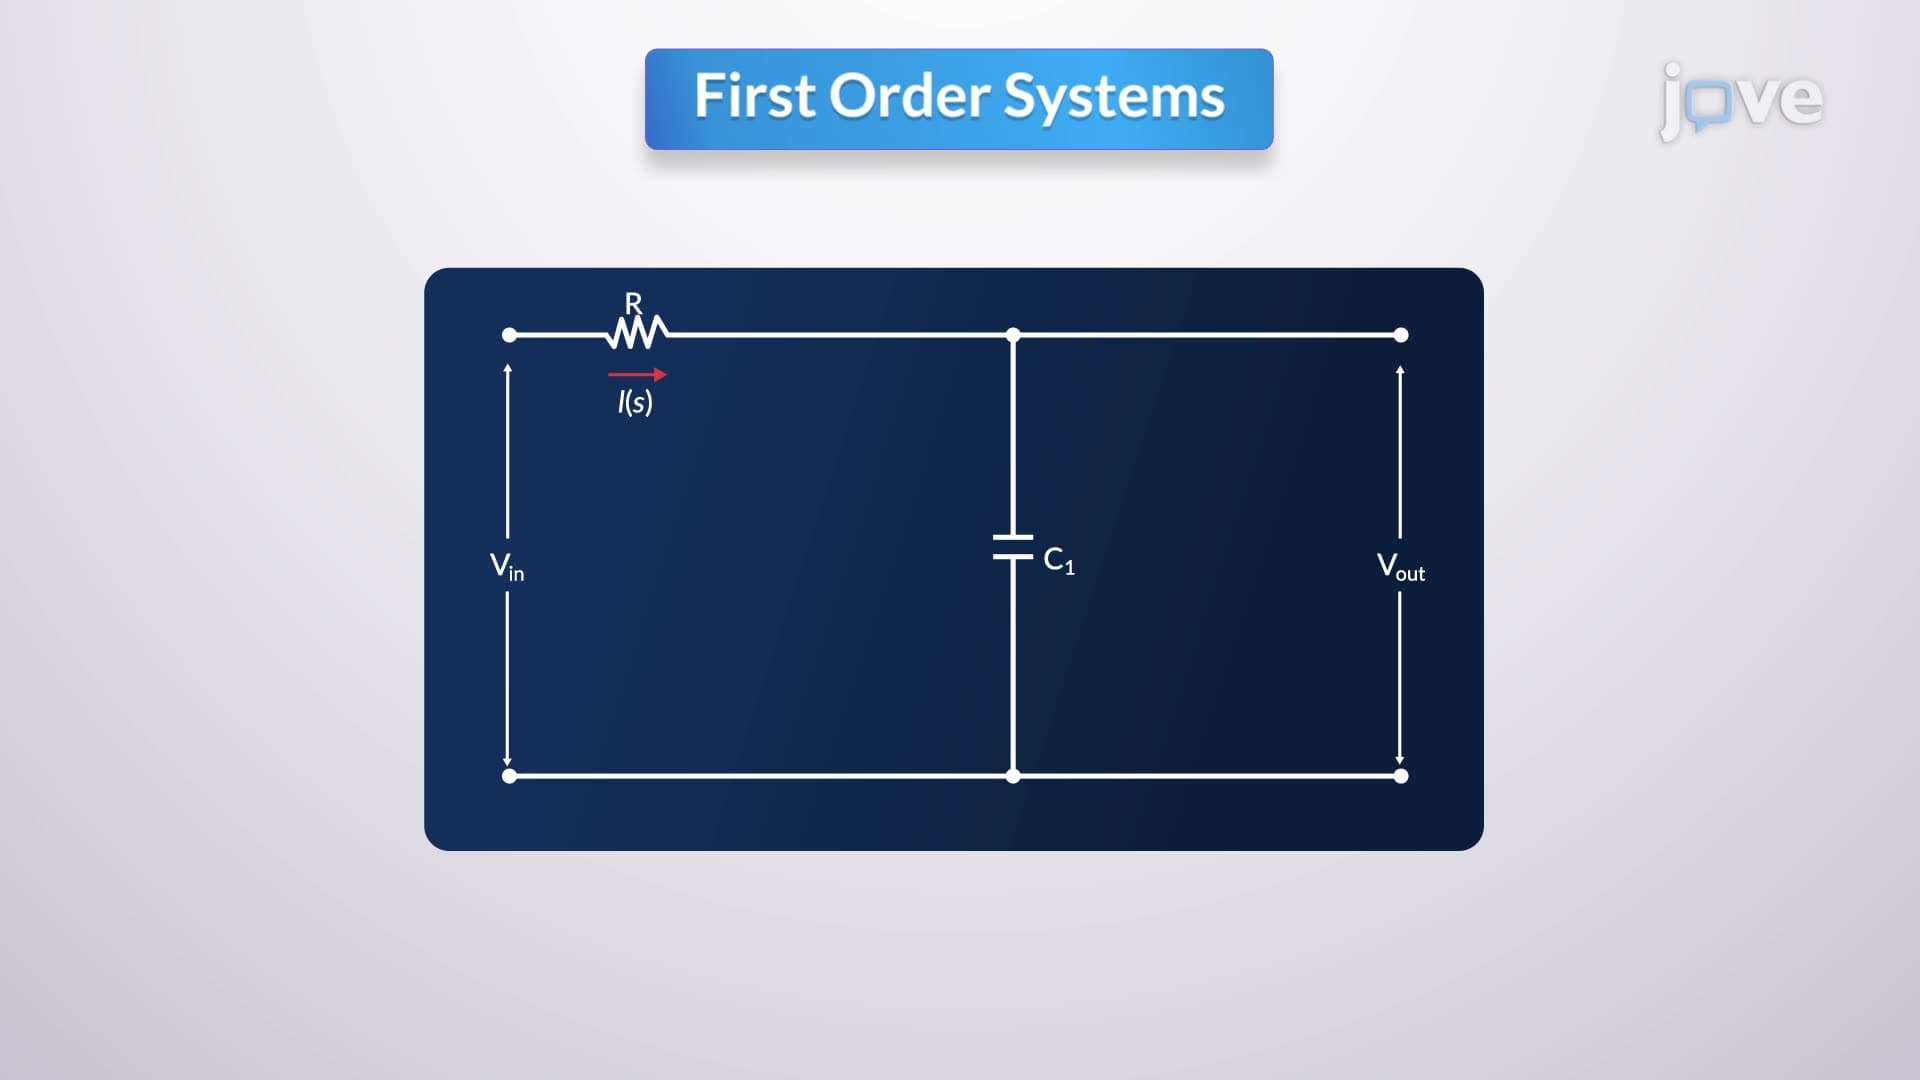
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Phase-lead and Phase-lag Controllers