Related Experiment Video
Updated: Nov 26, 2025
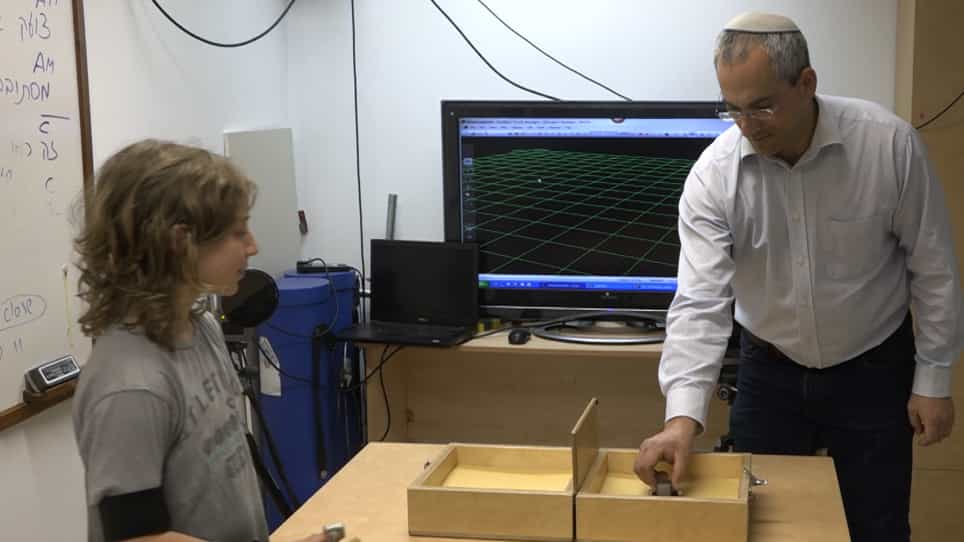

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
A Position-Control Based Approach to Haptic Rendering of Stiff Objects

Abstract:
Conventional force rendering methods in haptic applications often suffer stability issues when simulating interactions with stiff objects such as a virtual wall. This paper argues that the emphasis in such scenarios is to minimize the penetration into the virtual wall instead of modeling the wall as a spring-damper system. Therefore, we propose an approach using a position controller to achieve better haptic rendering of the virtual wall. The proposed approach exploits model-based development tools to obtain the linear control system model without the need for an analytical model of the dynamics of the haptic device. A simulation-based performance comparison of two different controllers has been made for a 6-DOF parallel structure haptic device.
More Related Videos


Related Concept Videos
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:09
Bending of Material: Problem Solving
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...