Related Experiment Video
Updated: Nov 25, 2025
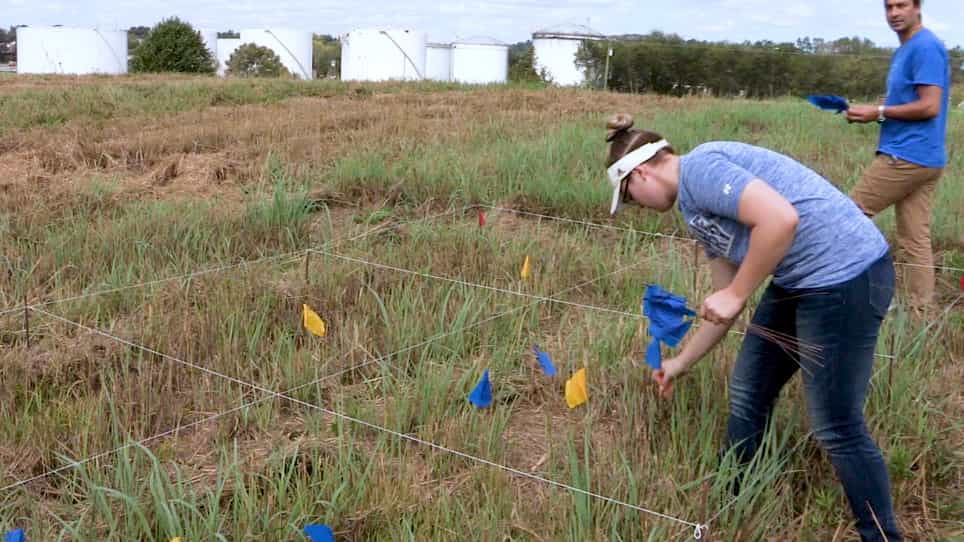
Sampling Soils in a Heterogeneous Research Plot
Published on: January 7, 2019
Statistical Distribution Analysis of Navigation Positioning System Errors-Issue of the Empirical Sample Size
1Department of Transport and Logistics, Gdynia Maritime University, Morska 81-87, 81-225 Gdynia, Poland.

Abstract:
Positioning systems are used to determine position coordinates in navigation (air, land, and marine). Statistical analysis of their accuracy assumes that the position errors (latitude-δ and longitude-δ) are random and that their distributions are consistent with the normal distribution. However, in practice, these errors do not appear in a random way, since the position determination in navigation systems is done with an iterative method. It causes so-called "Position Random Walk", similar to the term "Random Walk" known from statistics. It results in the empirical distribution of δ and δ being inconsistent with the normal distribution, even for samples of up to several thousand measurements. This phenomenon results in a significant overestimation of the accuracy of position determination calculated from such a short series of measurements, causing these tests to lose their representativeness. This paper attempts to determine the length of a measurement session (number of measurements) that is representative of the positioning system. This will be a measurement session of such a length that the position error statistics (δ and δ) represented by the standard deviation values are close to the real values and the calculated mean values (φ¯ and λ¯) are also close to the real values. Special attention will also be paid to the selection of an appropriate (statistically reliable) number of measurements to be tested statistically to verify the hypothesis that the δ and δ distributions are consistent with the normal distribution. Empirical measurement data are taken from different positioning systems: Global Positioning System (GPS) (168'286 fixes), Differential Global Positioning System (DGPS) (864'000 fixes), European Geostationary Navigation Overlay Service (EGNOS) (928'492 fixes), and Decca Navigator system (4052 fixes). The analyses showed that all researched positioning systems (GPS, DGPS, EGNOS and Decca Navigator) are characterized by the Position Random Walk (PRW), which resulted in that the empirical distribution of δ and δ being inconsistent with the normal distribution. The size of the PRW depends on the nominal accuracy of position determination by the system. It was found that measurement sessions consisting of 1000 fixes (for the GPS system) overestimate the accuracy analysis results by 109.1% and cannot be considered representative. Furthermore, when analyzing the results of long measurement campaigns (GPS and DGPS), it was found that the representative length of the measurement session differs for each positioning system and should be determined for each of them individually.
Related Concept Videos
 01:26
Errors in Global Positioning System
 01:04
Random Error
 01:15
Systematic Error: Methodological and Sampling Errors
Sampling errors originate from improper sampling methods or the wrong sample population. These errors can be minimized by refining the sampling strategy. Defective instruments or faulty calibrations are the sources of instrumental...
 01:16
Contaminants and Errors
Another key consideration is determining the appropriate number of samples required to...
 01:20
Random and Systematic Errors
 01:19
Errors and Mistakes in Surveying