Related Experiment Video
Updated: Nov 24, 2025

Influence of Step-Width Manipulation on Running Biomechanics
Published on: February 28, 2025
Kinematics of Maximal Speed Sprinting With Different Running Speed, Leg Length, and Step Characteristics
Kenji Miyashiro1, Ryu Nagahara2, Kohei Yamamoto3,4
1Law Course, Department of Law, Nihon Bunka University, Tokyo, Japan.

Abstract:
This study aimed to provide multiple regression equations taking into account differences in running speed, leg length, and step characteristics to predict kinematics of maximal speed sprinting. Seventy-nine male sprinters performed a maximal effort 60-m sprint, during which they were videoed through the section from the 40- to 50-m mark. From the video images, leg kinematic variables were obtained and used as dependent variables for multiple linear regression equation with predictors of running speed, leg length, step frequency, and swing/support ratio. Multiple regression equations to predict leg kinematics of maximal speed sprinting were successfully obtained. For swing leg kinematics, a significant regression model was obtained to predict thigh angle at the contralateral foot strike, maximal knee flexion and thigh lift angular velocities, and maximal leg backward swing velocity (adjusted R 2 = 0.194-0.378, medium to large effect). For support leg kinematics, a significant regression model was obtained to predict knee flexion and extension angular displacements, maximal knee extension velocity, maximal leg backward swing angular velocity, and the other 13 kinematic variables (adjusted R 2 = 0.134-0.757, medium to large effect). Based on the results, at a given leg length, faster maximal speed sprinting will be accompanied with greater thigh angle at the contralateral foot strike, greater maximal leg backward swing velocity during the swing phase, and smaller knee extension range during the support phase. Longer-legged sprinters will accomplish the same running speed with a greater thigh angle at contralateral foot strike, greater knee flexion range, and smaller maximal leg backward swing velocity during the support phase. At a given running speed and leg length, higher step frequencies will be achieved with a greater thigh angle at contralateral foot strike and smaller knee flexion and extension ranges during the support phase. At a given running speed, leg length and step frequency, a greater swing/support ratio will be accompanied with a greater thigh angle at contralateral foot strike and smaller knee extension angular displacement and velocity during the support phase. The regression equations obtained in this study will be useful for sprinters when trying to improve their maximal speed sprinting motion.
More Related Videos
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
 08:26
Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
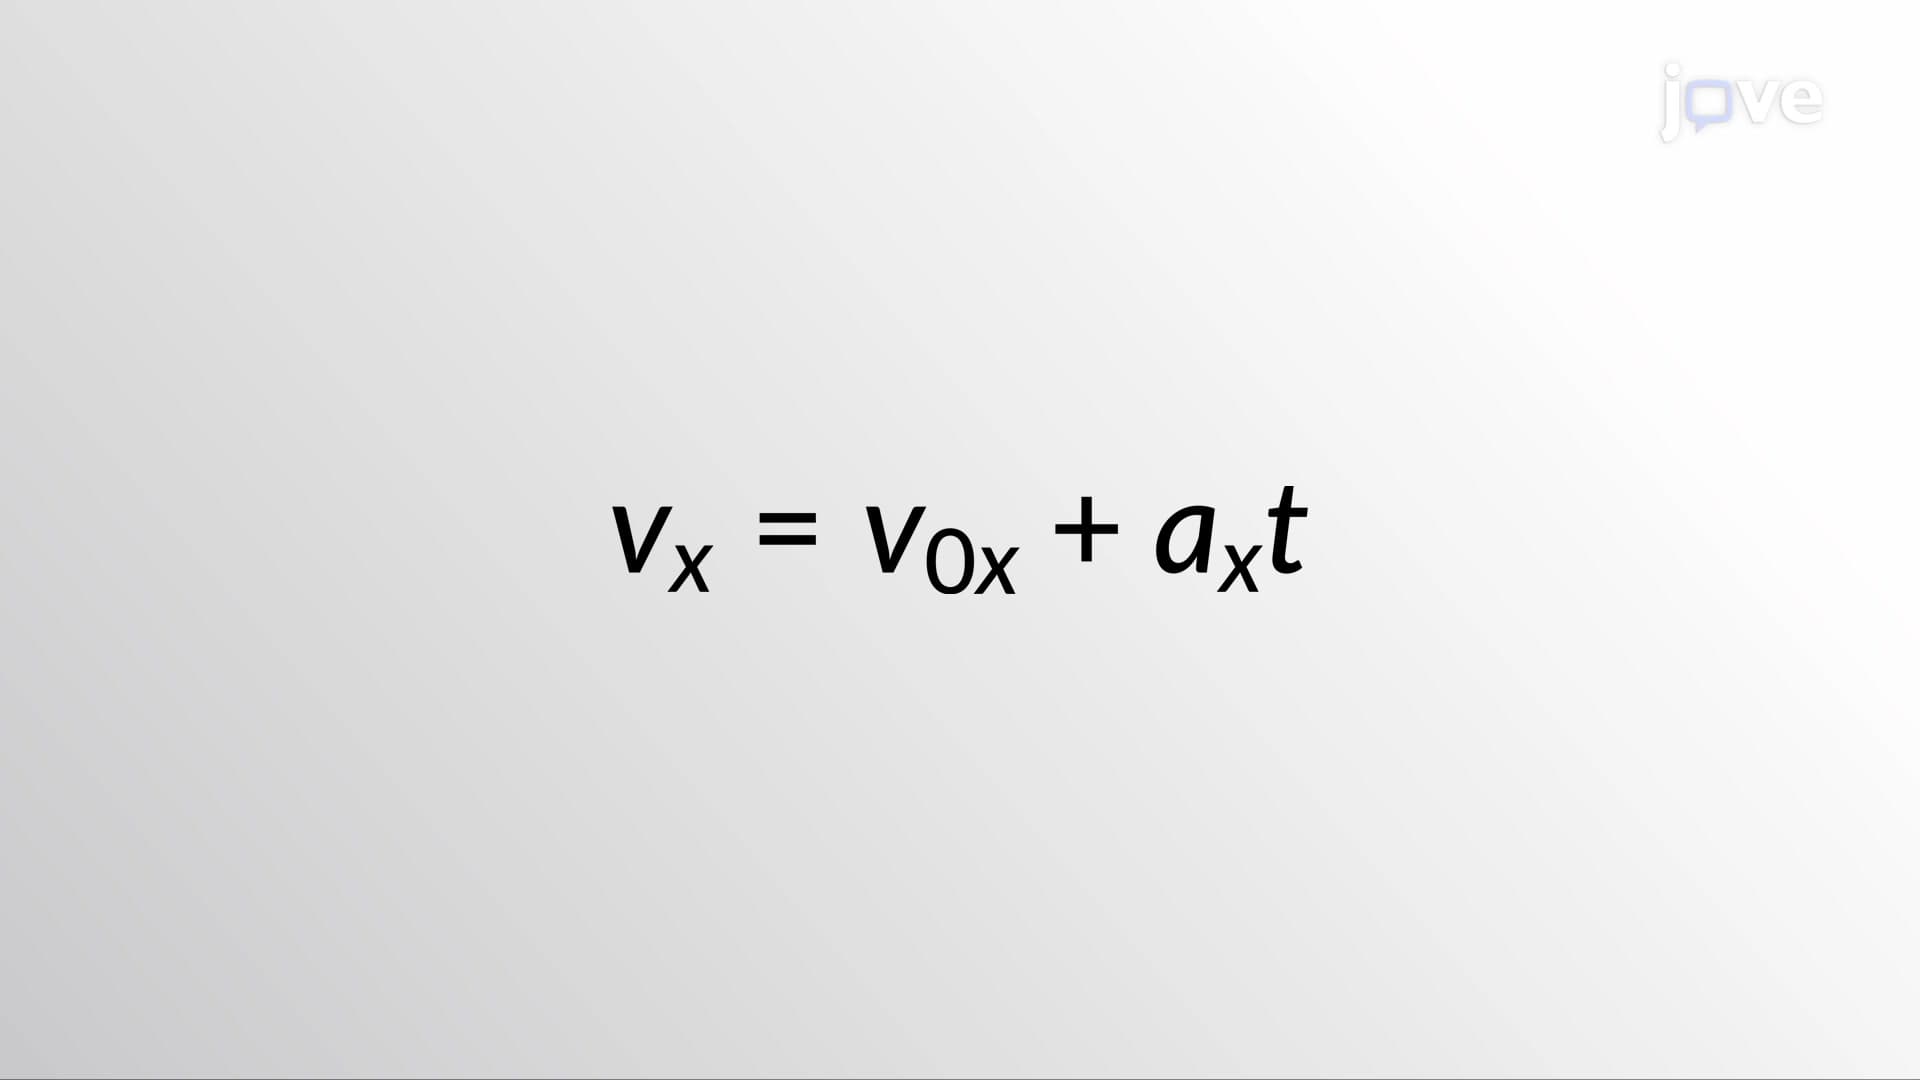 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:28
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....