Composite-Learning-Based Adaptive Neural Control for Dual-Arm Robots With Relative Motion
Related Experiment Video
Updated: Nov 24, 2025

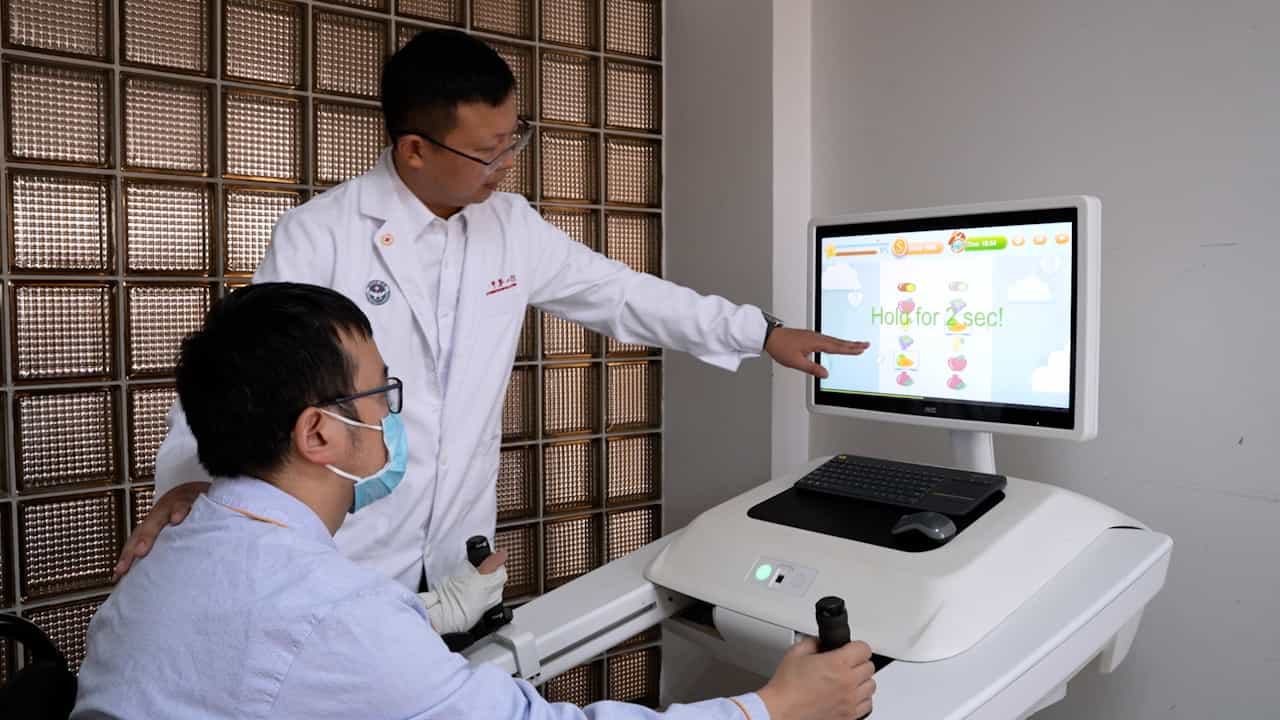
Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016

Abstract:
This article presents an adaptive control method for dual-arm robot systems to perform bimanual tasks under modeling uncertainties. Different from the traditional symmetric bimanual robot control, we study the dual-arm robot control with relative motions between robotic arms and a grasped object. The robot system is first divided into two subsystems: a settled manipulator system and a tool-used manipulator system. Then, a command filtered control technique is developed for trajectory tracking and contact force control. In addition, to deal with the inevitable dynamic uncertainties, a radial basis function neural network (RBFNN) is employed for the robot, with a novel composite learning law to update the NN weights. The composite learning is mainly based on an integration of the historic data of NN regression such that information of the estimate error can be utilized to improve the convergence. Moreover, a partial persistent excitation condition is employed to ensure estimation convergence. The stability analysis is performed by using the Lyapunov theorem. Numerical simulation results demonstrate the validity of the proposed control and learning algorithm.

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:18
Hierarchy of Motor Control
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...