Related Experiment Video
Updated: Nov 24, 2025

Integration of 5G Experimentation Infrastructures into a Multi-Site NFV Ecosystem
Published on: February 3, 2021
5G-Enabled Autonomous Driving Demonstration with a V2X Scenario-in-the-Loop Approach
Zsolt Szalay1,2, Dániel Ficzere3, Viktor Tihanyi1,2
1Department of Automotive Technologies, Budapest University of Technology and Economics, 6, Stoczek utca, 1111 Budapest, Hungary.

Abstract:
Autonomous vehicles are at the forefront of interest due to the expectations of changing transportation for the better. In order to make better decisions on the road, vehicles use information from various sources: their own sensors, messages arriving from surrounding vehicles and objects, as well as from centralized entities-including their own Digital Twin. Certain decisions require the information to arrive with low latency and some of this information (such as video) requires broadband communication. Furthermore, the vehicles can populate an area, so they can represent mass communication endpoints that still need low latency and massive broadband. The mobility of the vehicles obviously requires the complete coverage of the roads with reliable wireless communication technologies fulfilling the previously mentioned needs. The fifth generation of cellular mobile technologies, 5G, addresses these requirements. The current paper presents real-life scenarios-on the M86 highway and the ZalaZONE proving ground in Hungary-for the demonstration of vehicular communication with 5G support, where the cars exchange sensor and control information with each other, their environment, and their Digital Twins. The demonstrations were carried out through the Scenario-in-the-Loop (SciL) methodology, where some of the actionable triggers were not physically present around the vehicles, but sensed or simulated around their Digital Twin. The measurements around the demonstrations aim to reveal the feasibility of the 5G Non-Standalone Architecture for certain communication scenarios, and they mainly aim to reveal the current latency and throughput limitations under real-life conditions.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:10
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:21
Distributed Loads: Problem Solving
 01:13
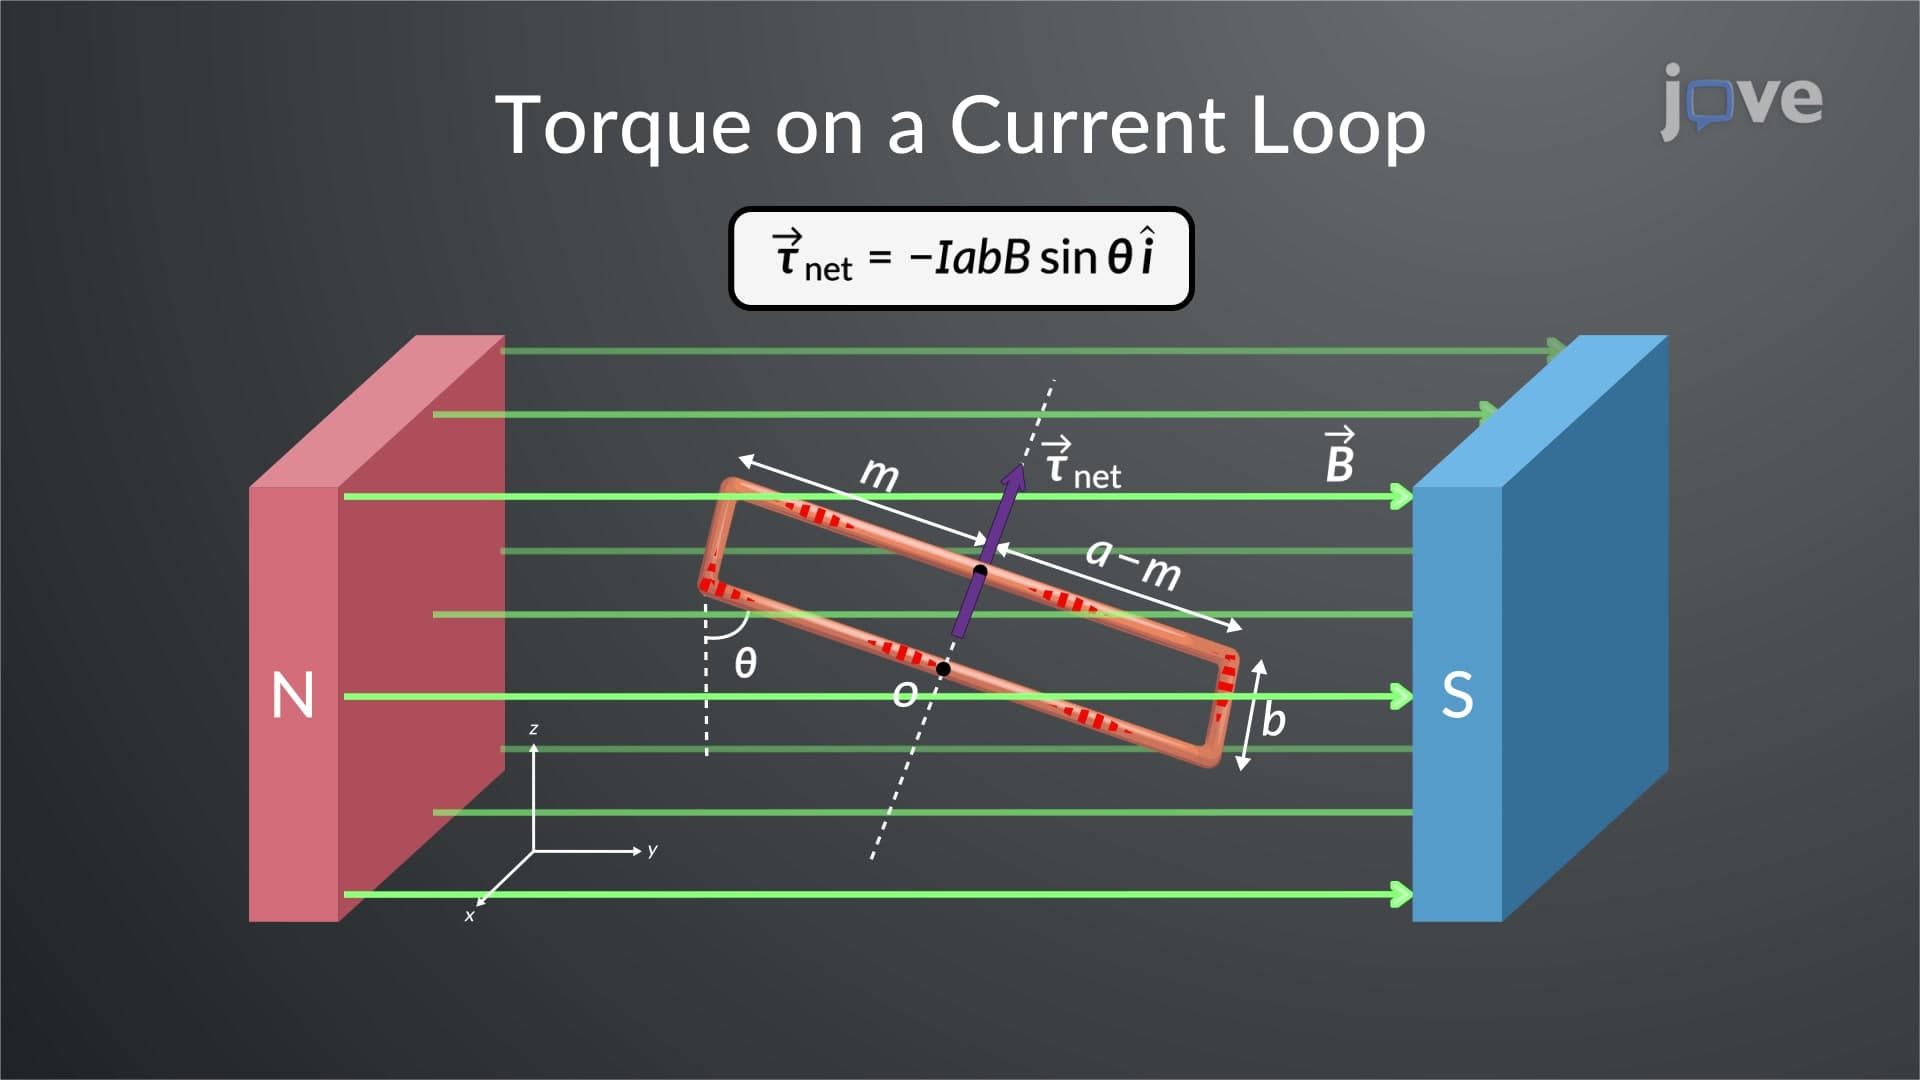
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...