Related Experiment Video
Updated: Nov 23, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Behavioural Study of the Force Control Loop Used in a Collaborative Robot for Sanding Materials
Rodrigo Pérez Ubeda1, Santiago C Gutiérrez Rubert1, Ranko Zotovic Stanisic2
1Department of Mechanical and Materials Engineering, Universitat Politècnica de València, 46022 Valencia, Spain.

Abstract:
The rise of collaborative robots urges the consideration of them for different industrial tasks such as sanding. In this context, the purpose of this article is to demonstrate the feasibility of using collaborative robots in processing operations, such as orbital sanding. For the demonstration, the tools and working conditions have been adjusted to the capacity of the robot. Materials with different characteristics have been selected, such as aluminium, steel, brass, wood, and plastic. An inner/outer control loop strategy has been used, complementing the robot's motion control with an outer force control loop. After carrying out an explanatory design of experiments, it was observed that it is possible to perform the operation in all materials, without destabilising the control, with a mean force error of 0.32%. Compared with industrial robots, collaborative ones can perform the same sanding task with similar results. An important outcome is that unlike what might be thought, an increase in the applied force does not guarantee a better finish. In fact, an increase in the feed rate does not produce significant variation in the finish-less than 0.02 µm; therefore, the process is in a "saturation state" and it is possible to increase the feed rate to increase productivity.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:05
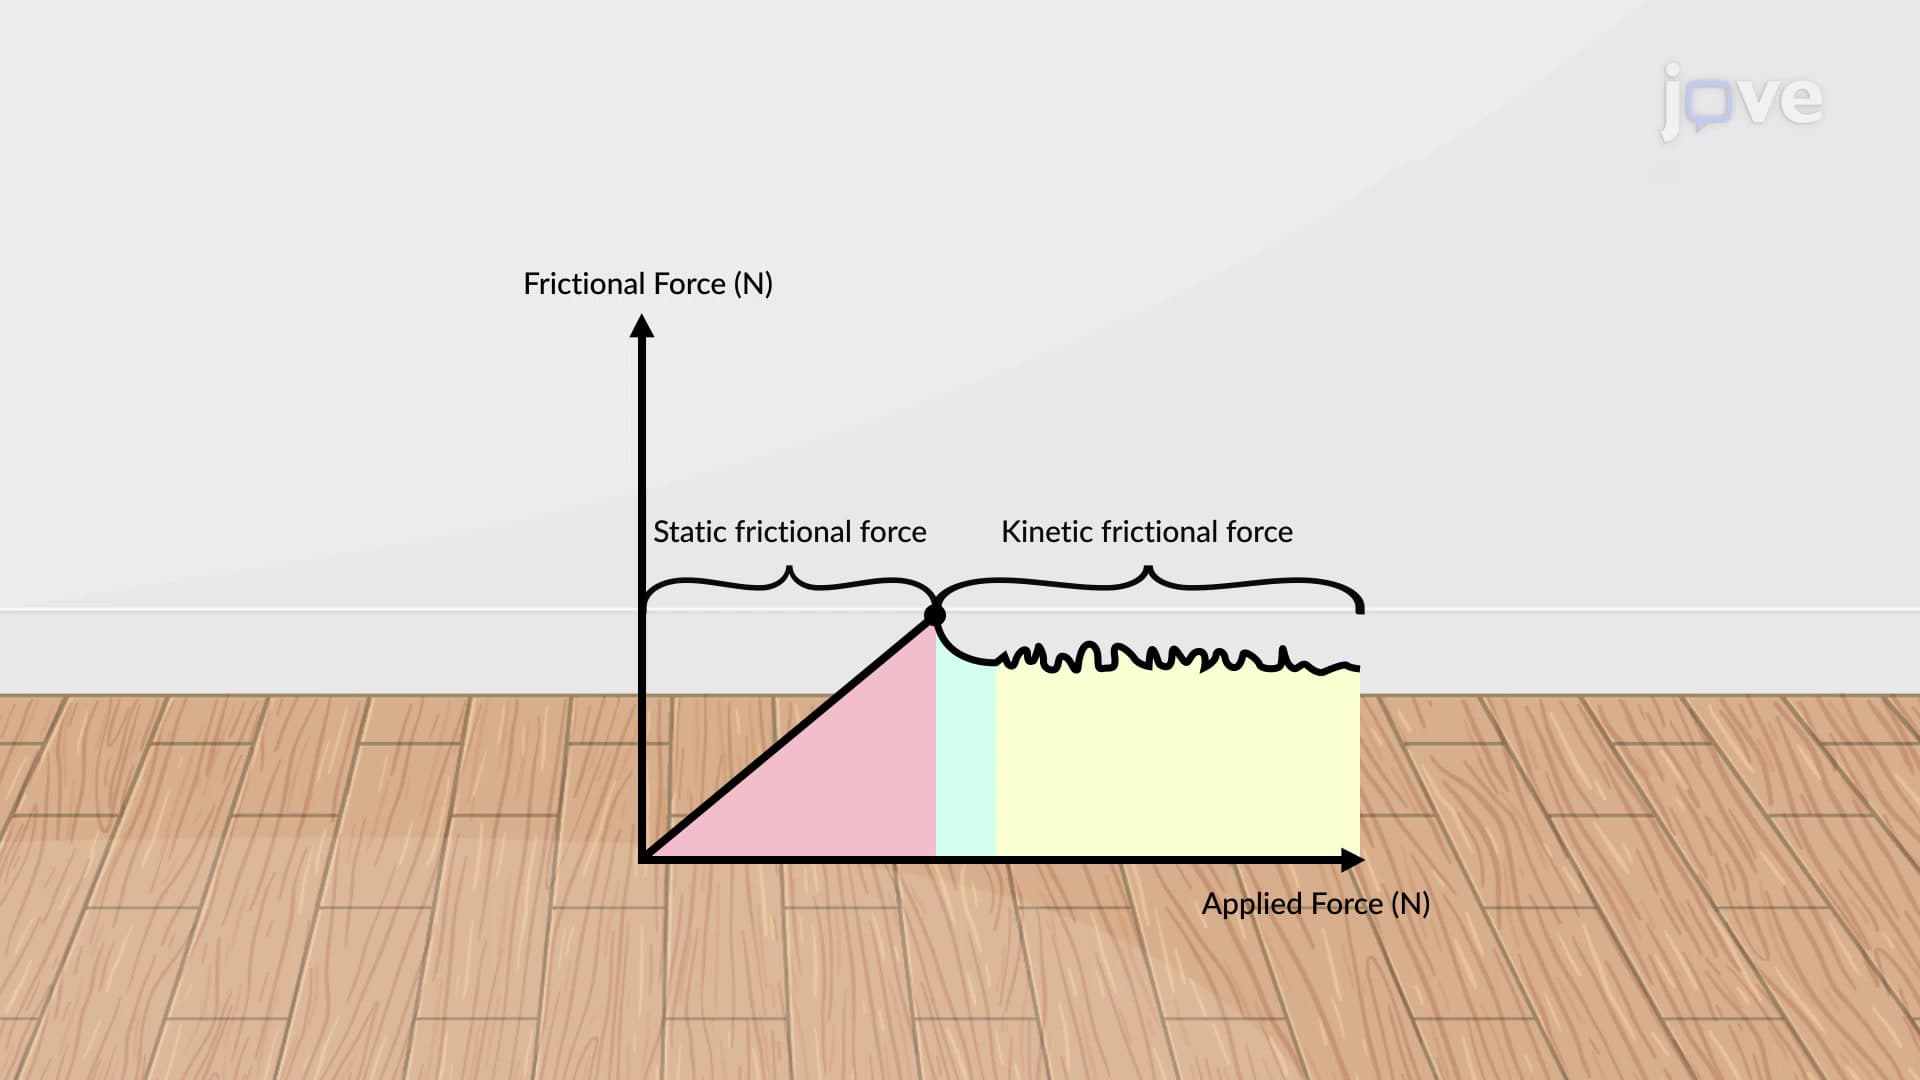
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:10
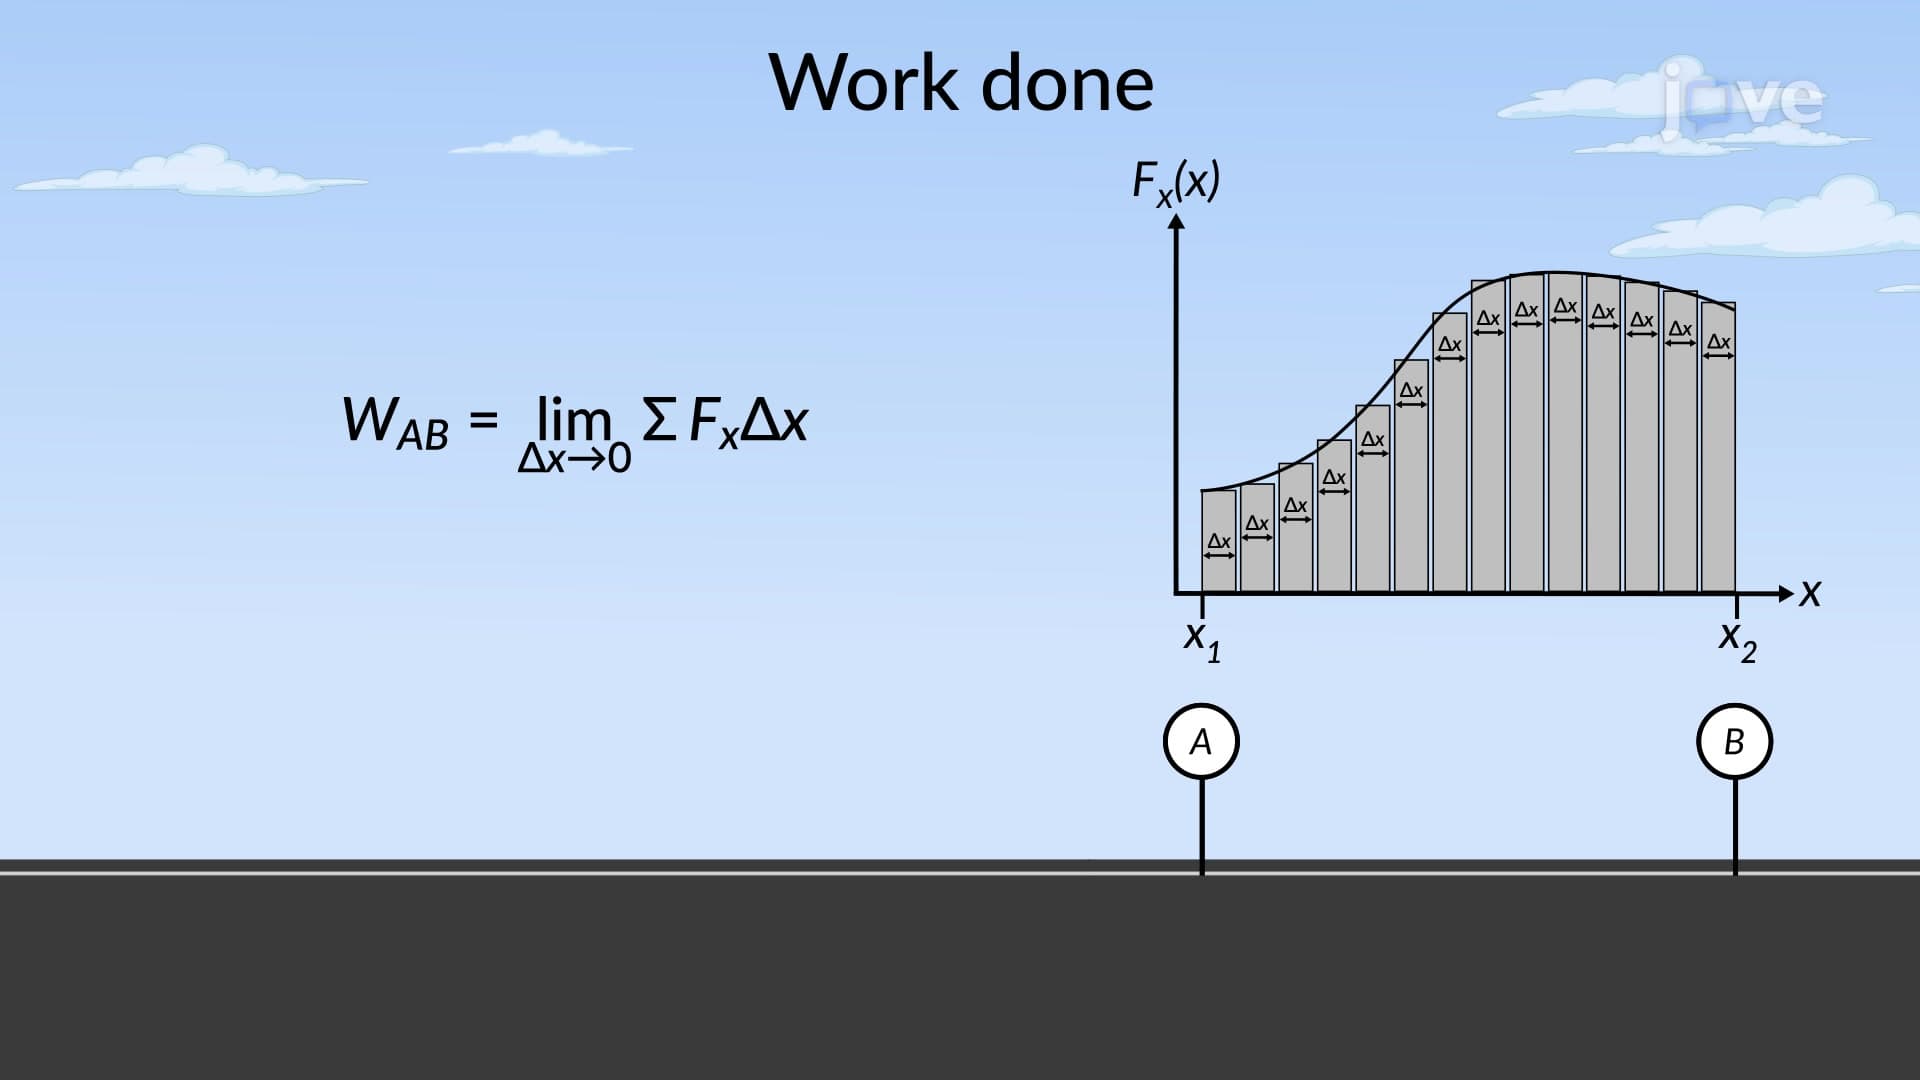
Work and Energy for Variable Forces
 01:22
Mechanical Systems