Related Experiment Video
Updated: Nov 22, 2025


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Shoulder kinematics plus contextual target information enable control of multiple distal joints of a simulated
Sébastien Mick1, Effie Segas2, Lucas Dure2
1Institut de Neurosciences Cognitives et Intégratives d'Aquitaine, UMR 5287, CNRS and Univ. Bordeaux, 146 rue Léo Saignat, 33076, Bordeaux, France. sebastien.mick@u-bordeaux.fr.

Background:
Prosthetic restoration of reach and grasp function after a trans-humeral amputation requires control of multiple distal degrees of freedom in elbow, wrist and fingers. However, such a high level of amputation reduces the amount of available myoelectric and kinematic information from the residual limb.
Methods:
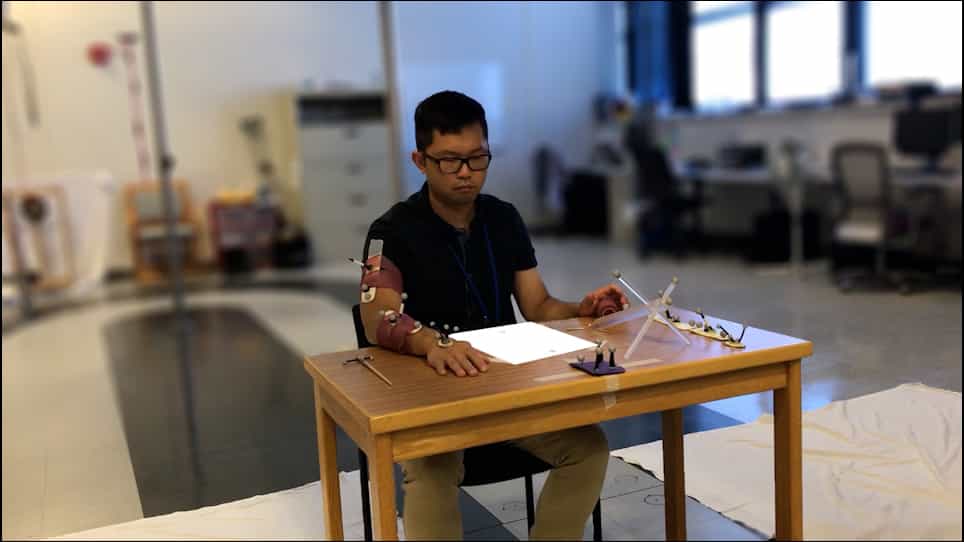
To overcome these limits, we added contextual information about the target's location and orientation such as can now be extracted from gaze tracking by computer vision tools. For the task of picking and placing a bottle in various positions and orientations in a 3D virtual scene, we trained artificial neural networks to predict postures of an intact subject's elbow, forearm and wrist (4 degrees of freedom) either solely from shoulder kinematics or with additional knowledge of the movement goal. Subjects then performed the same tasks in the virtual scene with distal joints predicted from the context-aware network.
Results:
Average movement times of 1.22s were only slightly longer than the naturally controlled movements (0.82 s). When using a kinematic-only network, movement times were much longer (2.31s) and compensatory movements from trunk and shoulder were much larger. Integrating contextual information also gave rise to motor synergies closer to natural joint coordination.
Conclusions:
Although notable challenges remain before applying the proposed control scheme to a real-world prosthesis, our study shows that adding contextual information to command signals greatly improves prediction of distal joint angles for prosthetic control.
More Related Videos

Related Concept Videos
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...