Related Experiment Video
Updated: Nov 21, 2025
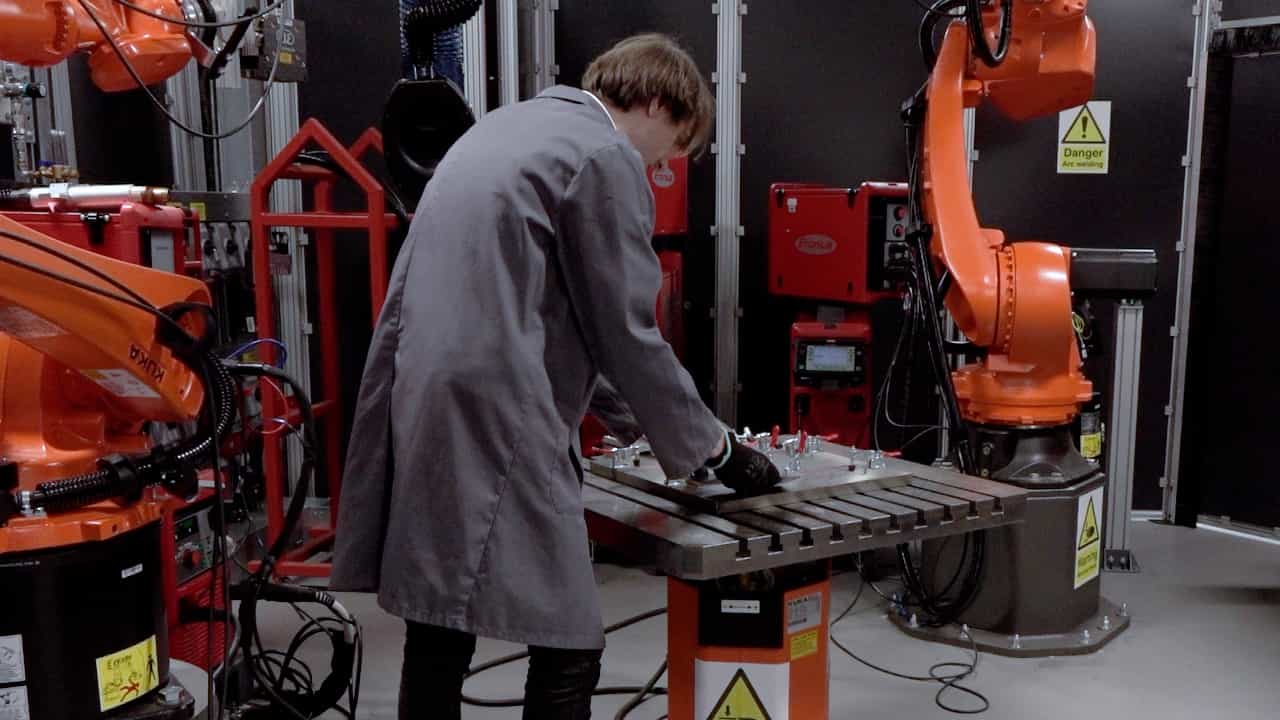
Automatic Laser-based Geometry Capture for Finite Element Analysis of Weld Beads
Published on: July 25, 2025
Online Extraction of Pose Information of 3D Zigzag-Line Welding Seams for Welding Seam Tracking
Bo Hong1, Aiting Jia1, Yuxiang Hong2
1College of Mechanical Engineering, Xiangtan University, Xiangtan 411105, China.

Abstract:
Three-dimensional (3D) zigzag-line welding seams are found extensively in the manufacturing of marine engineering equipment, heavy lifting equipment, and logistics transportation equipment. Currently, due to the large amount of calculation and poor real-time performance of 3D welding seam detection algorithms, real-time tracking of 3D zigzag-line welding seams is still a challenge especially in high-speed welding. For the abovementioned problems, we proposed a method for the extraction of the pose information of 3D zigzag-line welding seams based on laser displacement sensing and density-based clustering point cloud segmentation during robotic welding. after thee point cloud data of the 3D zigzag-line welding seams was obtained online by the laser displacement sensor, it was segmented using theρ-Approximate DBSCAN (Density-Based Spatial Clustering of Applications with Noise) algorithm. In the experiment, high-speed welding was performed on typical low-carbon steel 3D zigzag-line welding seams using gas metal arc welding. The results showed that when the welding velocity was 1000 mm/min, the proposed method obtained a welding seam position detection error of less than 0.35 mm, a welding seam attitude estimation error of less than two degrees, and the running time of the main algorithm was within 120 ms. Thus, the online extraction of the pose information of 3D zigzag-line welding seams was achieved and the requirements of welding seam tracking were met.
Related Concept Videos
 01:20
Mesh Analysis
A fundamental concept in mesh analysis is the definition of meshes and mesh currents. A mesh is a closed...
 01:29
Three-Dimensional Analysis of Strain