WITHDRAWN: Deep learning for Koopman Operator Optimal Control
Related Experiment Video
Updated: Nov 21, 2025

Deep Neural Networks for Image-Based Dietary Assessment
Published on: March 13, 2021
1Electrical Power Engineering and Automatic Control Department, Pyramids Higher Institute for Engineering and Technology, Egypt.

Abstract:
Nonlinear dynamics are ubiquitous in complex systems. Their applications range from robotics to computational neuroscience. In this work, the Koopman framework for globally linearizing nonlinear dynamics is introduced. Under this framework, the nonlinear observable states are lifted into a higher dimensional, linear regime. The challenge is to identify functions that facilitate the coordinate transformation to this raised linear space. This point is tackled using deep learning, where nonlinear dynamics are learned in a model-free manner, i.e., the underlying dynamics are uncovered using data rather than the nonlinear state-space equations. The main contributions include an implementation of the Linearly Recurrent Encoder Network (LREN) that is faster than the existing implementation and is significantly faster than the state-of-the-art deep learning-based approach. Also, a novel architecture termed Deep Encoder with Initial State Parameterization (DENIS) is proposed. By deriving an energy-budget control performance evaluation method, we demonstrate that DENIS also outperforms LREN in control performance. It is also on-par with and sometimes better than the iterative linear quadratic regulator (iLQR), which requires access to the state-space equations. Extensive experiments are done on DENIS to validate its performance. Also, another novel architecture termed Double Encoder for Input Nonaffine systems (DEINA) is described. Additionally, DEINA's potential ability to outperform existing Koopman frameworks for controlling nonaffine input systems is shown. We attribute this to using an auxiliary network to nonlinearly transform the inputs, thereby lifting the strong linear constraints imposed by the traditional Koopman approximation approach. Koopman model predictive control (KMPC) is implemented to verify that our models can also be successfully controlled under this popular approach. Overall, we demonstrate the deep learning-based Koopman framework shows promise for optimally controlling nonlinear dynamics.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...
 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:22
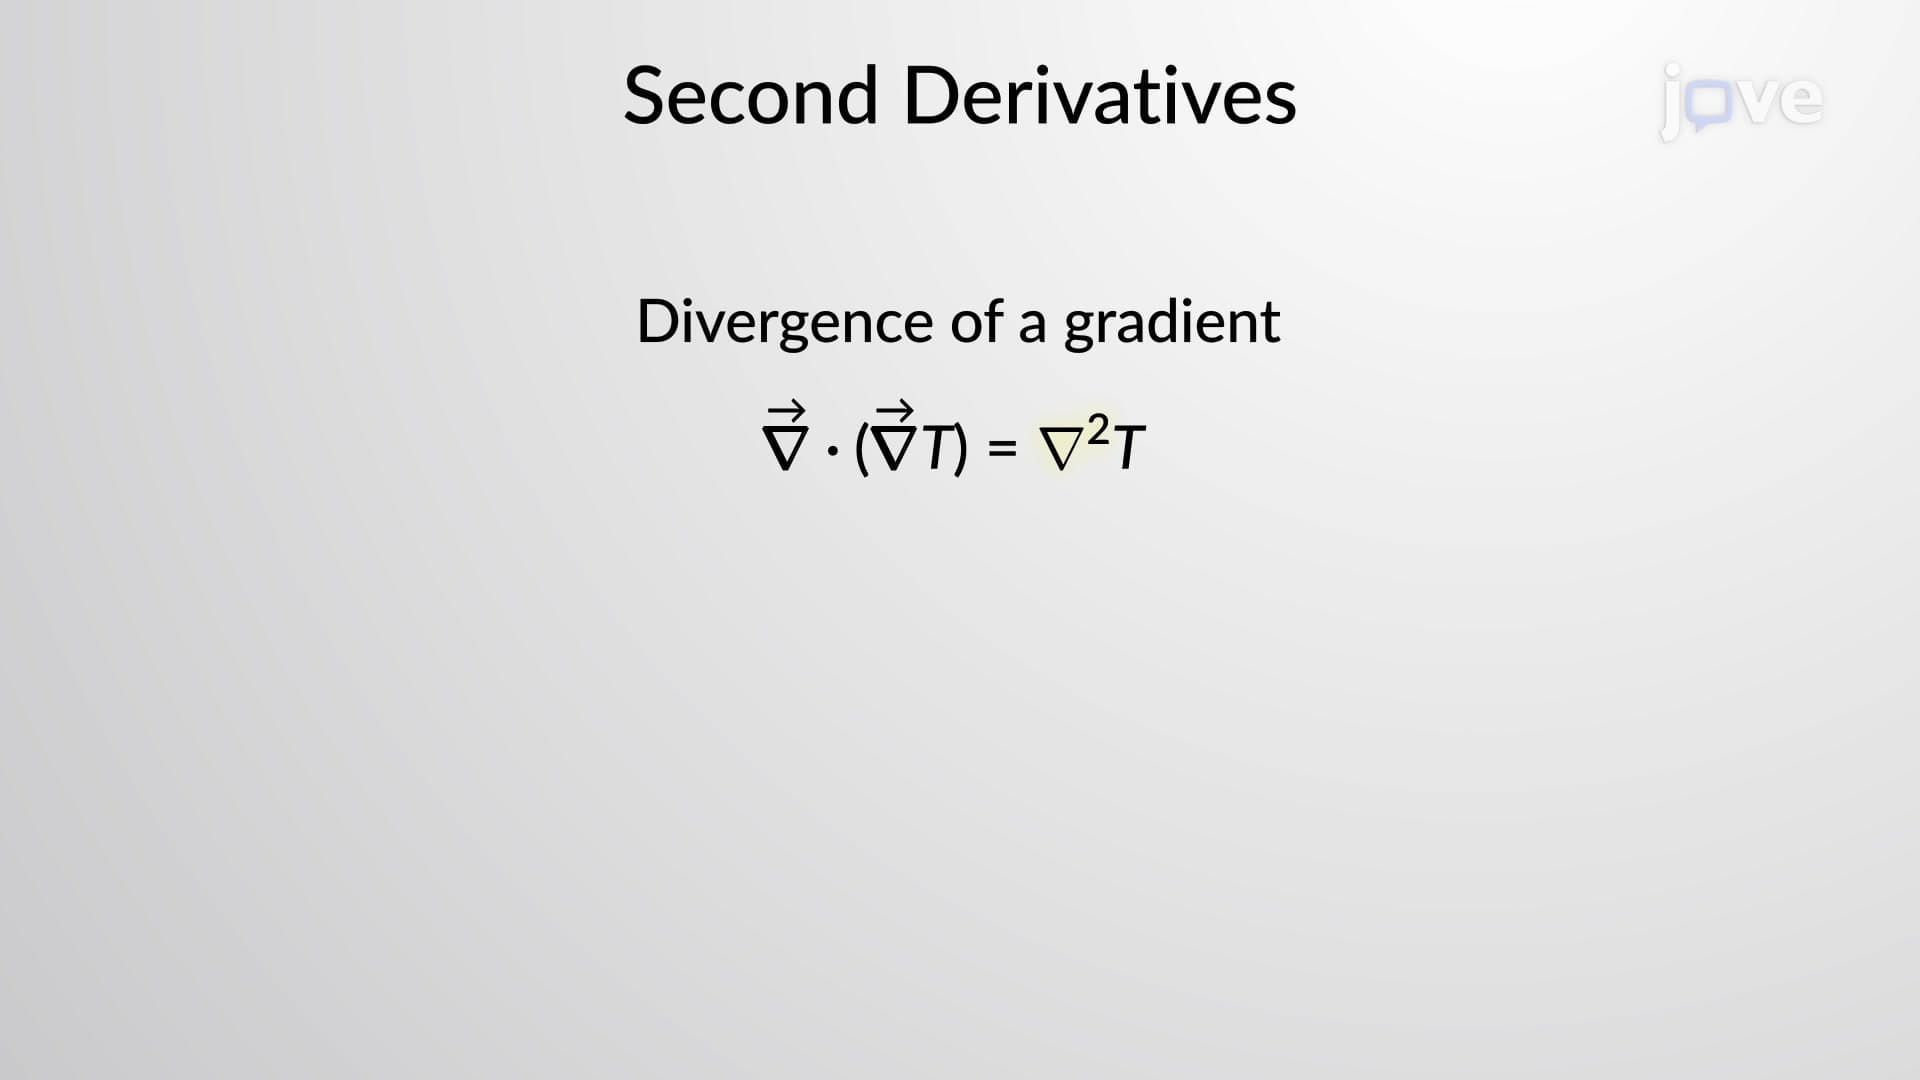
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...