Related Experiment Video
Updated: Nov 20, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Synchronization-based control for a collaborative robot
Henry Eberle1, Slawomir J Nasuto2, Yoshikatsu Hayashi2
1Department of Orthopaedics and Musculoskeletal Science, Division of Surgery, University College London, London WC1E 6BT, UK.

Abstract:
This article introduces a new control scheme for controlling a robotic manipulator in a collaborative task, allowing it to respond proactively to its partner's movements. Unlike conventional robotic systems, humans can operate in an unstructured, dynamic environment due to their ability to anticipate changes before they occur and react accordingly. Recreating this artificially by using a forward model would lead to the huge computational task of simulating a world full of complex nonlinear dynamics and autonomous human agents. In this study, a controller based on anticipating synchronization, where a 'leader' dynamical system is predicted by a coupled 'follower' with delayed self-feedback, is used to modify a robot's dynamical behaviour to follow that of a series of leaky integrators and harmonic oscillators. This allows the robot (follower) to be coupled with a collaborative partner (leader) to anticipate its movements, without a complete model of its behaviour. This is tested by tasking a simulated Baxter robot with performing a collaborative manual coordination task with an autonomous partner under a range of feedback delay conditions, confirming its ability to anticipate using oscillators instead of a detailed forward model.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:10
Control Systems
At the heart...
 01:30
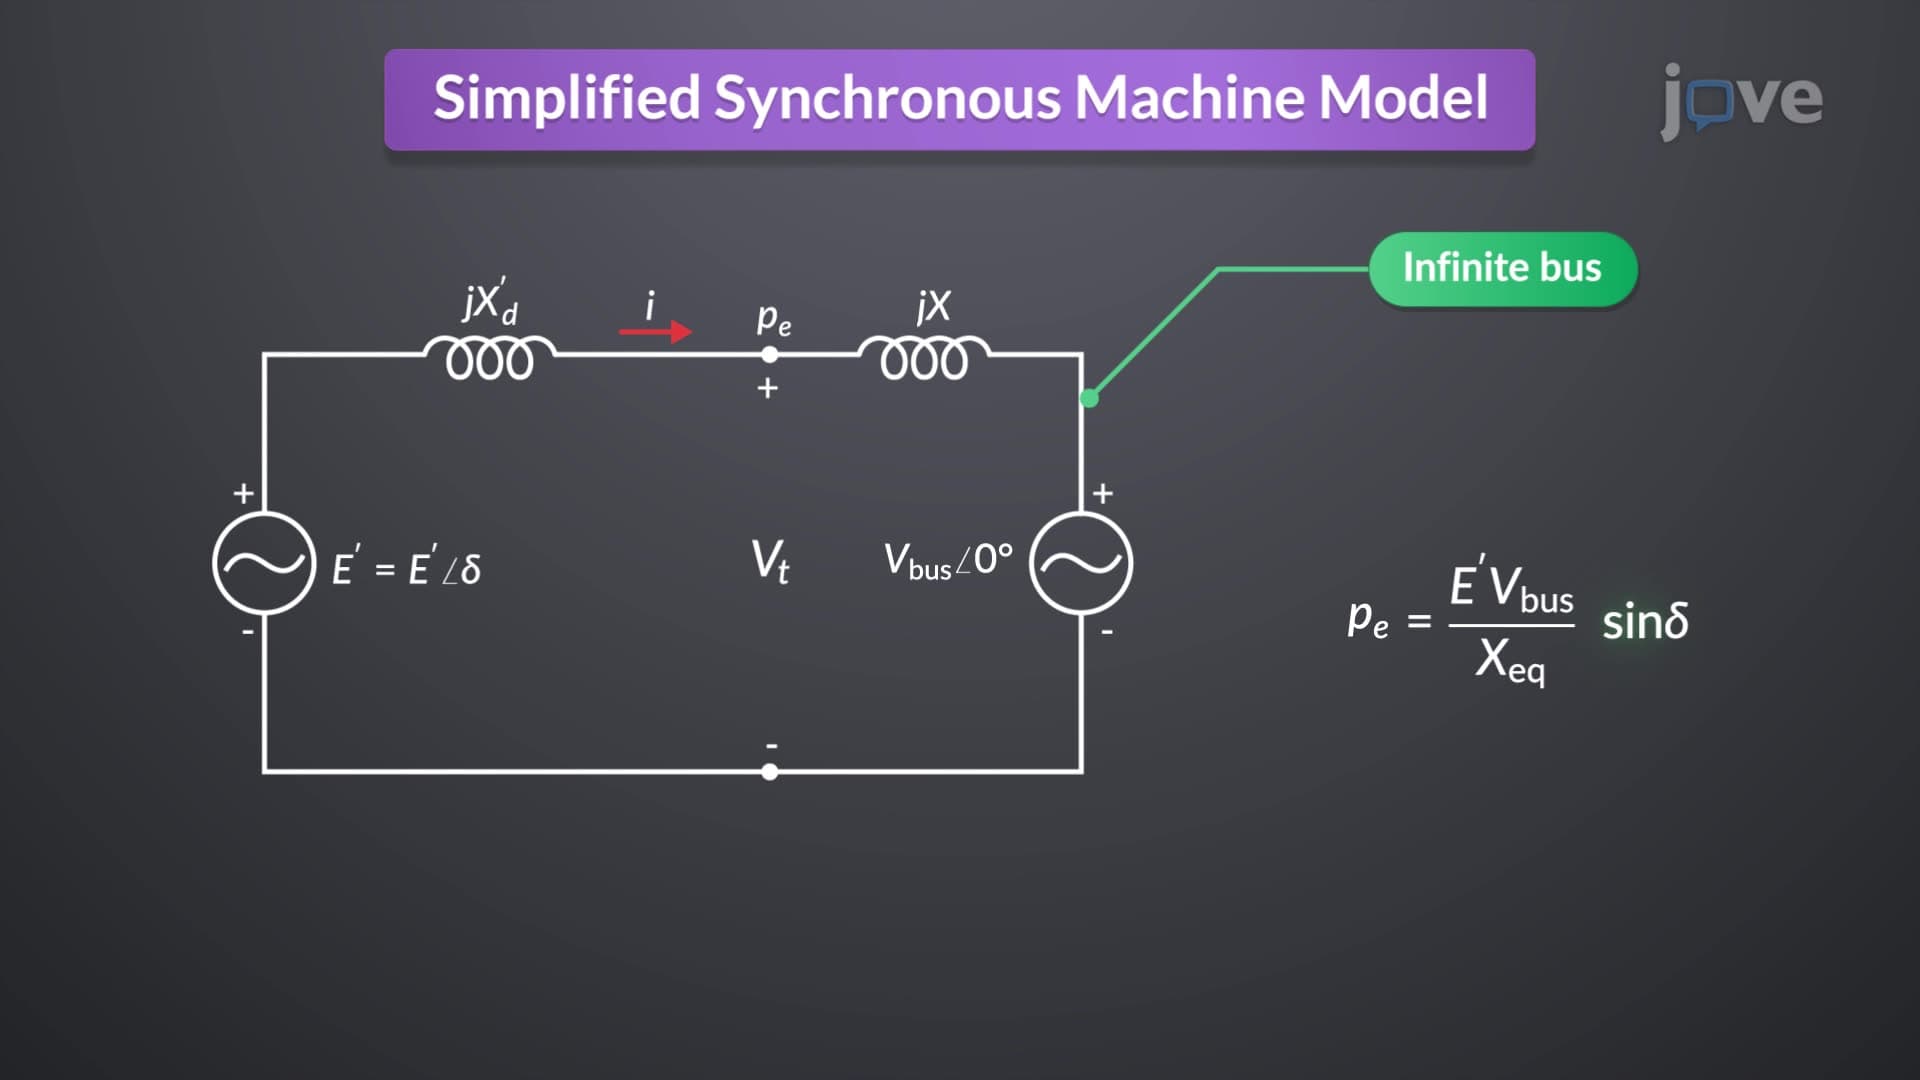
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...