Related Experiment Video
Updated: Nov 20, 2025
Picometer-Precision Atomic Position Tracking through Electron Microscopy
Published on: July 3, 2021
Fast and Robust Iterative Closest Point

Abstract:
The iterative closest point (ICP) algorithm and its variants are a fundamental technique for rigid registration between two point sets, with wide applications in different areas from robotics to 3D reconstruction. The main drawbacks for ICP are its slow convergence, as well as its sensitivity to outliers, missing data, and partial overlaps. Recent work such as Sparse ICP achieves robustness via sparsity optimization at the cost of computational speed. In this paper, we propose a new method for robust registration with fast convergence. First, we show that the classical point-to-point ICP can be treated as a majorization-minimization (MM) algorithm, and propose an Anderson acceleration approach to speed up its convergence. In addition, we introduce a robust error metric based on the Welsch's function, which is minimized efficiently using the MM algorithm with Anderson acceleration. On challenging datasets with noises and partial overlaps, we achieve similar or better accuracy than Sparse ICP while being at least an order of magnitude faster. Finally, we extend the robust formulation to point-to-plane ICP, and solve the resulting problem using a similar Anderson-accelerated MM strategy. Our robust ICP methods improve the registration accuracy on benchmark datasets while being competitive in computational time.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:19
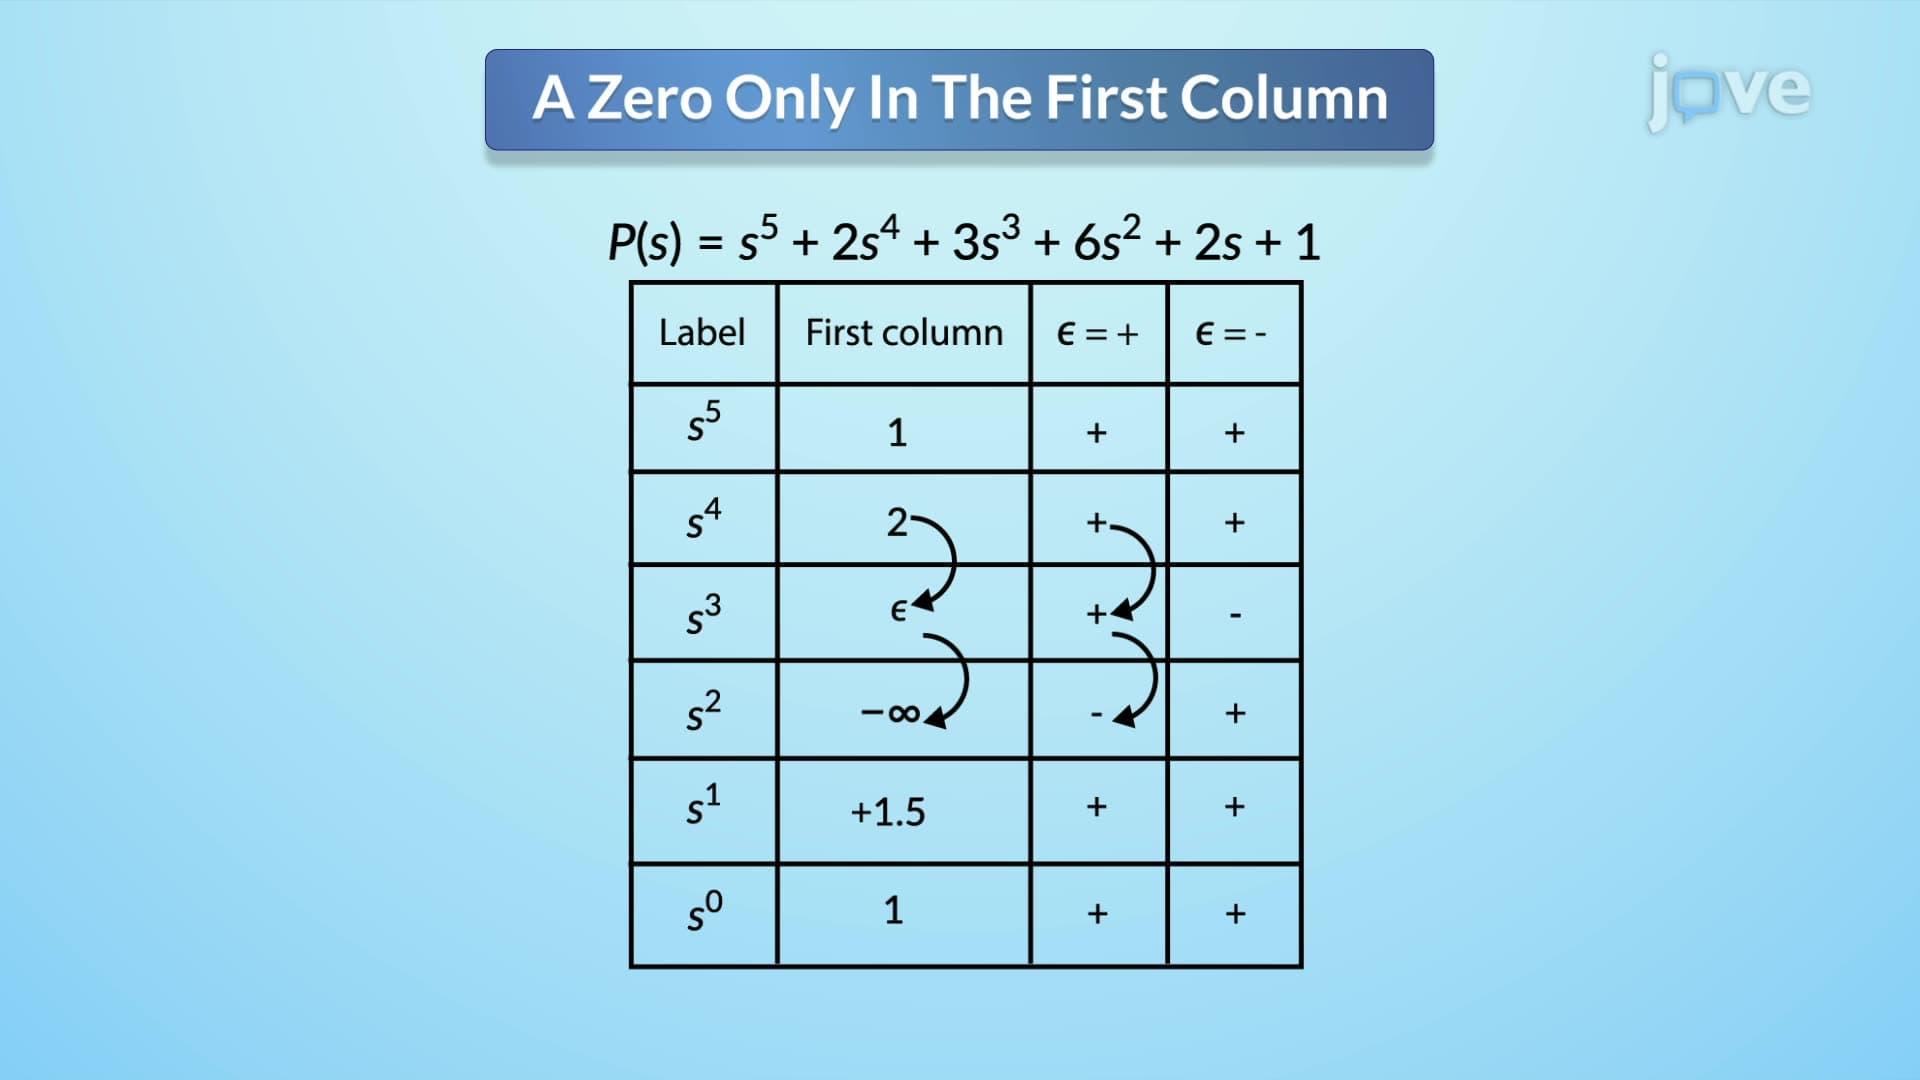
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...