Related Experiment Video
Updated: Jul 2, 2026


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Dynamic model and control for a cable-driven continuum manipulator used for minimally invasive surgery
Fei Qi1, Bai Chen2, Shuyuan Gao1
1School of Mechanical Engineering and Rail Transit, Changzhou University, Changzhou, Jiangsu Province, China.

Background:
Due to its unique flexible and dexterity, continuum robot has been widely used in small constrained environment. However, those advantages also bring that motion modelling and accurate control for the continuum robot is more complicated and tedious. A dynamic model and control strategy is presented for improving its control performance.
Methods:
The kinematics and velocity model of the robot are derived. The inertial force, elastic force, gravity and actuation force applied to the continuum robot are analysed. Meanwhile, the friction in drive system is investigated, and dynamic model is established by the Kane's method. Finally, a motion control strategy is proposed based on this model to verify the dynamic model.
Results:
Results of the simulation and experiment of a prototype verify the proposed model and its control method.
Conclusions:
The proposed model and control strategy can be used to achieve the bending deformation of the robot.


Related Concept Videos
 01:23
Simplification of a Force and Couple System: II
 01:19
Machines
A free-body diagram of the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:30
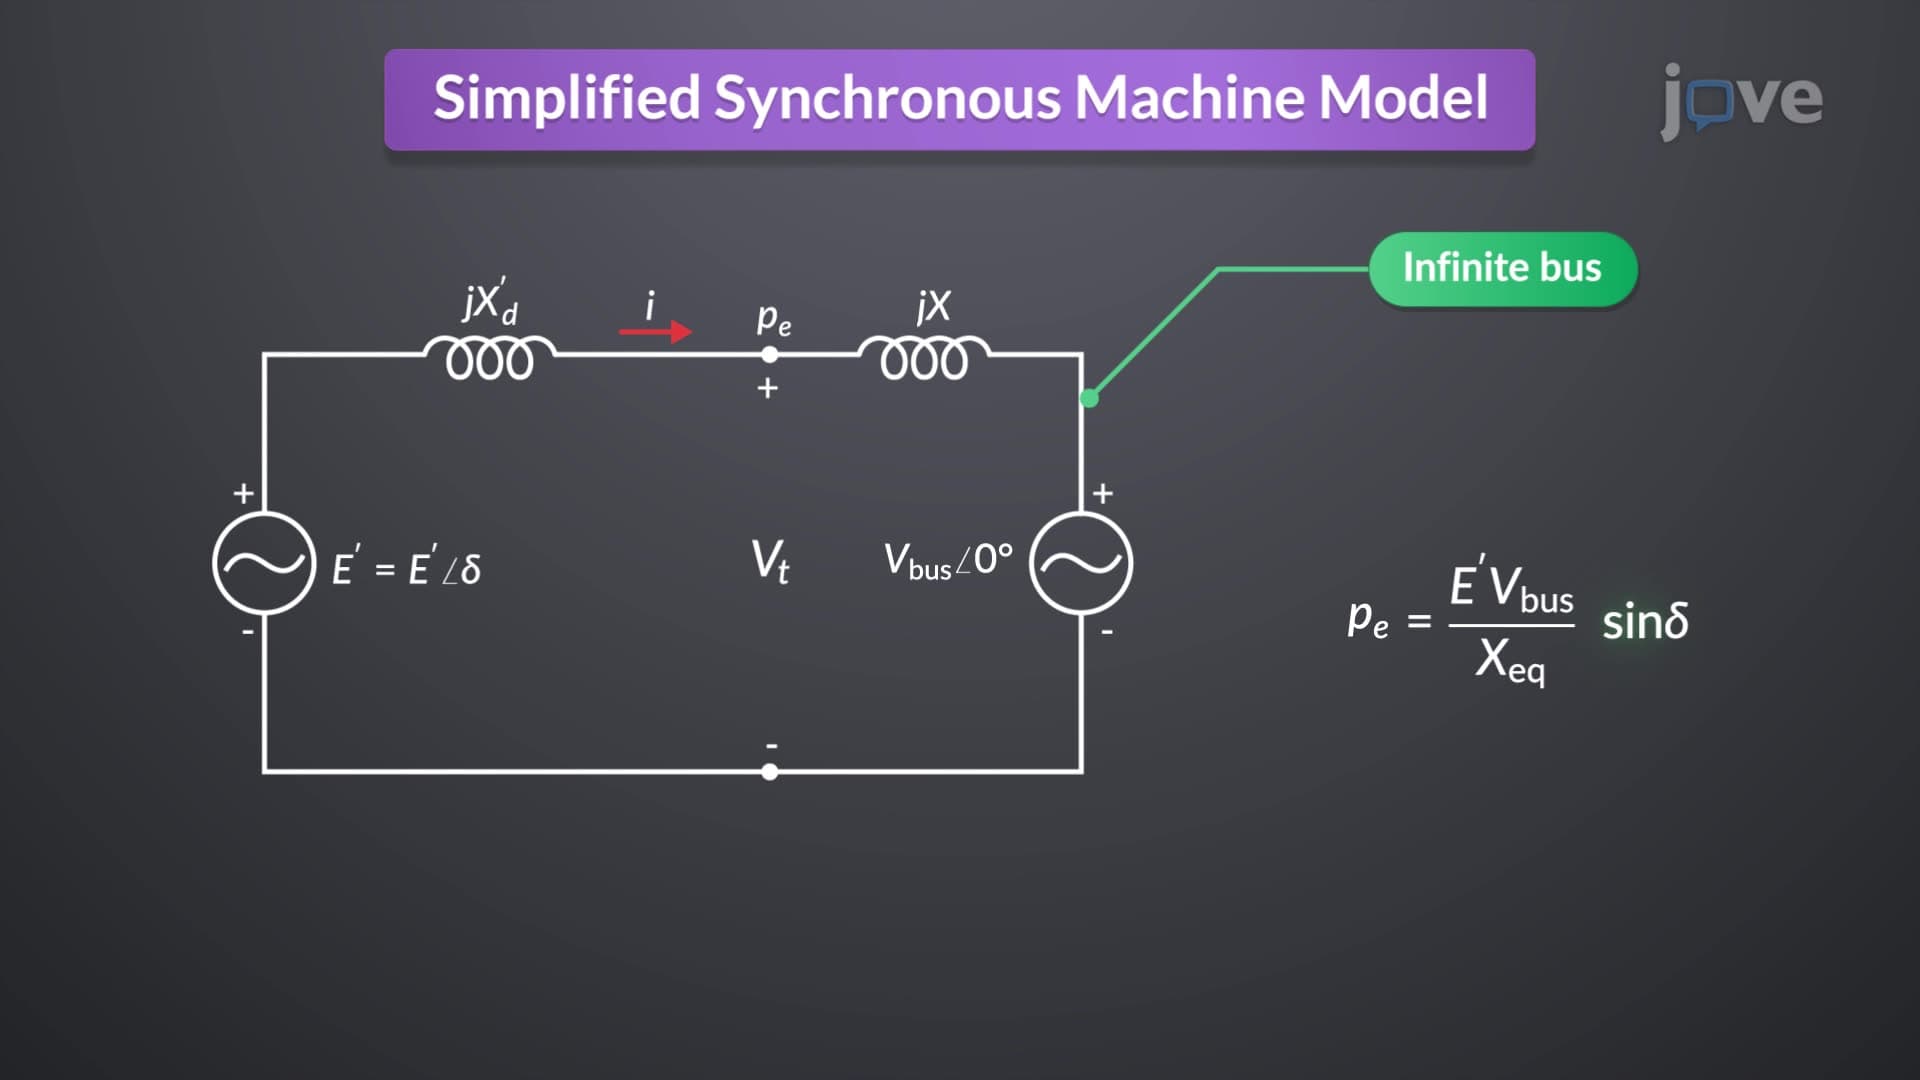
Simplified Synchronous Machine Model
In this model, each generator is connected to a...