Related Experiment Video
Updated: Nov 19, 2025


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Dynamic Morphological Computation Through Damping Design of Soft Continuum Robots
Antonio Di Lallo1,2, Manuel G Catalano3, Manolo Garabini1
1Dipartimento di Ingegneria dell'Informazione, Centro di Ricerca E. Piaggio, Università di Pisa, Pisa, Italy.

Abstract:
Inspired by nature, soft robotics aims at enhancing robots capabilities through the use of soft materials. This article presents the study of soft continuum robots which can change their dynamic behavior thanks to a proper design of their damping properties. It enables an under-actuated dynamic strategy to control multi-chamber pneumatic systems using a reduced number of feeding lines. The present work starts from the conceptual investigation of a way to tune the damping properties of soft continuum robots, and leverages on the introduction of viscous fluid within the soft chamber wall to produce dissipative actions. Several solutions are analyzed in simulations and the most promising one is tested experimentally. The proposed approach employs a layer of granular material immersed in viscous silicone oil to increase the damping effect. After validation and experimental characterization, the method is employed to build soft continuum actuators with different deformation patterns, i.e., extending, contracting and bending. Experimental results show the dynamic behavior of the presented actuators. Finally, the work reports information on how the actuators are designed and builded, together with a discussion about possible applications and uses.


Related Concept Videos
 01:20
Types of Damping
 01:07
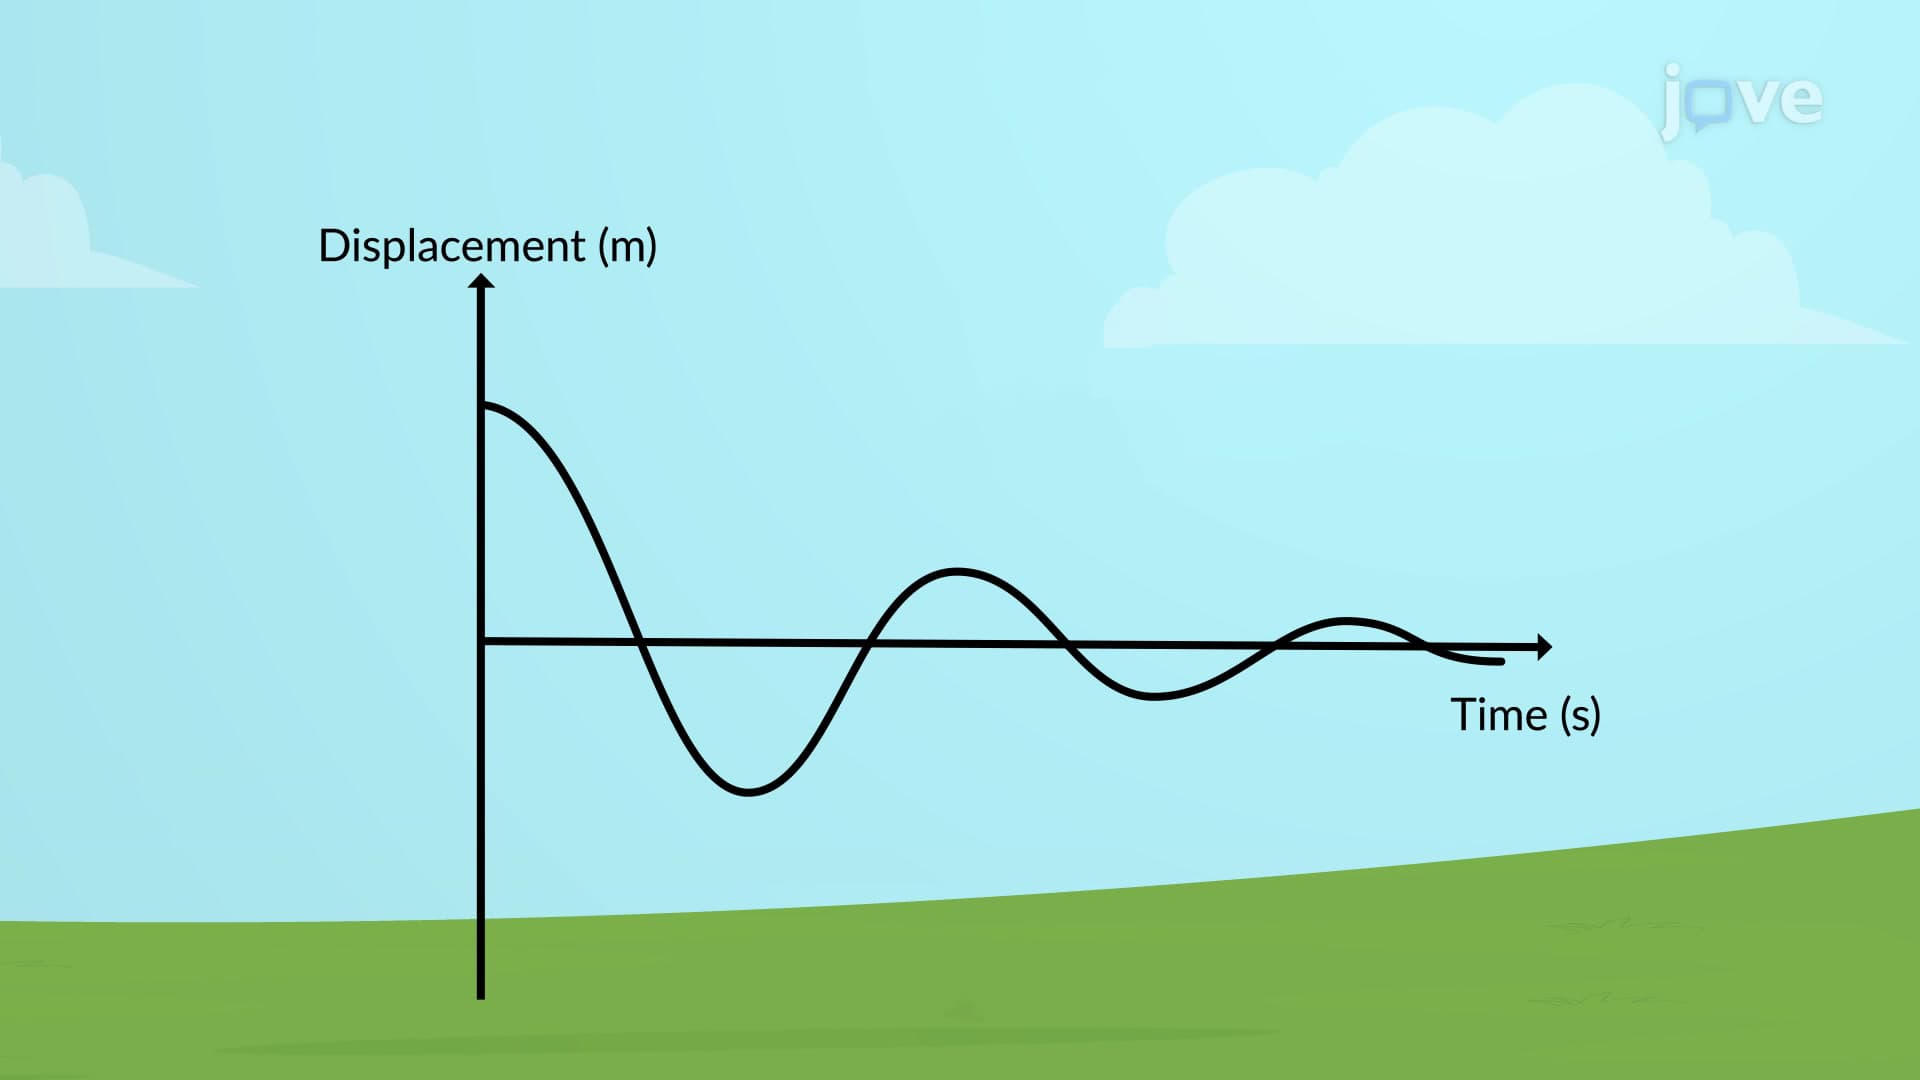
Damped Oscillations
Although friction and other non-conservative...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...