Related Experiment Video
Updated: Nov 18, 2025
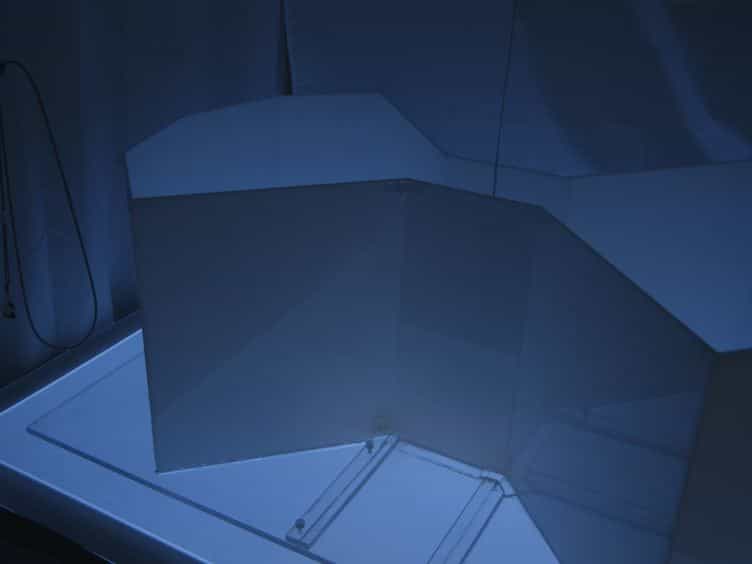

Automated Visual Cognitive Tasks for Recording Neural Activity Using a Floor Projection Maze
Published on: February 20, 2014
Multi-Task End-to-End Self-Driving Architecture for CAV Platoons
Sebastian Huch1,2, Aybike Ongel1, Johannes Betz3
1TUMCREATE, 1 CREATE Way, #10-02 CREATE Tower, Singapore 138602, Singapore.

Abstract:
Connected and autonomous vehicles (CAVs) could reduce emissions, increase road safety, and enhance ride comfort. Multiple CAVs can form a CAV platoon with a close inter-vehicle distance, which can further improve energy efficiency, save space, and reduce travel time. To date, there have been few detailed studies of self-driving algorithms for CAV platoons in urban areas. In this paper, we therefore propose a self-driving architecture combining the sensing, planning, and control for CAV platoons in an end-to-end fashion. Our multi-task model can switch between two tasks to drive either the leading or following vehicle in the platoon. The architecture is based on an end-to-end deep learning approach and predicts the control commands, i.e., steering and throttle/brake, with a single neural network. The inputs for this network are images from a front-facing camera, enhanced by information transmitted via vehicle-to-vehicle (V2V) communication. The model is trained with data captured in a simulated urban environment with dynamic traffic. We compare our approach with different concepts used in the state-of-the-art end-to-end self-driving research, such as the implementation of recurrent neural networks or transfer learning. Experiments in the simulation were conducted to test the model in different urban environments. A CAV platoon consisting of two vehicles, each controlled by an instance of the network, completed on average 67% of the predefined point-to-point routes in the training environment and 40% in a never-seen-before environment. Using V2V communication, our approach eliminates casual confusion for the following vehicle, which is a known limitation of end-to-end self-driving.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 00:46
Motor Units
 01:21
Distributed Loads: Problem Solving