Adapting Virtual Embodiment Through Reinforcement Learning
Related Experiment Video
Updated: Nov 18, 2025
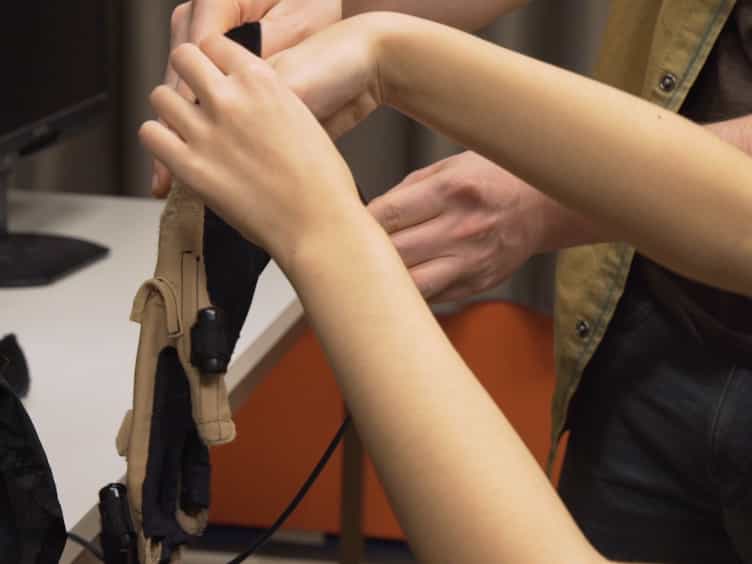
Creating Virtual-hand and Virtual-face Illusions to Investigate Self-representation
Published on: March 1, 2017

Abstract:
In Virtual Reality, having a virtual body opens a wide range of possibilities as the participant's avatar can appear to be quite different from oneself for the sake of the targeted application (e.g., for perspective-taking). In addition, the system can partially manipulate the displayed avatar movement through some distortion to make the overall experience more enjoyable and effective (e.g., training, exercising, rehabilitation). Despite its potential, an excessive distortion may become noticeable and break the feeling of being embodied into the avatar. Past researches have shown that individuals have a relatively high tolerance to movement distortions and a great variability of individual sensitivities to distortions. In this article, we propose a method taking advantage of Reinforcement Learning (RL) to efficiently identify the magnitude of the maximum distortion that does not get noticed by an individual (further noted the detection threshold). We show through a controlled experiment with subjects that the RL method finds a more robust detection threshold compared to the adaptive staircase method, i.e., it is more able to prevent subjects from detecting the distortion when its amplitude is equal or below the threshold. Finally, the associated majority voting system makes the RL method able to handle more noise within the forced choices input than adaptive staircase. This last feature is essential for future use with physiological signals as these latter are even more susceptible to noise. It would then allow to calibrate embodiment individually to increase the effectiveness of the proposed interactions.

Related Concept Videos
 01:12
Observational Learning
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:22
Purposive Learning
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:27
Associative Learning
Classical conditioning, also known...