Related Experiment Video
Updated: Nov 18, 2025
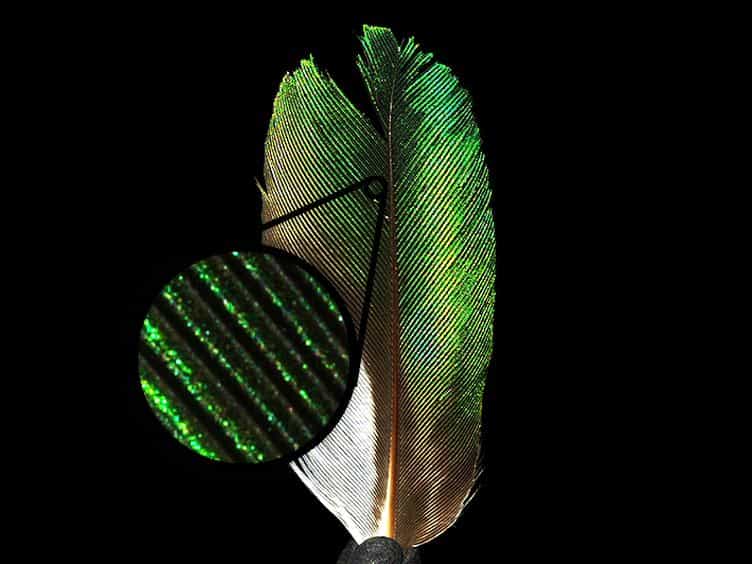
Measuring Spatially- and Directionally-varying Light Scattering from Biological Material
Published on: May 20, 2013
Extrinsic Camera Calibration with Line-Laser Projection
Izaak Van Crombrugge1, Rudi Penne1, Steve Vanlanduit1
1Faculty of Applied Engineering Department Electromechanics, Universiteit Antwerpen, Groenenborgerlaan 171, 2020 Antwerpen, Belgium.

Abstract:
Knowledge of precise camera poses is vital for multi-camera setups. Camera intrinsics can be obtained for each camera separately in lab conditions. For fixed multi-camera setups, the extrinsic calibration can only be done in situ. Usually, some markers are used, like checkerboards, requiring some level of overlap between cameras. In this work, we propose a method for cases with little or no overlap. Laser lines are projected on a plane (e.g., floor or wall) using a laser line projector. The pose of the plane and cameras is then optimized using bundle adjustment to match the lines seen by the cameras. To find the extrinsic calibration, only a partial overlap between the laser lines and the field of view of the cameras is needed. Real-world experiments were conducted both with and without overlapping fields of view, resulting in rotation errors below 0.5°. We show that the accuracy is comparable to other state-of-the-art methods while offering a more practical procedure. The method can also be used in large-scale applications and can be fully automated.
Related Concept Videos
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...