Related Experiment Video
Updated: Nov 18, 2025

A Methodology for Capturing Joint Visual Attention Using Mobile Eye-Trackers
Published on: January 18, 2020
Learning Local-Global Multiple Correlation Filters for Robust Visual Tracking with Kalman Filter Redetection
Jianming Zhang1, Yang Liu1, Hehua Liu1
1Hunan Provincial Key Laboratory of Intelligent Processing of Big Data on Transportation, School of Computer and Communication Engineering, Changsha University of Science and Technology, Changsha 410114, China.

Abstract:
Visual object tracking is a significant technology for camera-based sensor networks applications. Multilayer convolutional features comprehensively used in correlation filter (CF)-based tracking algorithms have achieved excellent performance. However, there are tracking failures in some challenging situations because ordinary features are not able to well represent the object appearance variations and the correlation filters are updated irrationally. In this paper, we propose a local-global multiple correlation filters (LGCF) tracking algorithm for edge computing systems capturing moving targets, such as vehicles and pedestrians. First, we construct a global correlation filter model with deep convolutional features, and choose horizontal or vertical division according to the aspect ratio to build two local filters with hand-crafted features. Then, we propose a local-global collaborative strategy to exchange information between local and global correlation filters. This strategy can avoid the wrong learning of the object appearance model. Finally, we propose a time-space peak to sidelobe ratio (TSPSR) to evaluate the stability of the current CF. When the estimated results of the current CF are not reliable, the Kalman filter redetection (KFR) model would be enabled to recapture the object. The experimental results show that our presented algorithm achieves better performances on OTB-2013 and OTB-2015 compared with the other latest 12 tracking algorithms. Moreover, our algorithm handles various challenges in object tracking well.
More Related Videos
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
 05:57
Long-term Video Tracking of Cohoused Aquatic Animals: A Case Study of the Daily Locomotor Activity of the Norway Lobster Nephrops norvegicus
Published on: April 8, 2019
Related Concept Videos
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:10
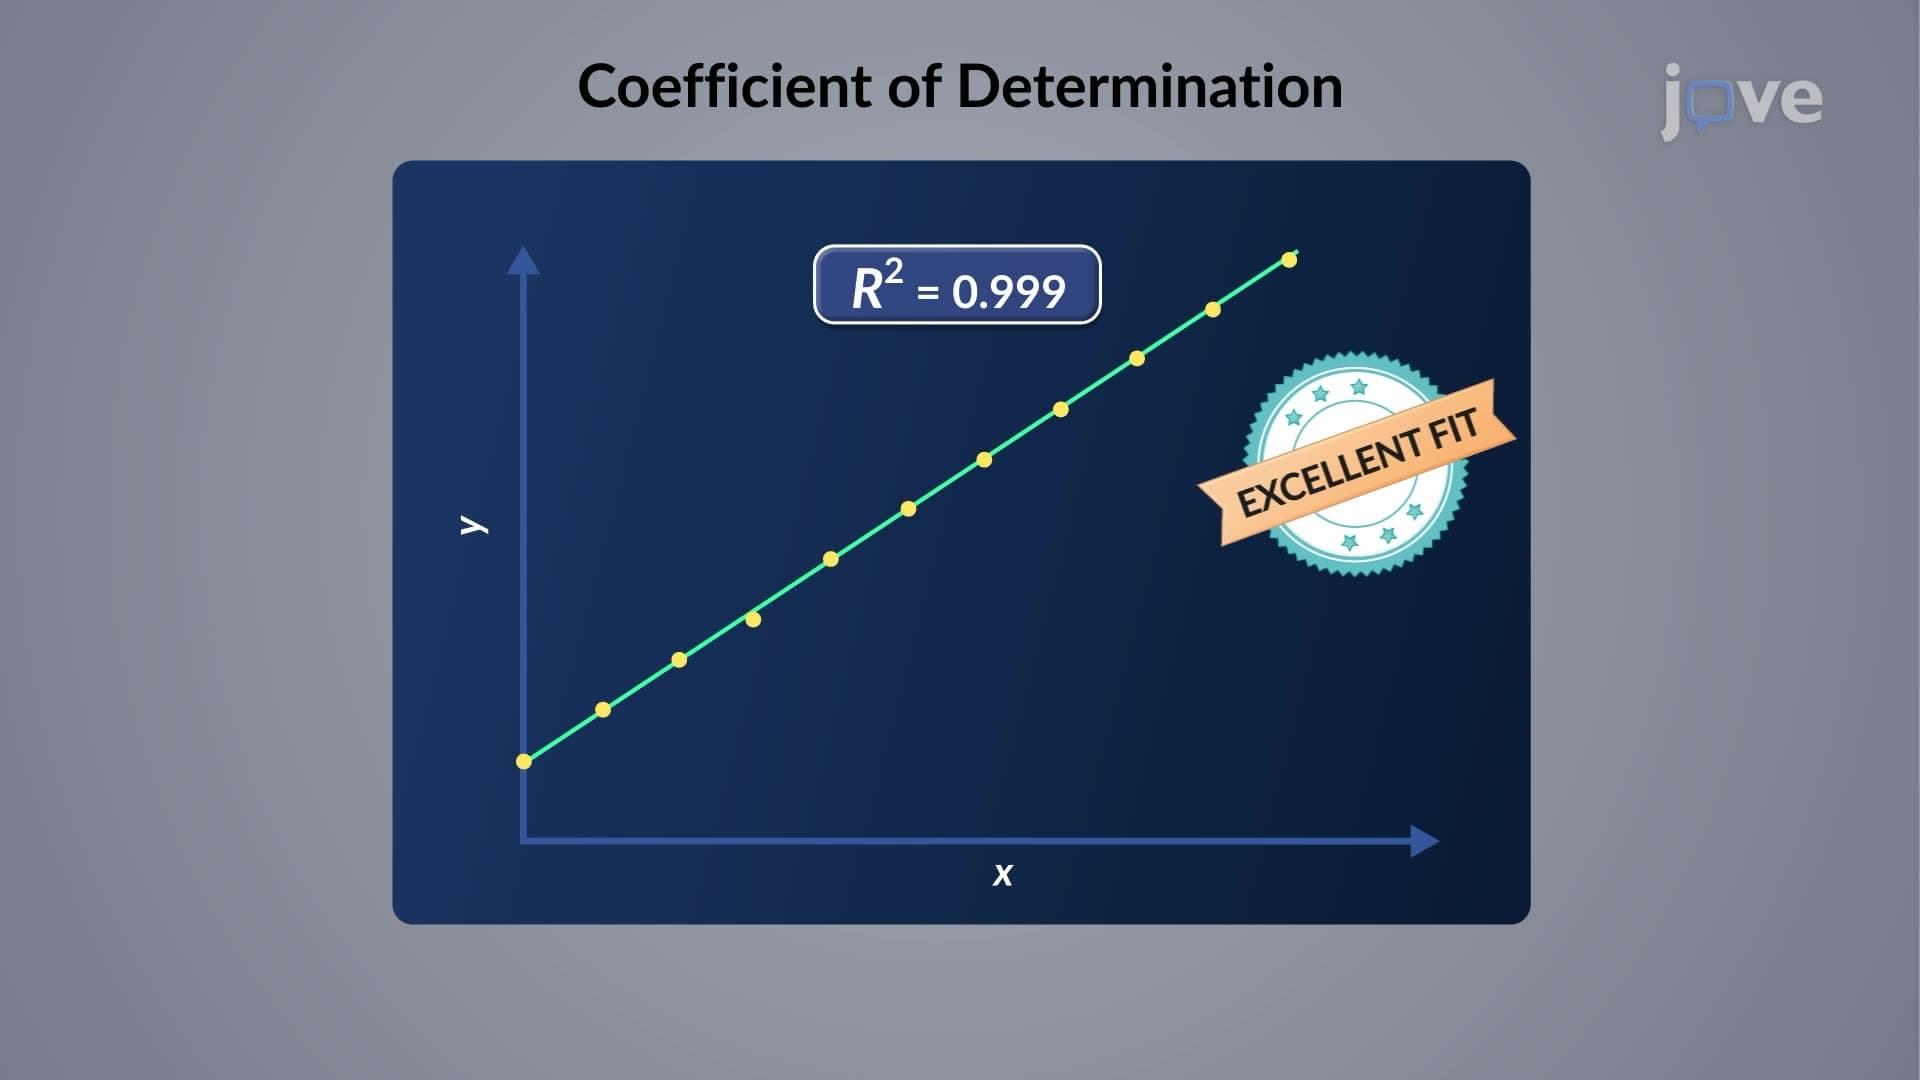
Calibration Curves: Correlation Coefficient
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Multi-input and Multi-variable systems
In the absence of...