Related Experiment Video
Updated: Nov 18, 2025
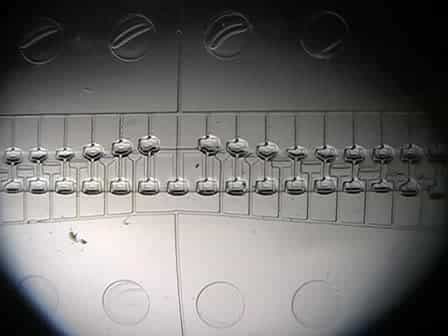

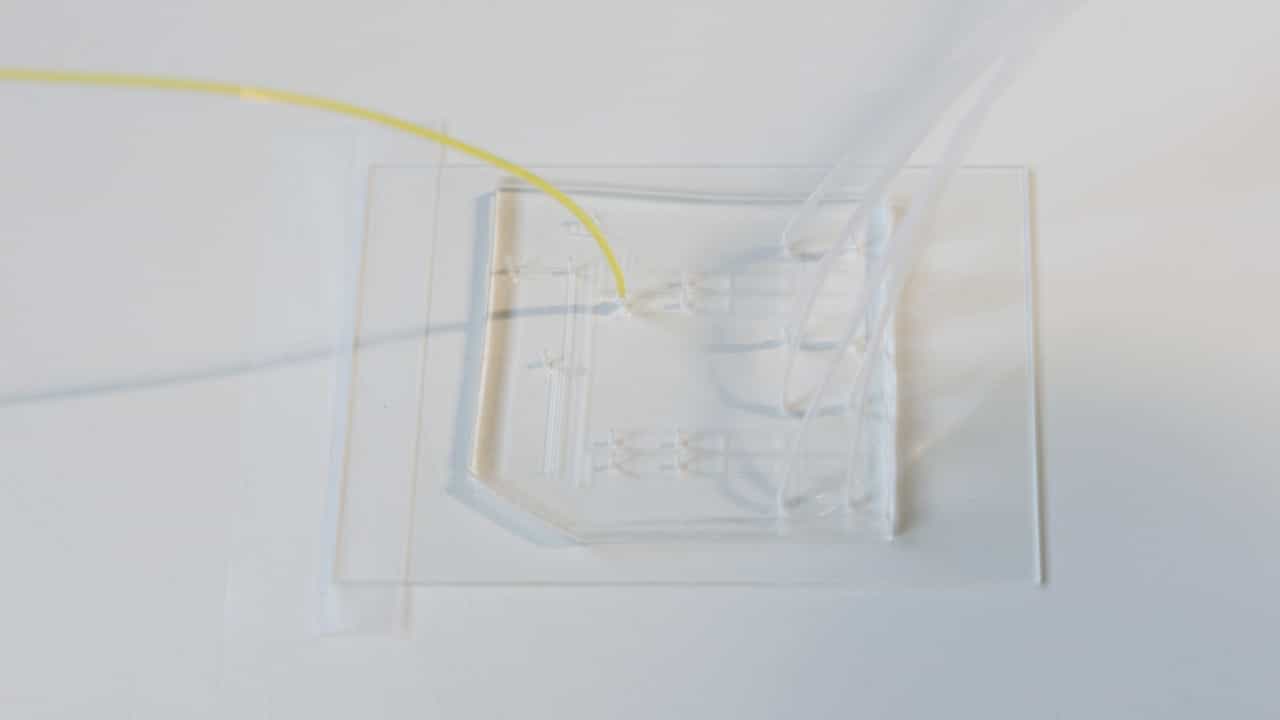
Microfluidic Chips Controlled with Elastomeric Microvalve Arrays
Published on: October 1, 2007
Synergizing microfluidics with soft robotics: A perspective on miniaturization and future directions
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, Waterloo, Ontario N2L 3G1, Canada.

Abstract:
Soft robotics has gone through a decade of tremendous progress in advancing both fundamentals and technologies. It has also seen a wide range of applications such as surgery assistance, handling of delicate foods, and wearable assistive systems driven by its soft nature that is more human friendly than traditional hard robotics. The rapid growth of soft robotics introduces many challenges, which vary with applications. Common challenges include the availability of soft materials for realizing different functions and the precision and speed of control required for actuation. In the context of wearable systems, miniaturization appears to be an additional hurdle to be overcome in order to develop truly impactful systems with a high user acceptance. Microfluidics as a field of research has gone through more than two decades of intense and focused research resulting in many fundamental theories and practical tools that have the potentials to be applied synergistically to soft robotics toward miniaturization. This perspective aims to introduce the potential synergy between microfluidics and soft robotics as a research topic and suggest future directions that could leverage the advantages of the two fields.