Related Experiment Video
Updated: Nov 17, 2025


Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Nonlinear electromechanical modeling and robustness of soft robotic fish-like energy harvester: insights and possible
1Department of Mechanical and Aerospace Engineering, New Mexico State University, Las Cruces, NM 88003, United States of America.

Abstract:
This work investigates the possible integration of an energy harvester in a bioinspired fish-like aquatic unmanned vehicle. The defined fish-like system utilizes a reduced complexity prescribed motion as the representation for energy harvester to be subjected to. Nonlinear electromechanical modeling is performed by considering the geometric and piezoelectric nonlinearities. A convergence analysis is carried out in order to determine the required modes in the Galerkin discretization due to the presence of nonlinear interactions between the prescribed and relative motions. The utilization of higher-order modeling for the strain and material leads to the identification of impactful prescribed motions terms that can activate the nonlinearities in the system, results in more harmonics to consider, and leads to the presence parametric excitation terms. Considering a reduced-complex model by decreasing the value of the quadratic constraint envelope that the fish-like system would be forced with, the soft-robotic system behaves more with a base excitation characteristic. Small damping would allow this prescribed motion with reduced quadratic envelope forcing still induces a hardening behavior, but the other harmonics and parametric resonance seen are greatly reduced. Considering this reduced complexity system, the interaction between the prescribed and base excitations is also investigated to demonstrate that when the two excitations are of similar nature constructive and destructive build of the response waveform can occur when looking at near the first natural resonance. It is shown that the quenching phenomenon can take place which may result in a destructive response of the piezoelectric energy harvester. The results show that the robustness of the fish-like robot is directly dependent on the design parameters including the damping of the structure, importance of the undulatory motion, and activation of the resonances.
Related Concept Videos
 01:10
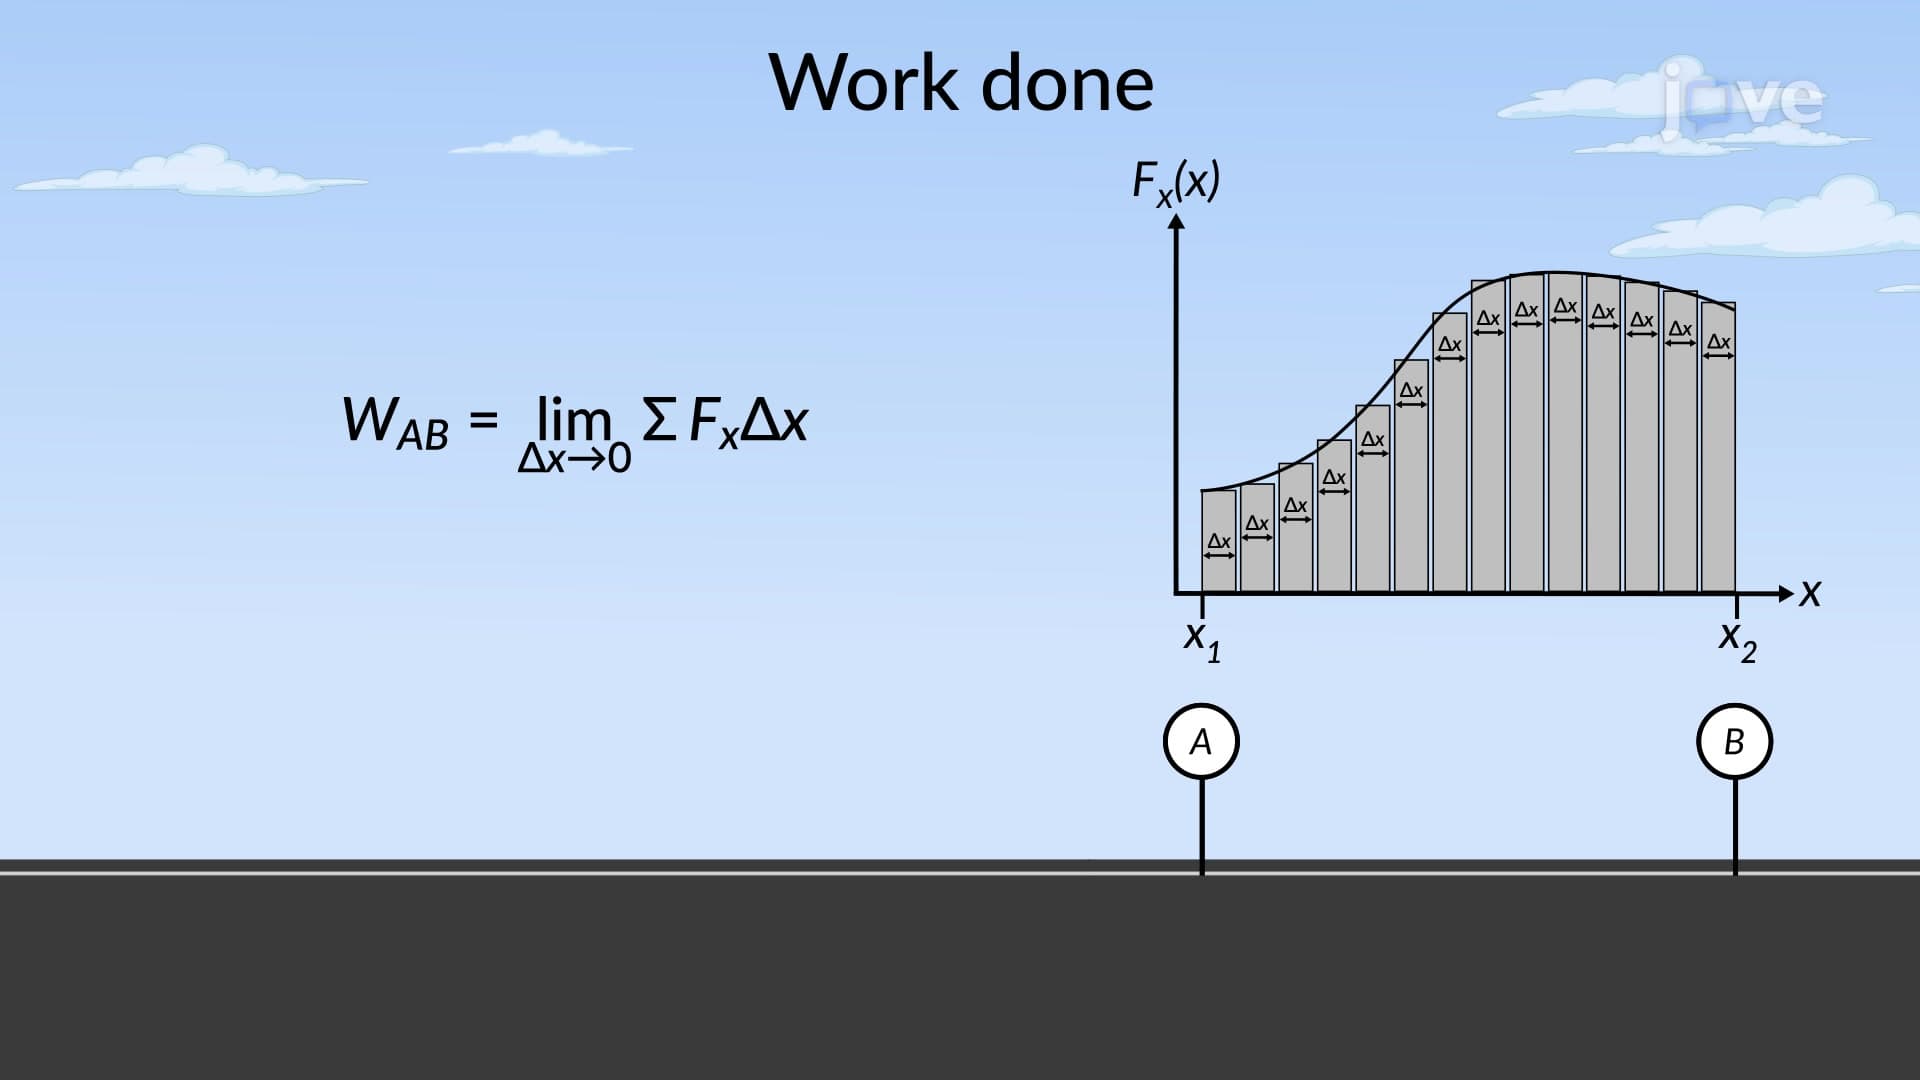
Work and Energy for Variable Forces
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:17
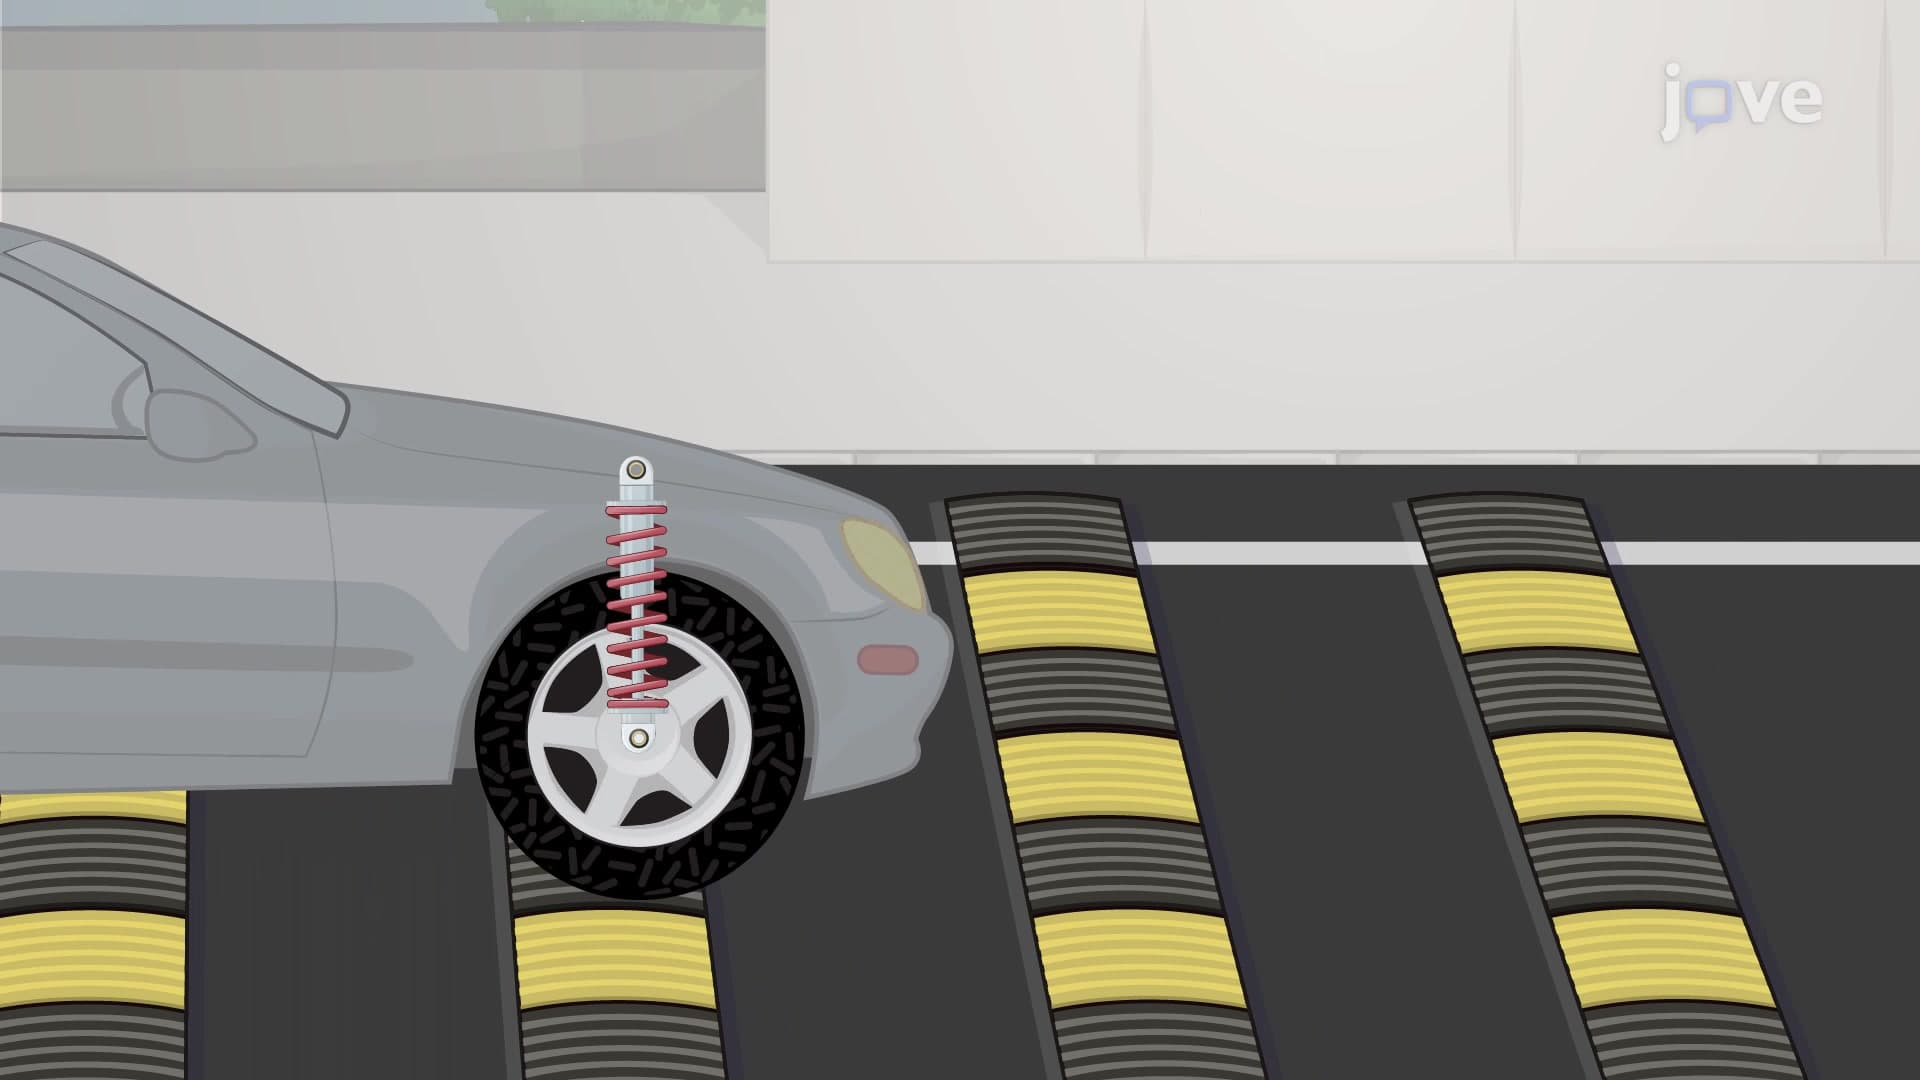
Problem Solving: Energy in Simple Harmonic Motion
Consider the spring in a shock absorber of a car. The spring attached to the wheel executes simple harmonic motion while the car is moving on a bumpy road. The force on the...
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...