Related Experiment Video
Updated: Aug 26, 2026
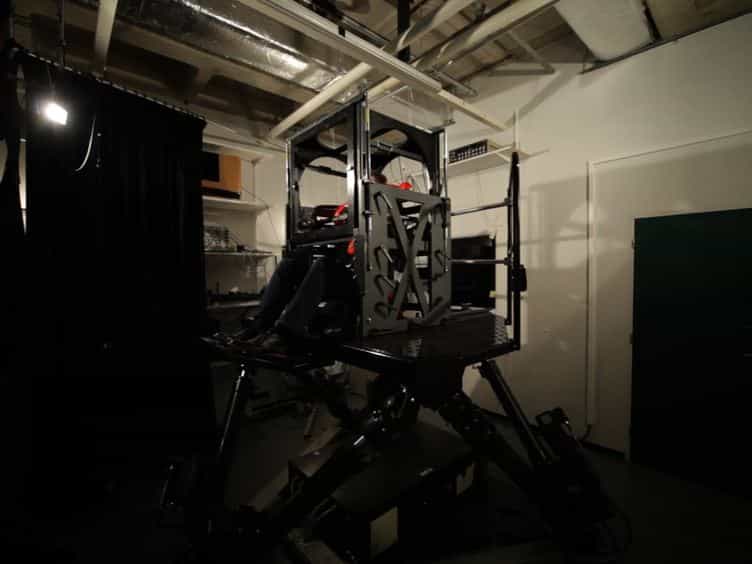

Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Finding motion parameters from spherical motion fields (or the advantages of having eyes in the back of your head)
1Computer Vision Laboratory, University of Maryland, College Park 20742.

Abstract:
A theory is developed for determining the motion of an observer given the motion field over a full 360 degree image sphere. The method is based on the fact that for an observer translating without rotation, the projected circular motion field about any equator can be divided into disjoint semicircles of clockwise and counterclockwise flow, and on the observation that the effects of rotation decouple around the three equators defining the three principal axes of rotation. Since the effect of rotation is geometrical, the three rotational parameters can be determined independently by searching, in each case, for a rotational value for which the derotated equatorial motion field can be partitioned into 180 degree arcs of clockwise and counterclockwise flow. The direction of translation is also obtained from this analysis. This search is two dimensional in the motion parameters, and can be performed relatively efficiently. Because information is correlated over large distances, the method can be considered a pattern recognition rather than a numerical algorithm. The algorithm is shown to be robust and relatively insensitive to noise and to missing data. Both theoretical and empirical studies of the error sensitivity are presented. The theoretical analysis shows that for white noise of bounded magnitude M, the expected errors is at worst linearly proportional to M. Empirical tests demonstrate negligible error for perturbations of up to 20% in the input, and errors of less than 20% for perturbations of up to 200%.
More Related Videos
Related Concept Videos
 01:23
Spherical Coordinates
 01:17
Accessory Structures of the Eye
 01:15
Equilibrium and Balance
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...
 01:15
Depth Perception and Spatial Vision