Related Experiment Video
Updated: Nov 16, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Grip Force Control During Virtual Interaction With Deformable and Rigid Objects Via a Haptic Gripper

Abstract:
Most studies of grip force control focus on the manipulation of rigid objects. However, in virtual and teleoperation applications, objects are often elastic in the pinch degree-of-freedom, and are manipulated using a handle that presents haptic feedback to the user. When designing controllers for haptic grippers, it is crucial to understand how grip force is controlled when manipulating rigid and deformable objects. Here, we used a virtual teleoperation setup with a haptic gripper interface to investigate grip force control in virtual environments. Ten participants lifted virtual objects and performed vertical, cyclic motions using a haptic gripper. We manipulated the control signal to the virtual interface, the haptic properties of the gripper, and the visual properties of the virtual objects to test their effect on the grip force control. We found that participants modulated their grip force as a function of the anticipated load force in all of the experimental conditions. The control signal and properties of the haptic gripper, but not the visual properties of the objects, affected the baseline and the extent of the grip force modulation. These results can provide design guidelines for haptic grippers that elicit natural grasping in virtual and bilateral teleoperation applications.

Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:07
Frictional Force
 01:05
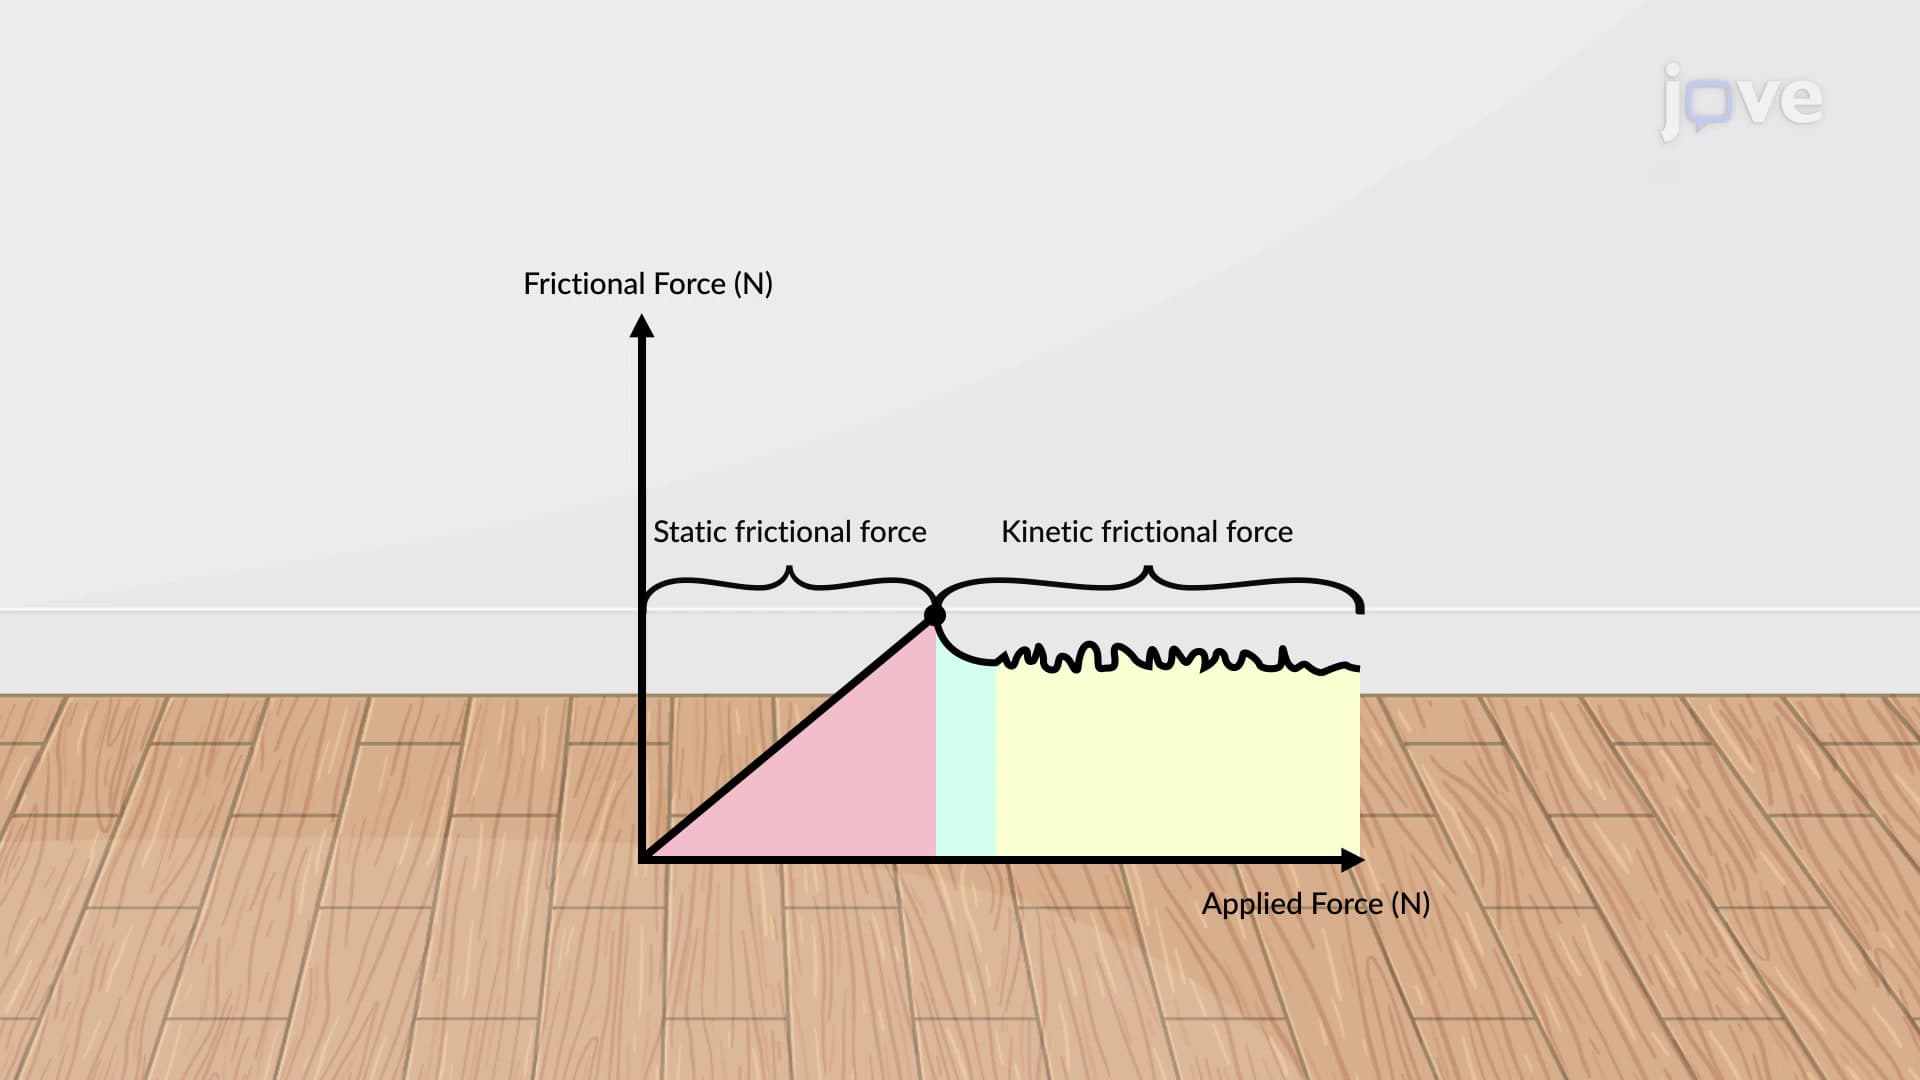
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:17
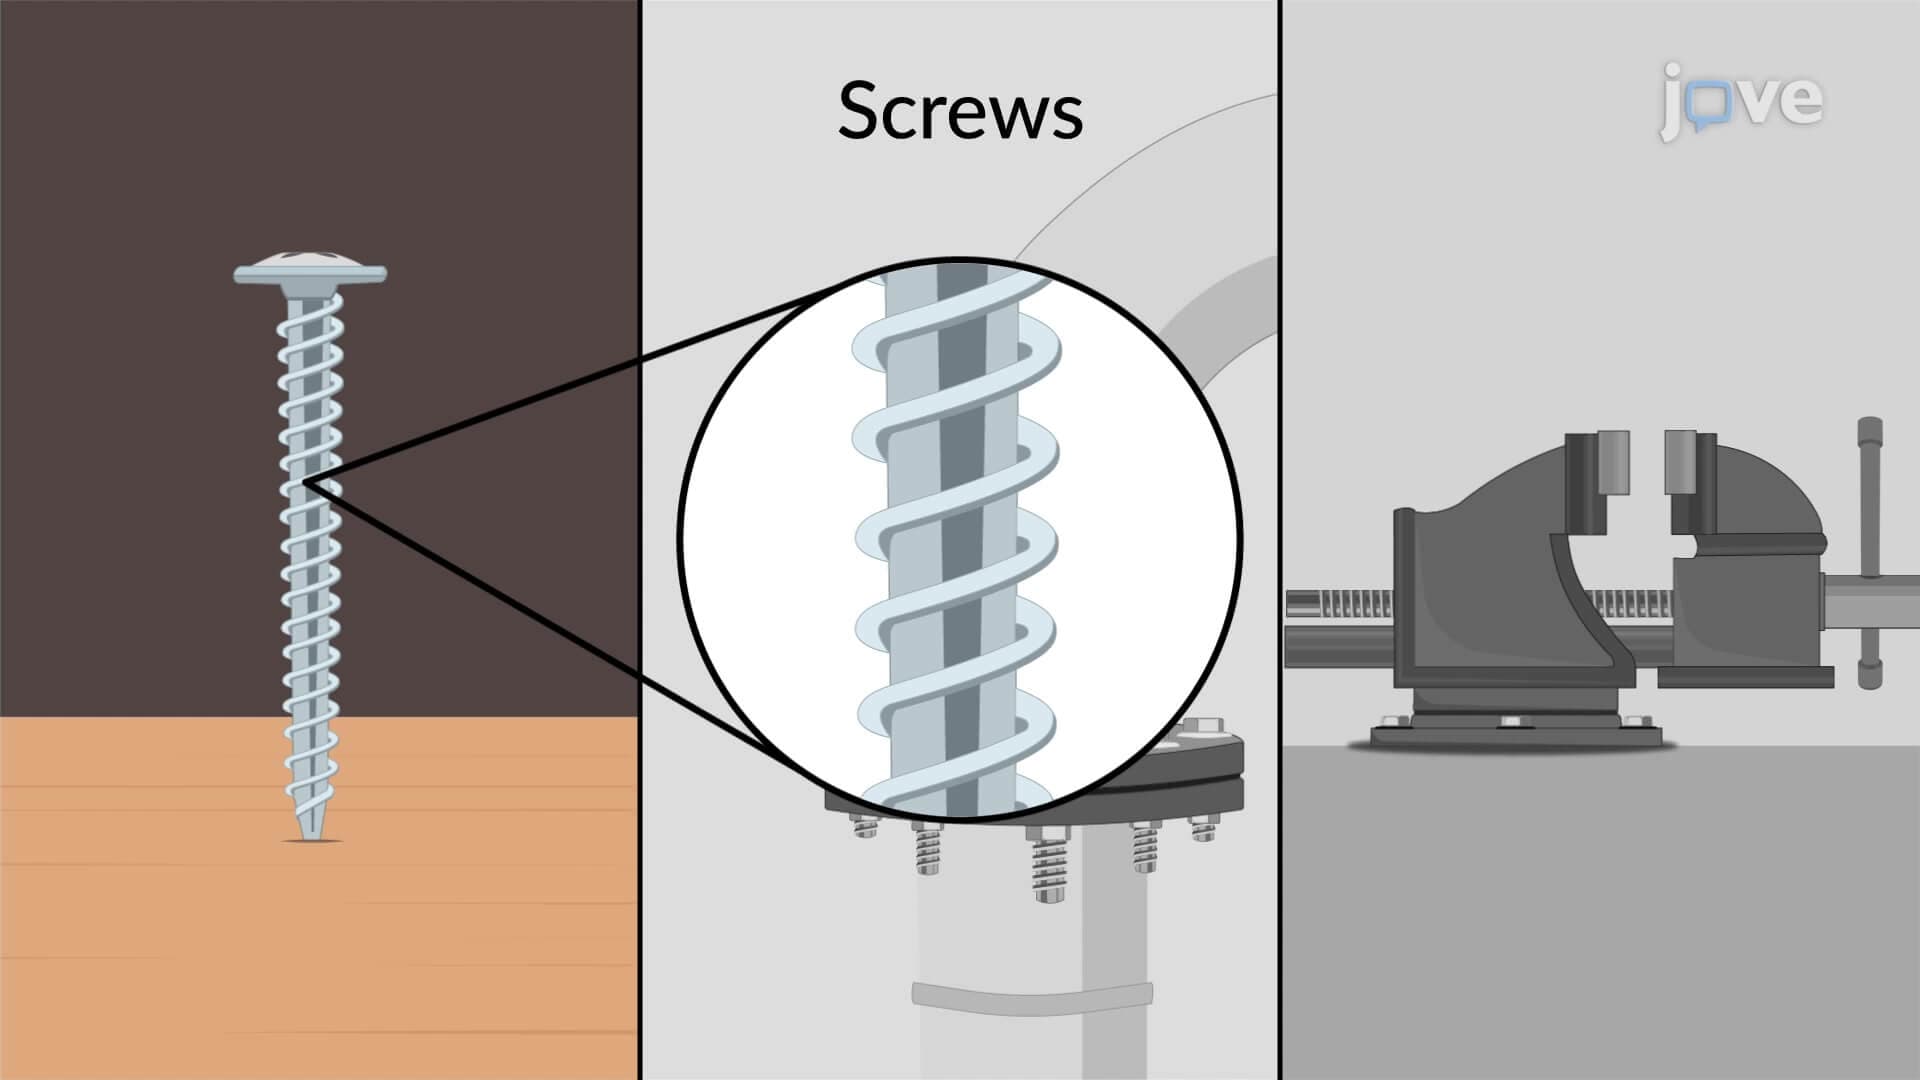
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...