Related Experiment Video
Updated: Nov 16, 2025

A Tactile Automated Passive-Finger Stimulator TAPS
Published on: June 3, 2009
Role of Tactile Noise in the Control of Digit Normal Force
Abdeldjallil Naceri1, Yasemin B Gultekin2,3, Alessandro Moscatelli4,5
1Advanced Robotics Department, Italian Institute of Technology, Genoa, Italy.

Abstract:
Whenever we grasp and lift an object, our tactile system provides important information on the contact location and the force exerted on our skin. The human brain integrates signals from multiple sites for a coherent representation of object shape, inertia, weight, and other material properties. It is still an open question whether the control of grasp force occurs at the level of individual fingers or whether it is also influenced by the control and the signals from the other fingers of the same hand. In this work, we approached this question by asking participants to lift, transport, and replace a sensorized object, using three- and four-digit grasp. Tactile input was altered by covering participant's fingertips with a rubber thimble, which reduced the reliability of the tactile sensory input. In different experimental conditions, we covered between one and three fingers opposing the thumb. Normal forces at each finger and the thumb were recorded while grasping and holding the object, with and without the thimble. Consistently with previous studies, reducing tactile sensitivity increased the overall grasping force. The gasping force increased in the covered finger, whereas it did not change from baseline in the remaining bare fingers (except the thumb for equilibrium constraints). Digit placement and object tilt were not systematically affected by rubber thimble conditions. Our results suggest that, in each finger opposing thumb, digit normal force is controlled locally in response to the applied tactile perturbation.
Related Concept Videos
 01:30
Dry Friction
To illustrate this concept, imagine a wooden crate resting on a rough, non-uniform horizontal surface. When an external force is applied to...
 01:33
Somatosensation
 01:05
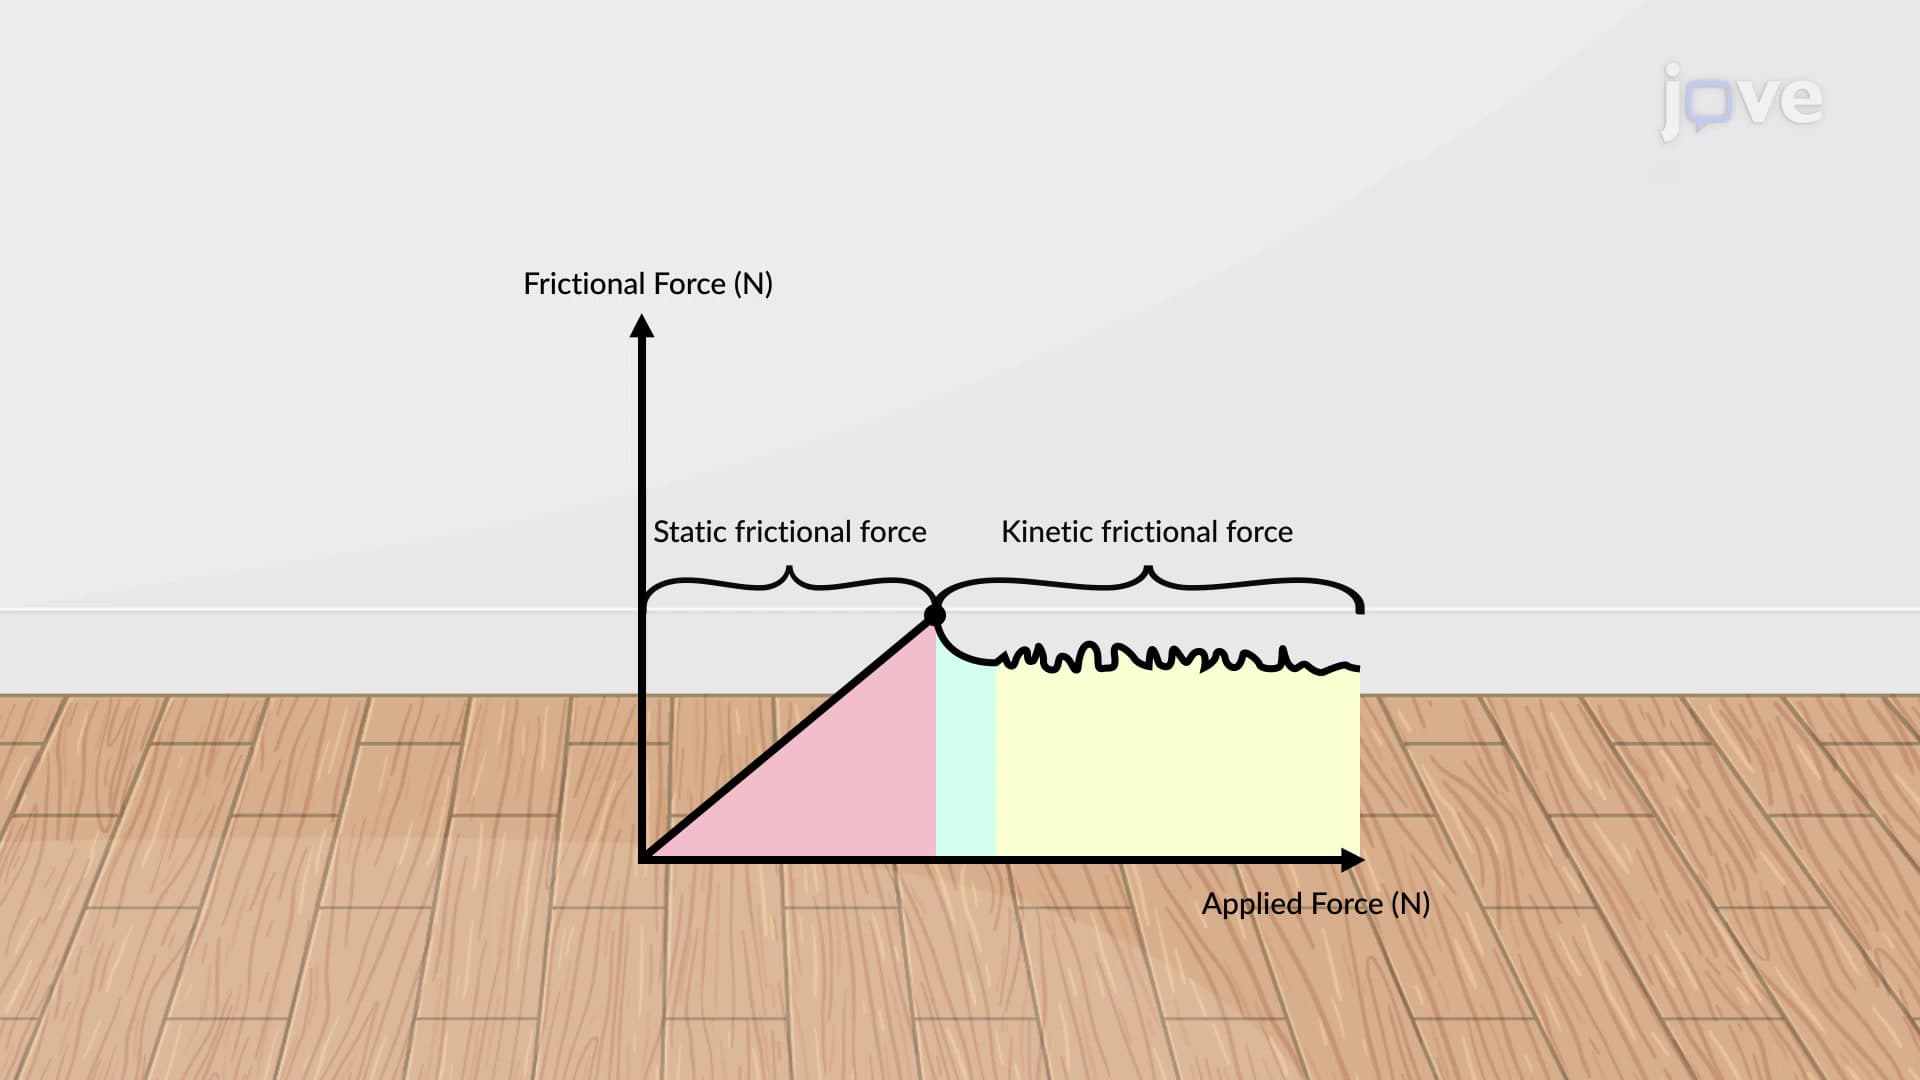
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:07
Frictional Force
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:27
Tactile and Chemical Senses