Related Experiment Video
Updated: Aug 11, 2026

Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
A Gas-Ribbon-Hybrid Actuated Soft Finger with Active Variable Stiffness
Xinbin Zhang1, Jihong Yan1, Jie Zhao2
1Laboratory for Space Environment and Physical Sciences and Harbin Institute of Technology, Harbin, China.

Abstract:
A new hybrid actuated soft finger with active variable stiffness is proposed for the first time by integrating gas-driven and ribbon-driven mechanisms. By carefully coordinating the two mechanisms, the bending deformation and the stiffness modulation processes of the soft finger can be uncoupled, providing it with both high flexibility and good variable stiffness. Although the soft finger, made entirely from flexible materials, works under a low and safe gas pressure of below 35 kPa, the maximum bending angle reaches ∼210°, and a single soft finger can withstand a weight of 1.25 kg. For any bending angle, with the help of the ribbon-driven mechanism, the stiffness of the soft finger can increase by three to six times. In addition, theoretical models are established for the evaluation of the bending-deformation characteristic and the output force of the soft finger, which are verified by experiments. A dual-finger soft robotic gripper is assembled by utilizing two soft fingers, which can easily and stably grab various objects with different sizes, shapes, and weights. Both the theoretical and experimental results indicate that the proposed gas-ribbon-hybrid actuated mechanism can effectively enhance the variable stiffness property of a soft finger while retaining its good compliance with the surroundings. This work might provide future insights for the development of compact and cost-effective soft end effectors with active variable stiffness.

Related Concept Videos
 01:05
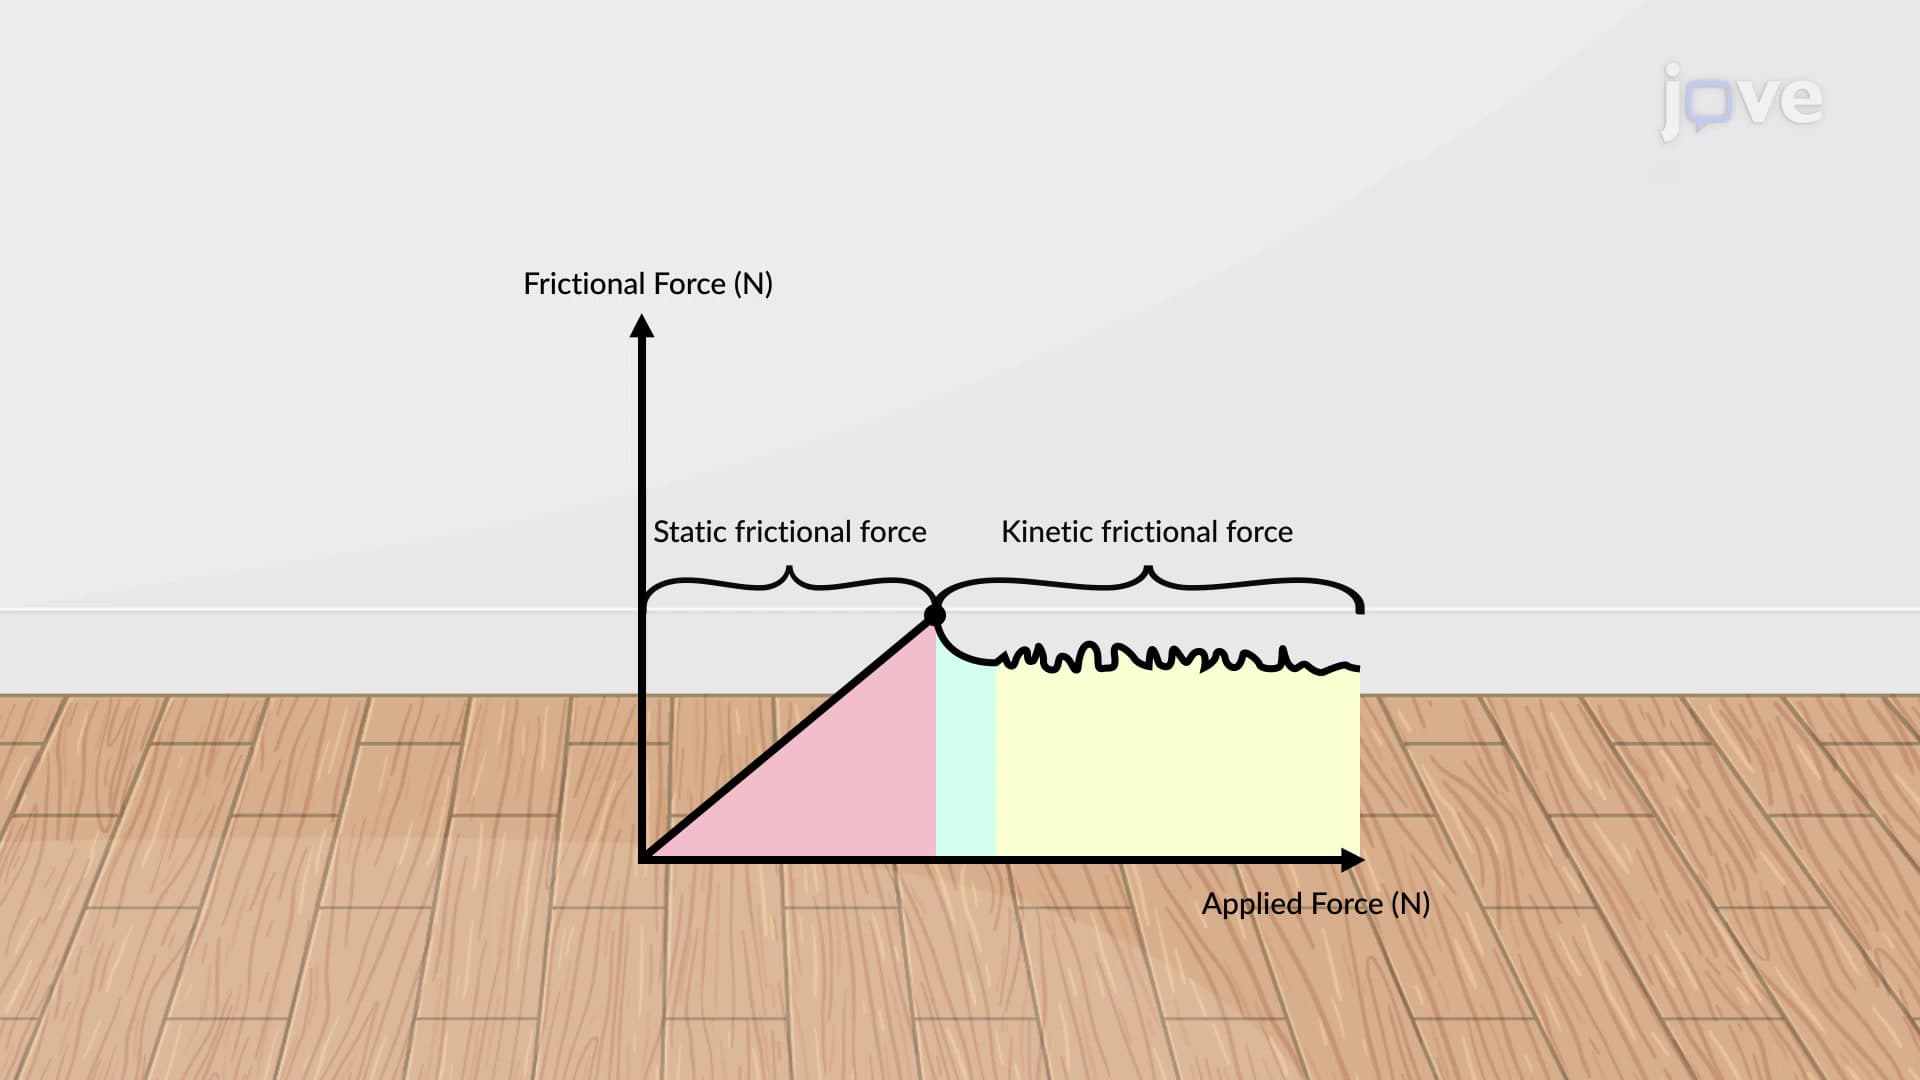
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:26
Kinetic Friction
 01:22
Mechanical Systems