Related Experiment Video
Updated: Nov 15, 2025
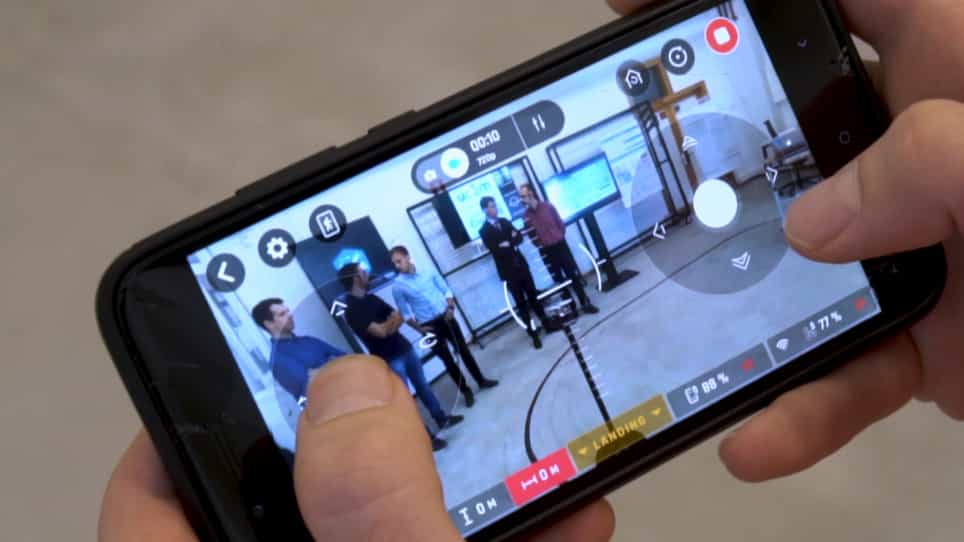
Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
A Robot Operating System Framework for Secure UAV Communications
Hyojun Lee1, Jiyoung Yoon2, Min-Seong Jang1
1Department of Information and Communication Engineering, Daegu Gyeongbuk Institute of Science and Technology, Daegu 42988, Korea.

Abstract:
To perform advanced operations with unmanned aerial vehicles (UAVs), it is crucial that components other than the existing ones such as flight controller, network devices, and ground control station (GCS) are also used. The inevitable addition of hardware and software to accomplish UAV operations may lead to security vulnerabilities through various vectors. Hence, we propose a security framework in this study to improve the security of an unmanned aerial system (UAS). The proposed framework operates in the robot operating system (ROS) and is designed to focus on several perspectives, such as overhead arising from additional security elements and security issues essential for flight missions. The UAS is operated in a nonnative and native ROS environment. The performance of the proposed framework in both environments is verified through experiments.
More Related Videos

Related Concept Videos
 01:24
PI Controller: Design
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:10
Control Systems
At the heart...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...