Related Experiment Video
Updated: Nov 11, 2025
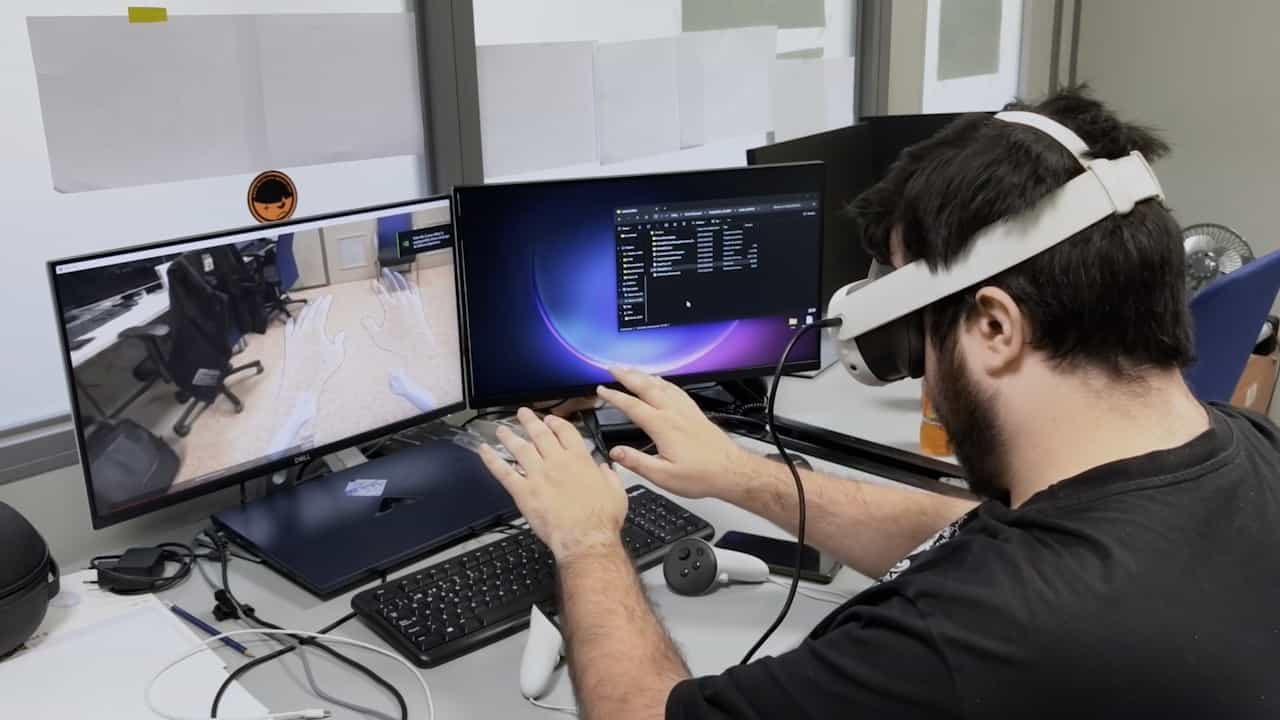
Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
Instant Panoramic Texture Mapping with Semantic Object Matching for Large-Scale Urban Scene Reproduction

Abstract:
This paper proposes a novel panoramic texture mapping-based rendering system for real-time, photorealistic reproduction of large-scale urban scenes at a street level. Various image-based rendering (IBR) methods have recently been employed to synthesize high-quality novel views, although they require an excessive number of adjacent input images or detailed geometry just to render local views. While the development of global data, such as Google Street View, has accelerated interactive IBR techniques for urban scenes, such methods have hardly been aimed at high-quality street-level rendering. To provide users with free walk-through experiences in global urban streets, our system effectively covers large-scale scenes by using sparsely sampled panoramic street-view images and simplified scene models, which are easily obtainable from open databases. Our key concept is to extract semantic information from the given street-view images and to deploy it in proper intermediate steps of the suggested pipeline, which results in enhanced rendering accuracy and performance time. Furthermore, our method supports real-time semantic 3D inpainting to handle occluded and untextured areas, which appear often when the user's viewpoint dynamically changes. Experimental results validate the effectiveness of this method in comparison with the state-of-the-art approaches. We also present real-time demos in various urban streets.
More Related Videos
 08:25
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
 09:56
Automated 3D Optical Coherence Tomography to Elucidate Biofilm Morphogenesis Over Large Spatial Scales
Published on: August 21, 2019
