Geodesic Multi-Class SVM with Stiefel Manifold Embedding
Related Experiment Video
Updated: Nov 11, 2025

Visualization Method for Proprioceptive Drift on a 2D Plane Using Support Vector Machine
Published on: October 27, 2016

Abstract:
Manifold of geodesic plays an essential role in characterizing the intrinsic data geometry. However, the existing SVM methods have largely neglected the manifold structure. As such, functional degeneration may occur due to the potential polluted training. Even worse, the entire SVM model might collapse in the presence of excessive training contamination. To address these issues, this paper devises a manifold SVM method based on a novel ξ -measure geodesic, whose primary design objective is to extract and preserve the data manifold structure in the presence of training noises. To further cope with overly contaminated training data, we introduce Kullback-Leibler (KL) regularization with steerable sparsity constraint. In this way, each loss weight is adaptively obtained by obeying the prior distribution and sparse activation during model training for robust fitting. Moreover, the optimal scale for Stiefel manifold can be automatically learned to improve the model flexibility. Accordingly, extensive experiments verify and validate the superiority of the proposed method.


Related Concept Videos
 01:31
Classification of Systems-II
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:23
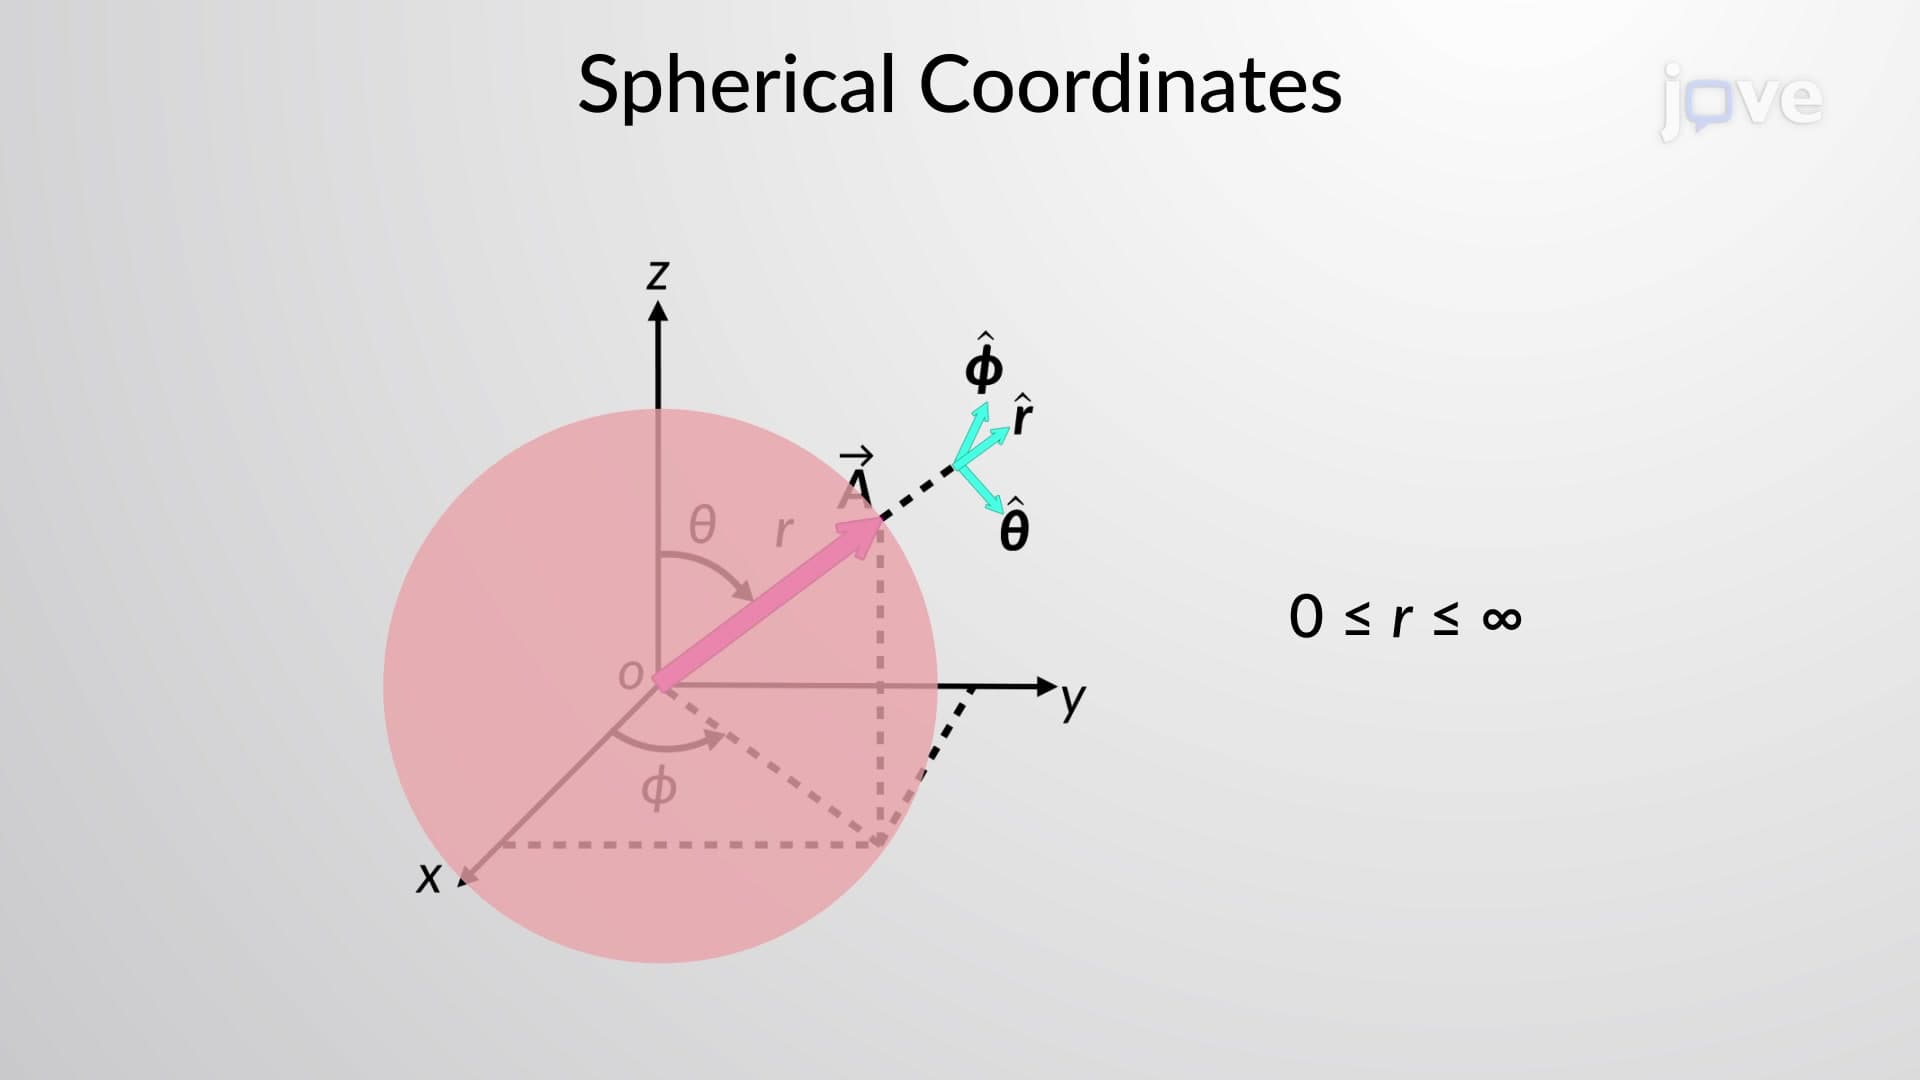
Spherical Coordinates
 01:26
Gauss's Law: Spherical Symmetry