Related Experiment Video
Updated: Nov 11, 2025
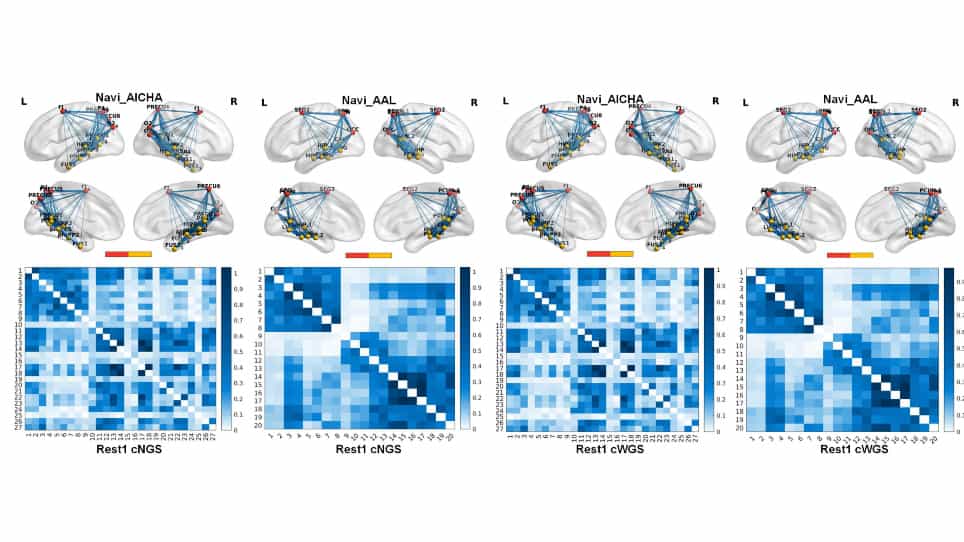

Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
A brain-inspired compact cognitive mapping system
Taiping Zeng1,2, Bailu Si3
1Institute of Science and Technology for Brain-Inspired Intelligence, Fudan University, Shanghai, China.

Abstract:
In many simultaneous localization and mapping (SLAM) systems, the map of the environment grows over time as the robot explores the environment. The ever-growing map prevents long-term mapping, especially in large-scale environments. In this paper, we develop a compact cognitive mapping approach inspired by neurobiological experiments. Mimicking the firing activities of neighborhood cells, neighborhood fields determined by movement information, i.e. translation and rotation, are modeled to describe one of the distinct segments of the explored environment. The vertices with low neighborhood field activities are avoided to be added into the cognitive map. The optimization of the cognitive map is formulated as a robust non-linear least squares problem constrained by the transitions between vertices, and is numerically solved efficiently. According to the cognitive decision-making of place familiarity, loop closure edges are clustered depending on time intervals, and then batch global optimization of the cognitive map is performed to satisfy the combined constraint of the whole cluster. After the loop closure process, scene integration is performed, in which revisited vertices are removed subsequently to further reduce the size of the cognitive map. The compact cognitive mapping approach is tested on a monocular visual SLAM system in a naturalistic maze for a biomimetic animated robot. Our results demonstrate that the proposed method largely restricts the growth of the size of the cognitive map over time, and meanwhile, the compact cognitive map correctly represents the overall layout of the environment. The compact cognitive mapping method is well suitable for the representation of large-scale environments to achieve long-term robot navigation.
More Related Videos
 11:15
Automated Visual Cognitive Tasks for Recording Neural Activity Using a Floor Projection Maze
Published on: February 20, 2014
 13:12
Translational Brain Mapping at the University of Rochester Medical Center: Preserving the Mind Through Personalized Brain Mapping
Published on: August 12, 2019
Related Concept Videos
 01:23
Storage
 01:20
Introduction to Cognitive Psychology
This field emerged in the mid-20th century, following a period dominated by behaviorism, which...
 01:15
Functional Brain Systems: Limbic System
 01:25
Neural Circuits
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:24
Somatosensory, Motor, and Association Cortex