Related Experiment Video
Updated: Nov 10, 2025


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Capillary Forces between Concave Gripper and Spherical Particle for Micro-Objects Gripping
Zenghua Fan1, Zixiao Liu1, Congcong Huang1
1School of Mechanical Engineering, Shandong University of Technology, Zibo 255049, China.

Abstract:
The capillary action between two solid surfaces has drawn significant attention in micro-objects manipulation. The axisymmetric capillary bridges and capillary forces between a spherical concave gripper and a spherical particle are investigated in the present study. A numerical procedure based on a shooting method, which consists of double iterative loops, was employed to obtain the capillary bridge profile and bring the capillary force subject to a constant volume condition. Capillary bridge rupture was characterized using the parameters of the neck radius, pressure difference, half-filling angle, and capillary force. The effects of various parameters, such as the contact angle of the spherical concave gripper, the radius ratio, and the liquid bridge volume on the dimensionless capillary force, are discussed. The results show that the radius ratio has a significant influence on the dimensionless capillary force for the dimensionless liquid bridge volumes of 0.01, 0.05, and 0.1 when the radius ratio value is smaller than 10. The effectiveness of the theorical approach was verified using simulation model and experiments.
Related Concept Videos
 01:32
Pinching-off of Coated Vesicles
 01:13
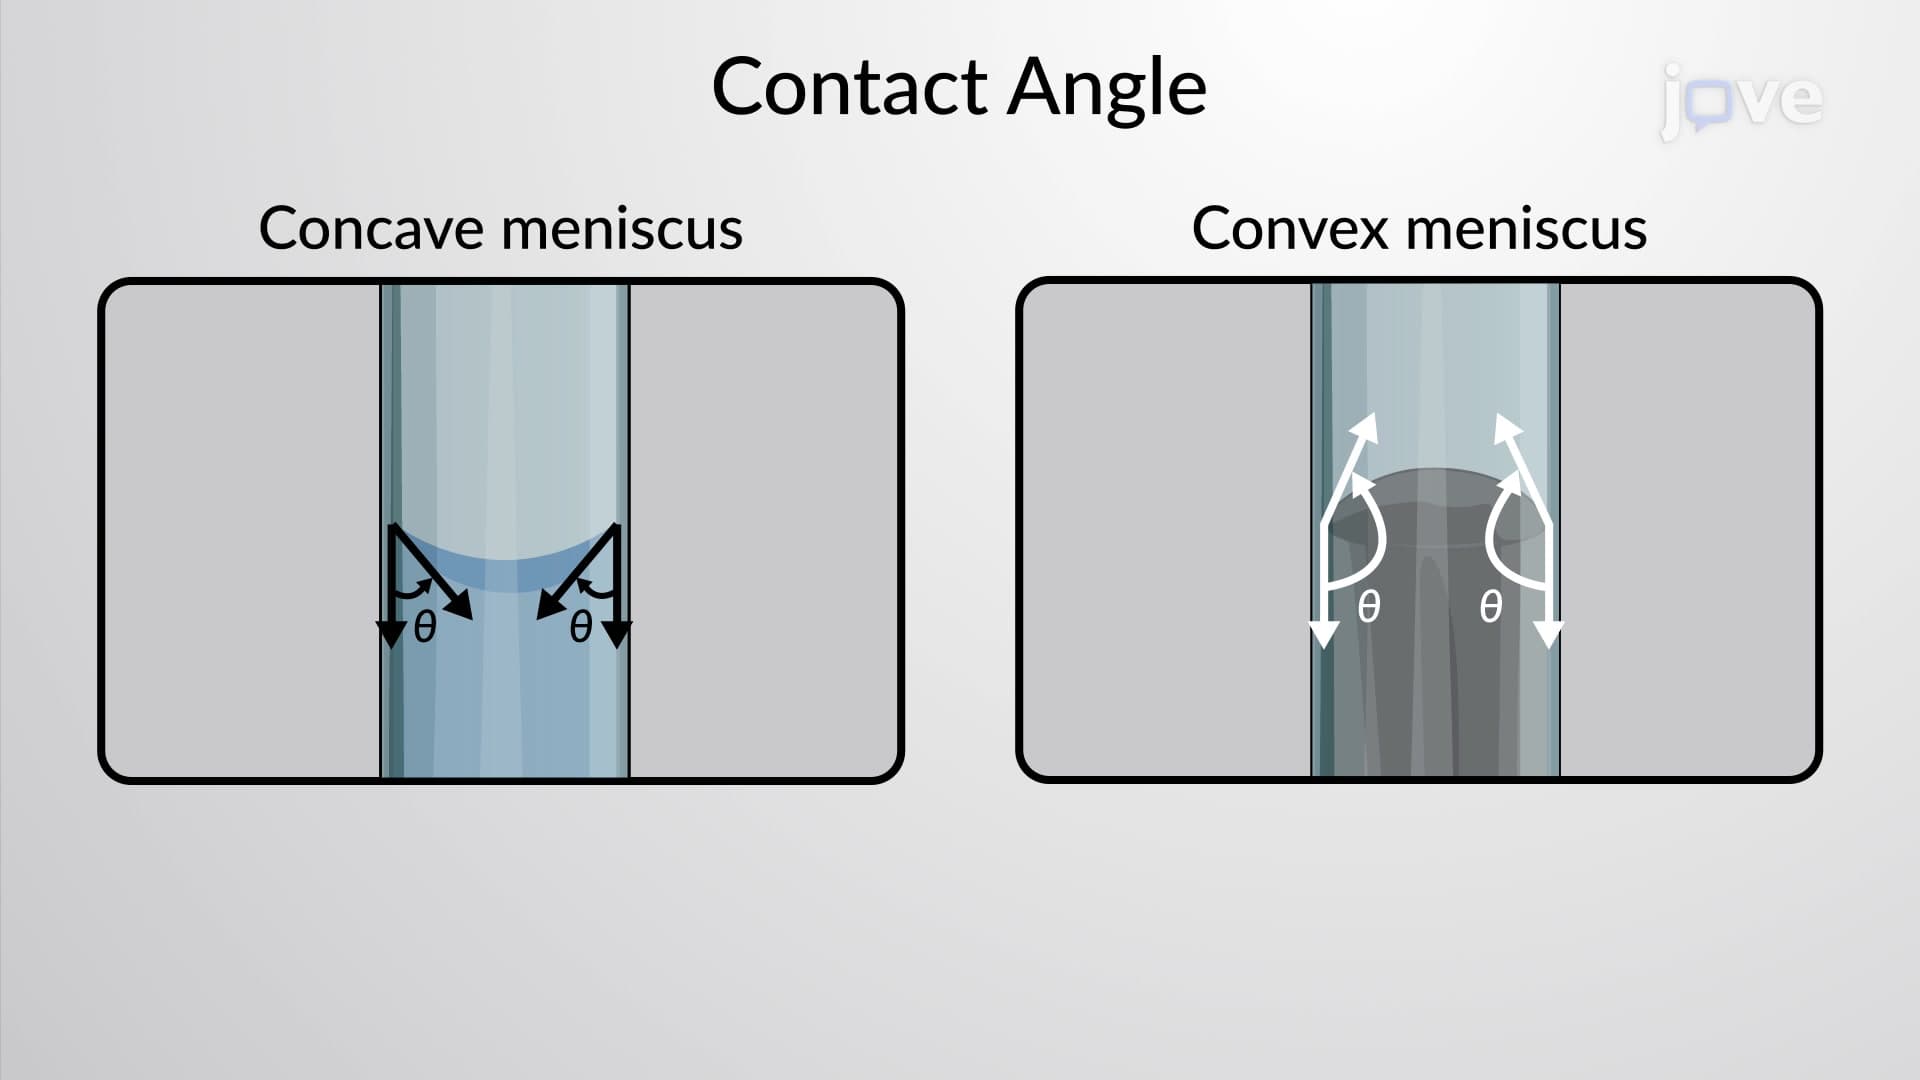
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...