Related Experiment Video
Updated: Nov 10, 2025
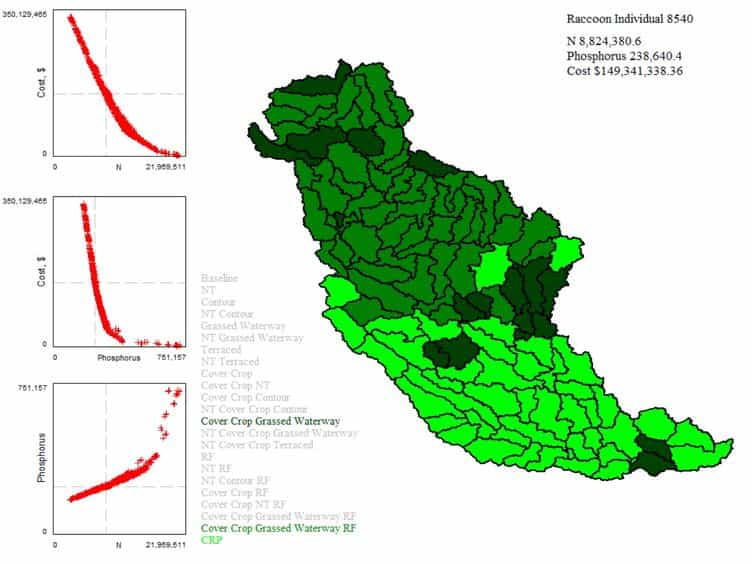

Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
An Improved Equilibrium Optimizer with Application in Unmanned Aerial Vehicle Path Planning
An-Di Tang1, Tong Han1, Huan Zhou1
1Aeronautics Engineering College, Air Force Engineering University, Xi'an 710038, China.

Abstract:
The unmanned aerial vehicle (UAV) path planning problem is a type of complex multi-constraint optimization problem that requires a reasonable mathematical model and an efficient path planning algorithm. In this paper, the fitness function including fuel consumption cost, altitude cost, and threat cost is established. There are also four set constraints including maximum flight distance, minimum flight altitude, maximum turn angle, and maximum climb angle. The constrained optimization problem is transformed into an unconstrained optimization problem by using the penalty function introduced. To solve the model, a multiple population hybrid equilibrium optimizer (MHEO) is proposed. Firstly, the population is divided into three subpopulations based on fitness and different strategies are executed separately. Secondly, a Gaussian distribution estimation strategy is introduced to enhance the performance of MHEO by using the dominant information of the populations to guide the population evolution. The equilibrium pool is adjusted to enhance population diversity. Furthermore, the Lévy flight strategy and the inferior solution shift strategy are used to help the algorithm get rid of stagnation. The CEC2017 test suite was used to evaluate the performance of MHEO, and the results show that MHEO has a faster convergence speed and better convergence accuracy compared to the comparison algorithms. The path planning simulation experiments show that MHEO can steadily and efficiently plan flight paths that satisfy the constraints, proving the superiority of the MHEO algorithm while verifying the feasibility of the path planning model.
More Related Videos

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:13
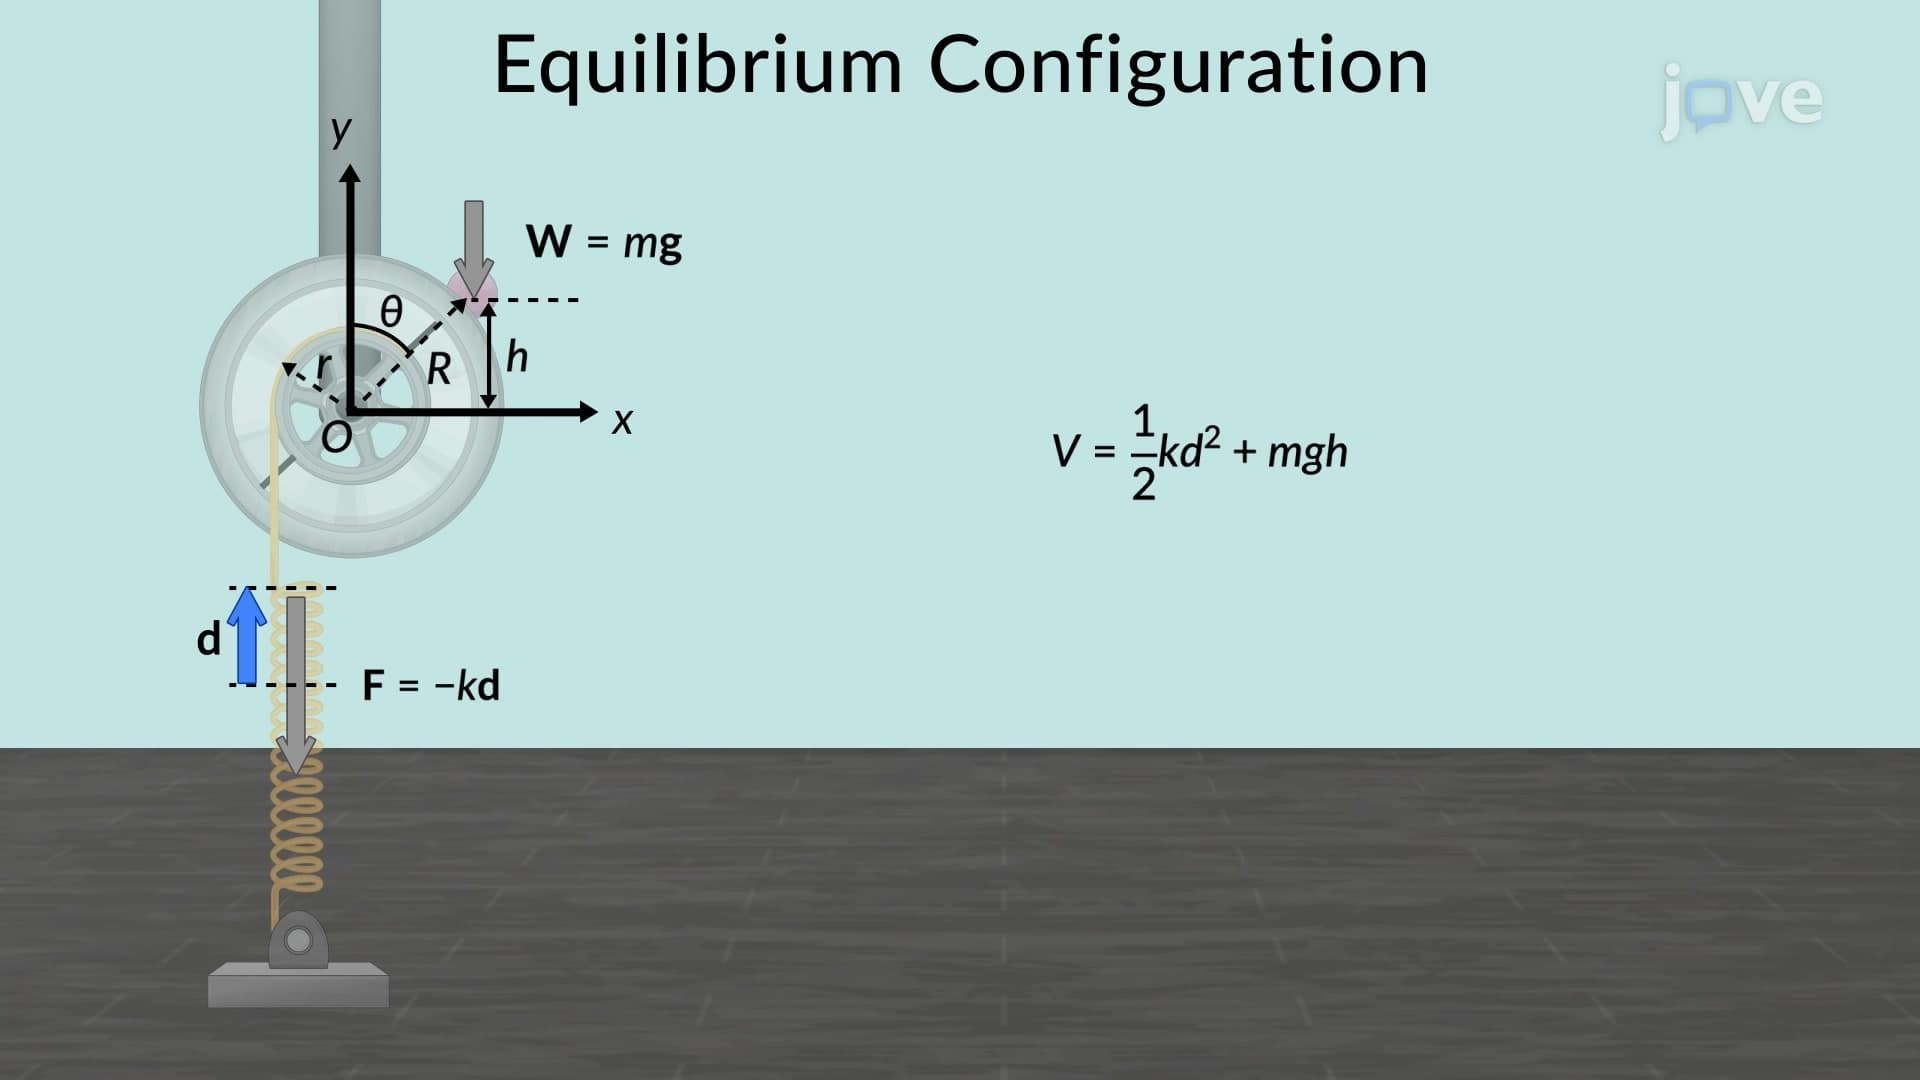
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...