Is the anterolateral ligament the smoking gun to explain rotational knee laxity or just vaporware?
João Espregueira-Mendes1,2,3,4,5
1Clínica do Dragão, Espregueira-Mendes Sports Centre - FIFA Medical Centre of Excellence, Porto, Portugal espregueira@dhresearchcentre.com.

Abstract
No abstract available in PubMed .
More Related Videos
 05:07
Author Spotlight: Implementing the Enhanced Recovery After Surgery Concept in Rehabilitation Following Anterior Cruciate Ligament Reconstruction
Published on: March 1, 2024
2.3K
 08:30
Surgical Retrieval, Isolation and In vitro Expansion of Human Anterior Cruciate Ligament-derived Cells for Tissue Engineering Applications
Published on: April 30, 2014
11.6K
Related Concept Videos
 01:23
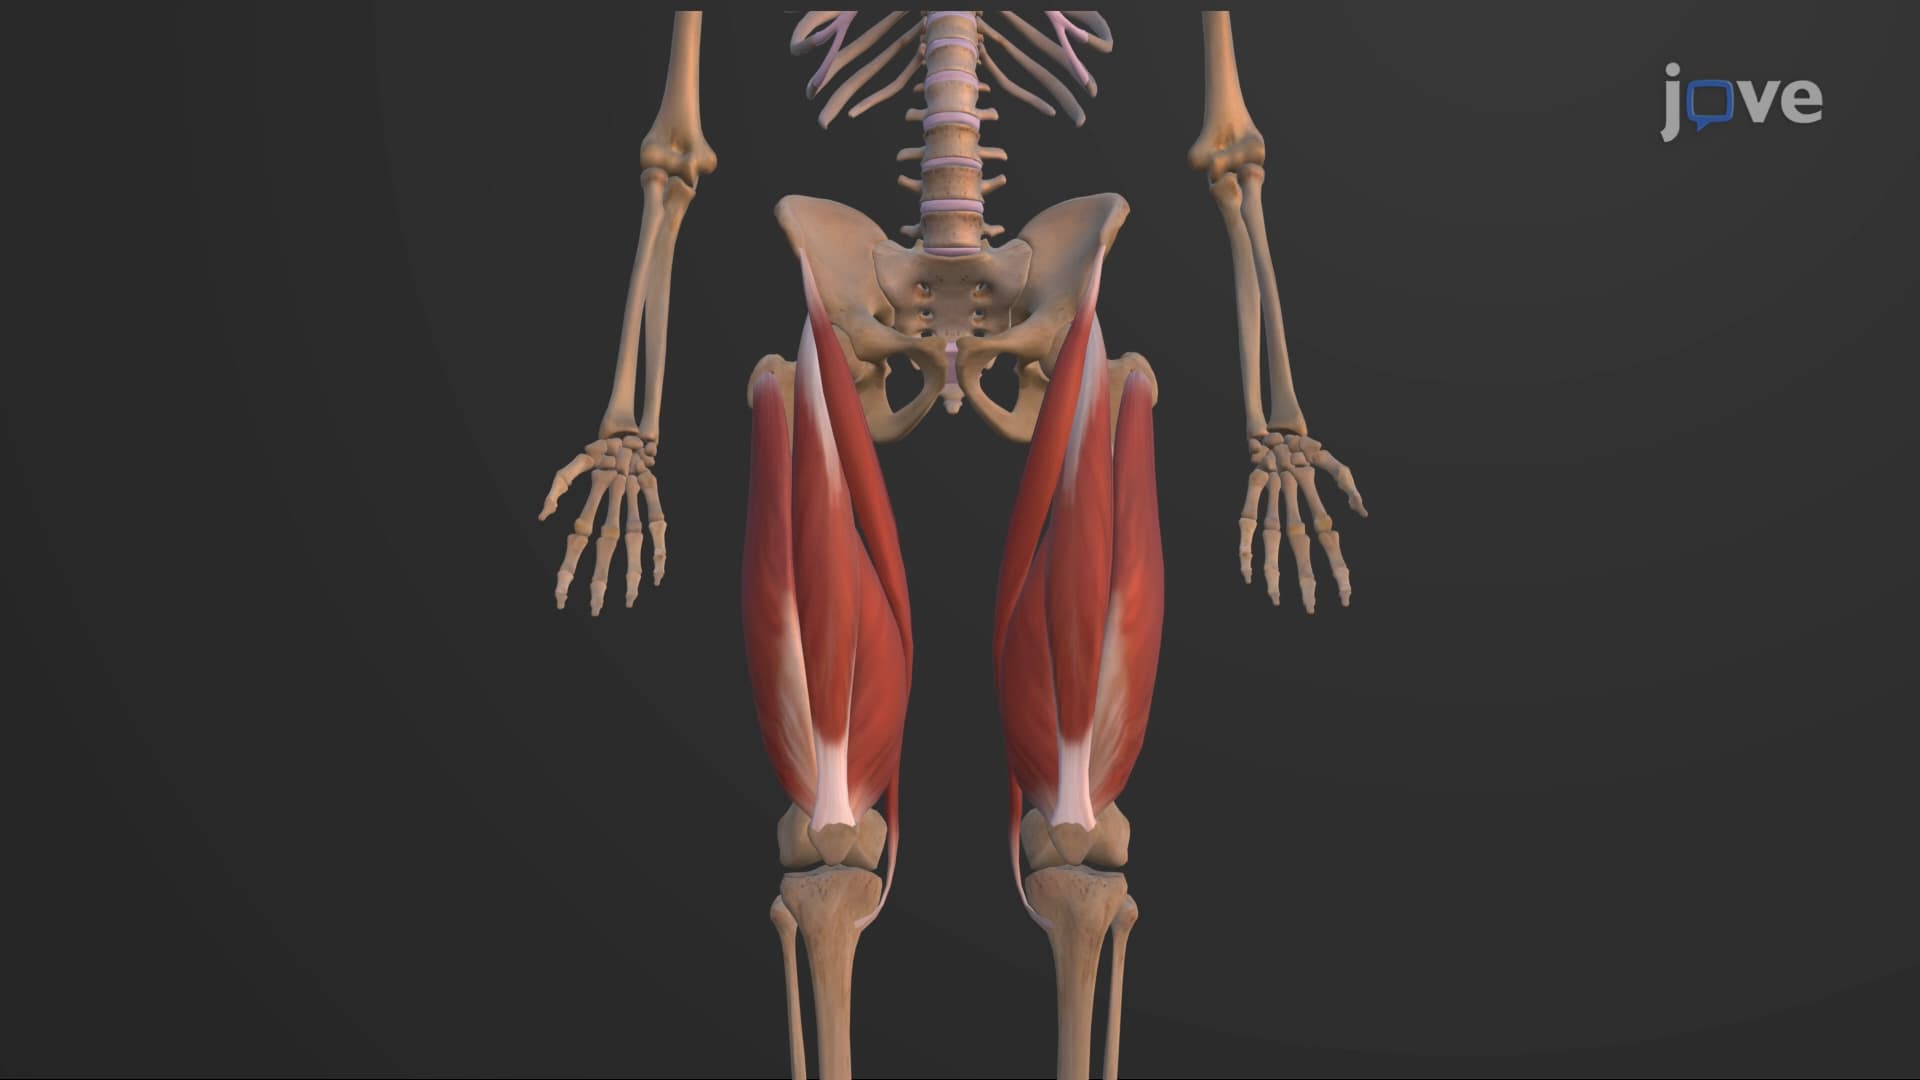
Muscles that Move the Leg
4.1K
The movement of the legs is facilitated by numerous muscles located within the anterior, medial, and posterior compartments of the thigh.
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
4.1K
 01:10
Ankle Joint
2.2K
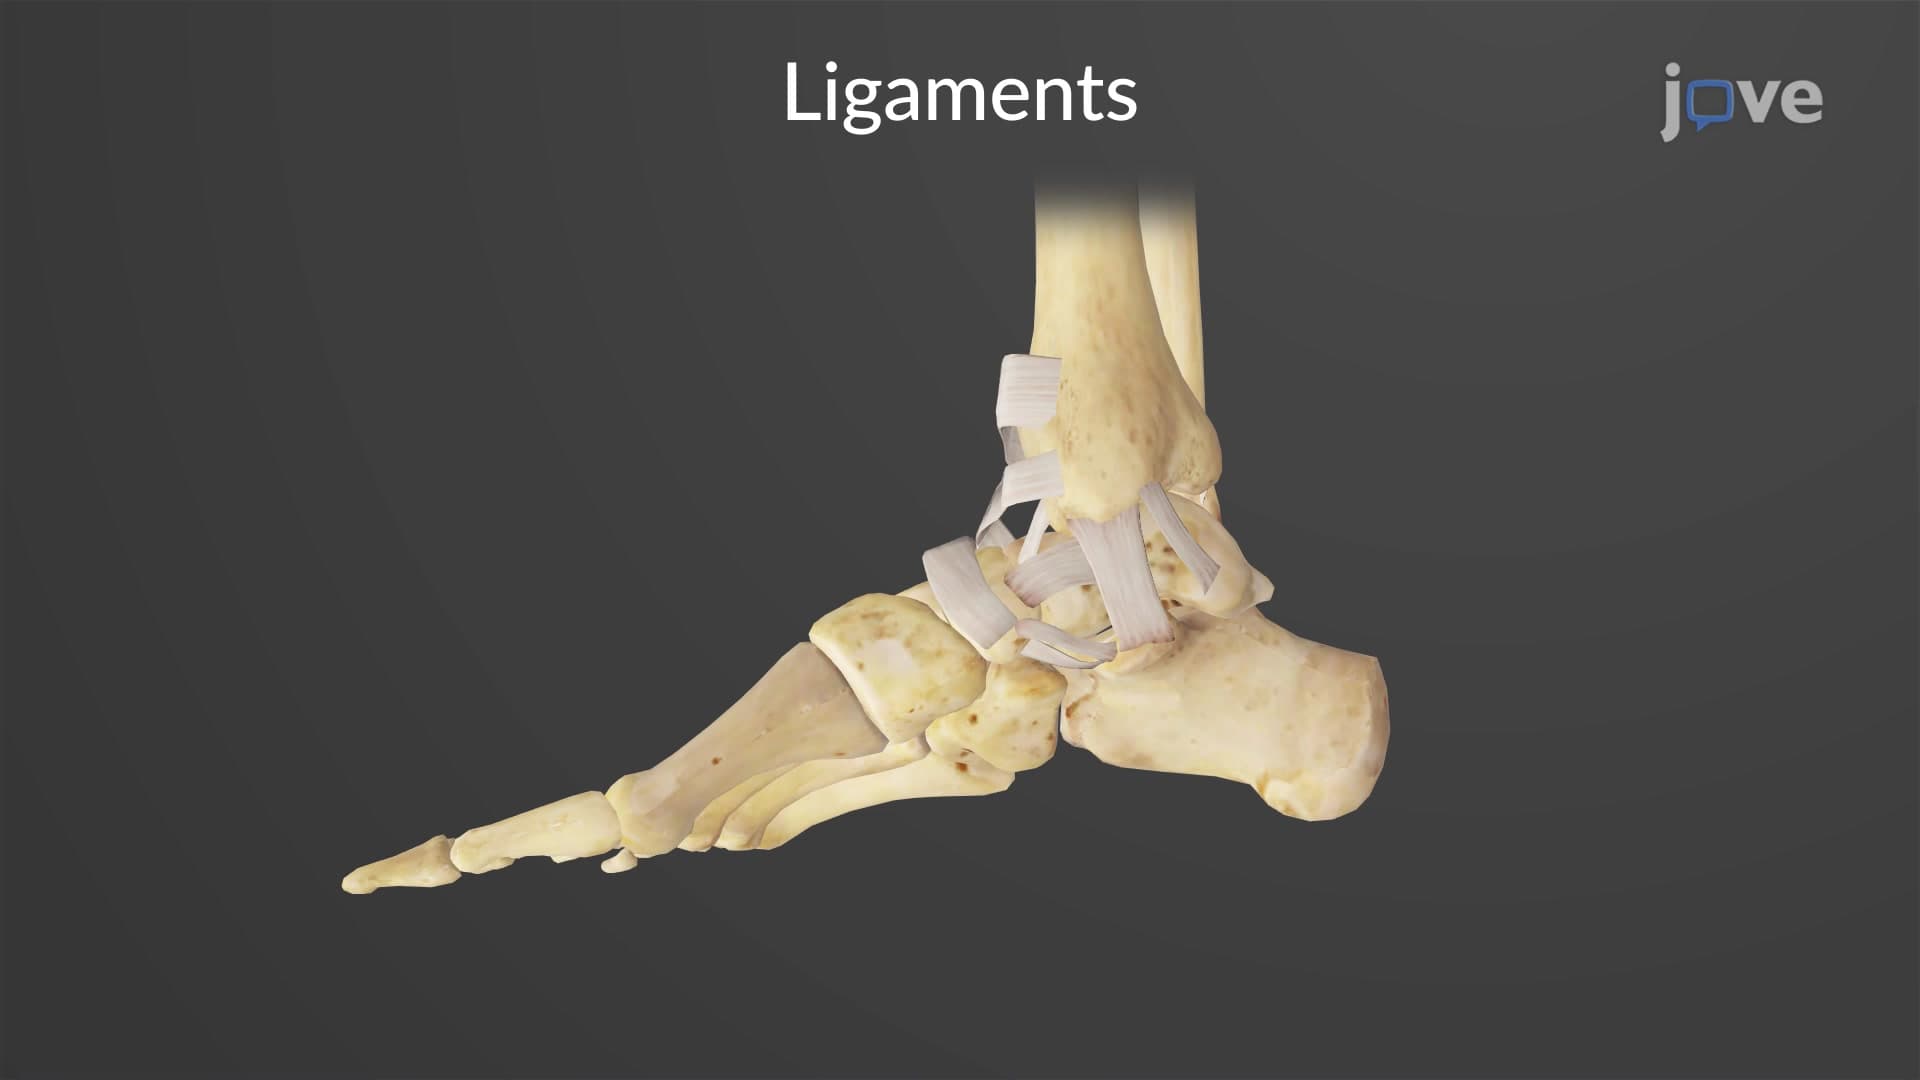
The ankle is formed by the talocrural joint (crural = leg). It consists of the articulations between the talus bone of the foot and the distal ends of the tibia and fibula of the leg. The superior aspect of the talus bone is square-shaped and has three areas of articulation. The top of the talus articulates with the inferior tibia. This is the portion of the ankle joint that carries the body weight between the leg and foot. The sides of the talus are firmly held in position by the articulations...
2.2K
 01:23
Knee Joint
2.7K
The knee joint is the most complicated joint in the body. It consists of three articulations– two tibiofemoral and one patellofemoral. As is characteristic of synovial joints, the knee joint has a thin articular capsule that partially surrounds this joint cavity. Additionally, several ligaments, muscles, and cartilaginous structures support the movement of the knee.
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
2.7K
 01:16
Bones of the Lower Limb: Femur and Patella
4.3K
The femur is the body's longest and strongest bone spanning the thigh region. Its head articulates with the acetabulum of the hip bone to form the hip joint. A minor indentation on the medial side of the femoral head, called the fovea capitis, serves as the site of attachment for the ligament of the head of the femur. This weak ligament spans the femur and acetabulum and supports the hip joint. The narrowed region below the head is the neck of the femur. The inclination angle between the...
4.3K
 01:10
Angular Momentum: Single Particle
6.9K
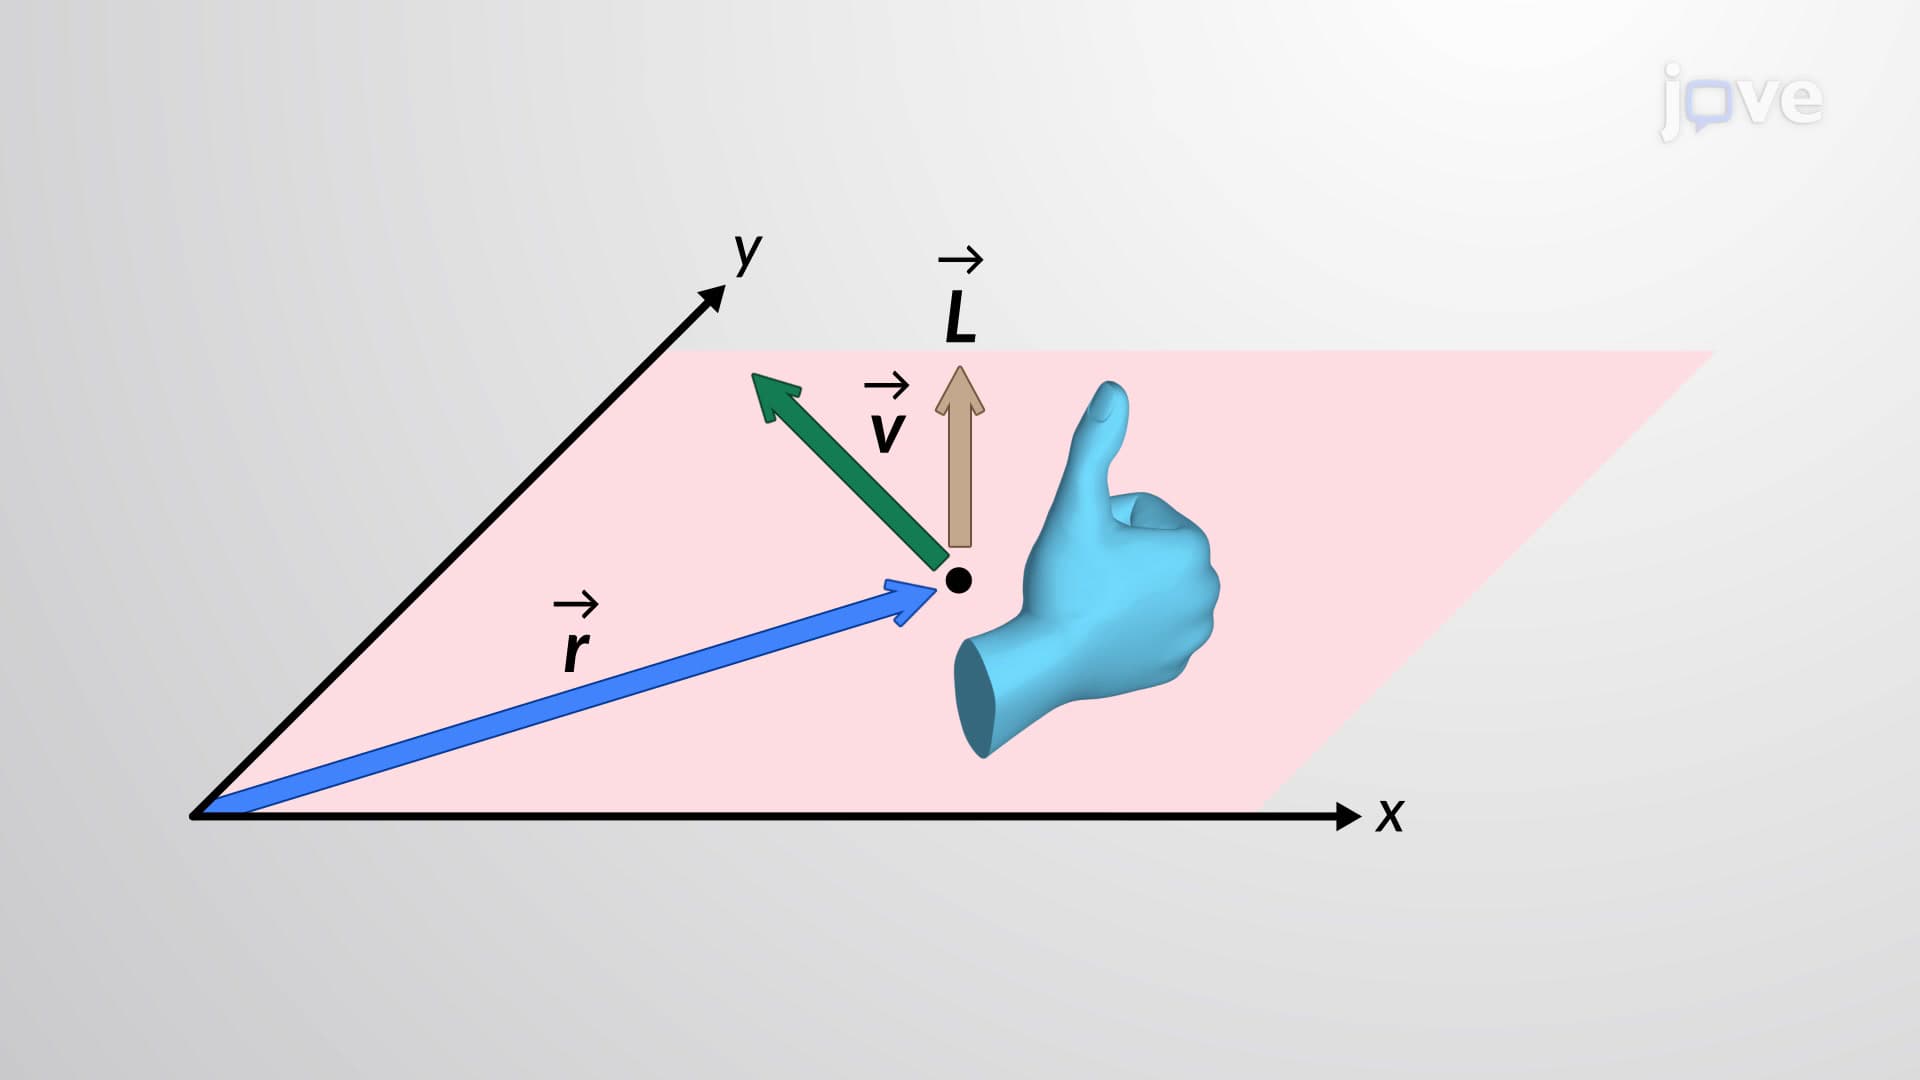
Angular momentum is directed perpendicular to the plane of the rotation, and its magnitude depends on the choice of the origin. The perpendicular vector joining the linear momentum vector of an object to the origin is called the “lever arm.” If the lever arm and linear momentum are collinear, then the magnitude of the angular momentum is zero. Therefore, in this case, the object rotates about the origin such that it lies on the rim of the circumference defined by the lever arm...
6.9K
 01:09
Angular Momentum and Principle Axes of Inertia
335
The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
335