Solving infinite-horizon optimalcontrol problems of the time-delayedsystems by a feed forward neural network model
Related Experiment Video
Updated: Nov 8, 2025

Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Alireza Nazemi1, Ensieh Fayyazi1
1Department of Mathematics,School of Mathematical Sciences, Shahrood University of Technology,Shahrood, Iran.

Abstract:
A numerical method using neural network for solving infinite-horizon time-delayed optimal control problems is studied. The problem is first transformed, using a Páde approximation, to one without a time-delayed argument. By a suitable change of variable, the obtained non-delay infinite-horizon optimal control problem is converted to a finite-horizon nonlinear optimal control problem. We try to approximate the solution of Hamiltonian conditions based on the Pontryagin minimum principle (PMP). For this purpose, we introduce an error function that contains all PMP conditions. We then minimize the error function where weights and biases associated with all neurons are unknown. Substituting the optimal values of the weights and biases in the trial solutions, we obtain the optimal solution of the original problem. Several examples are given to show the efficiency of the method.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
First Order Systems
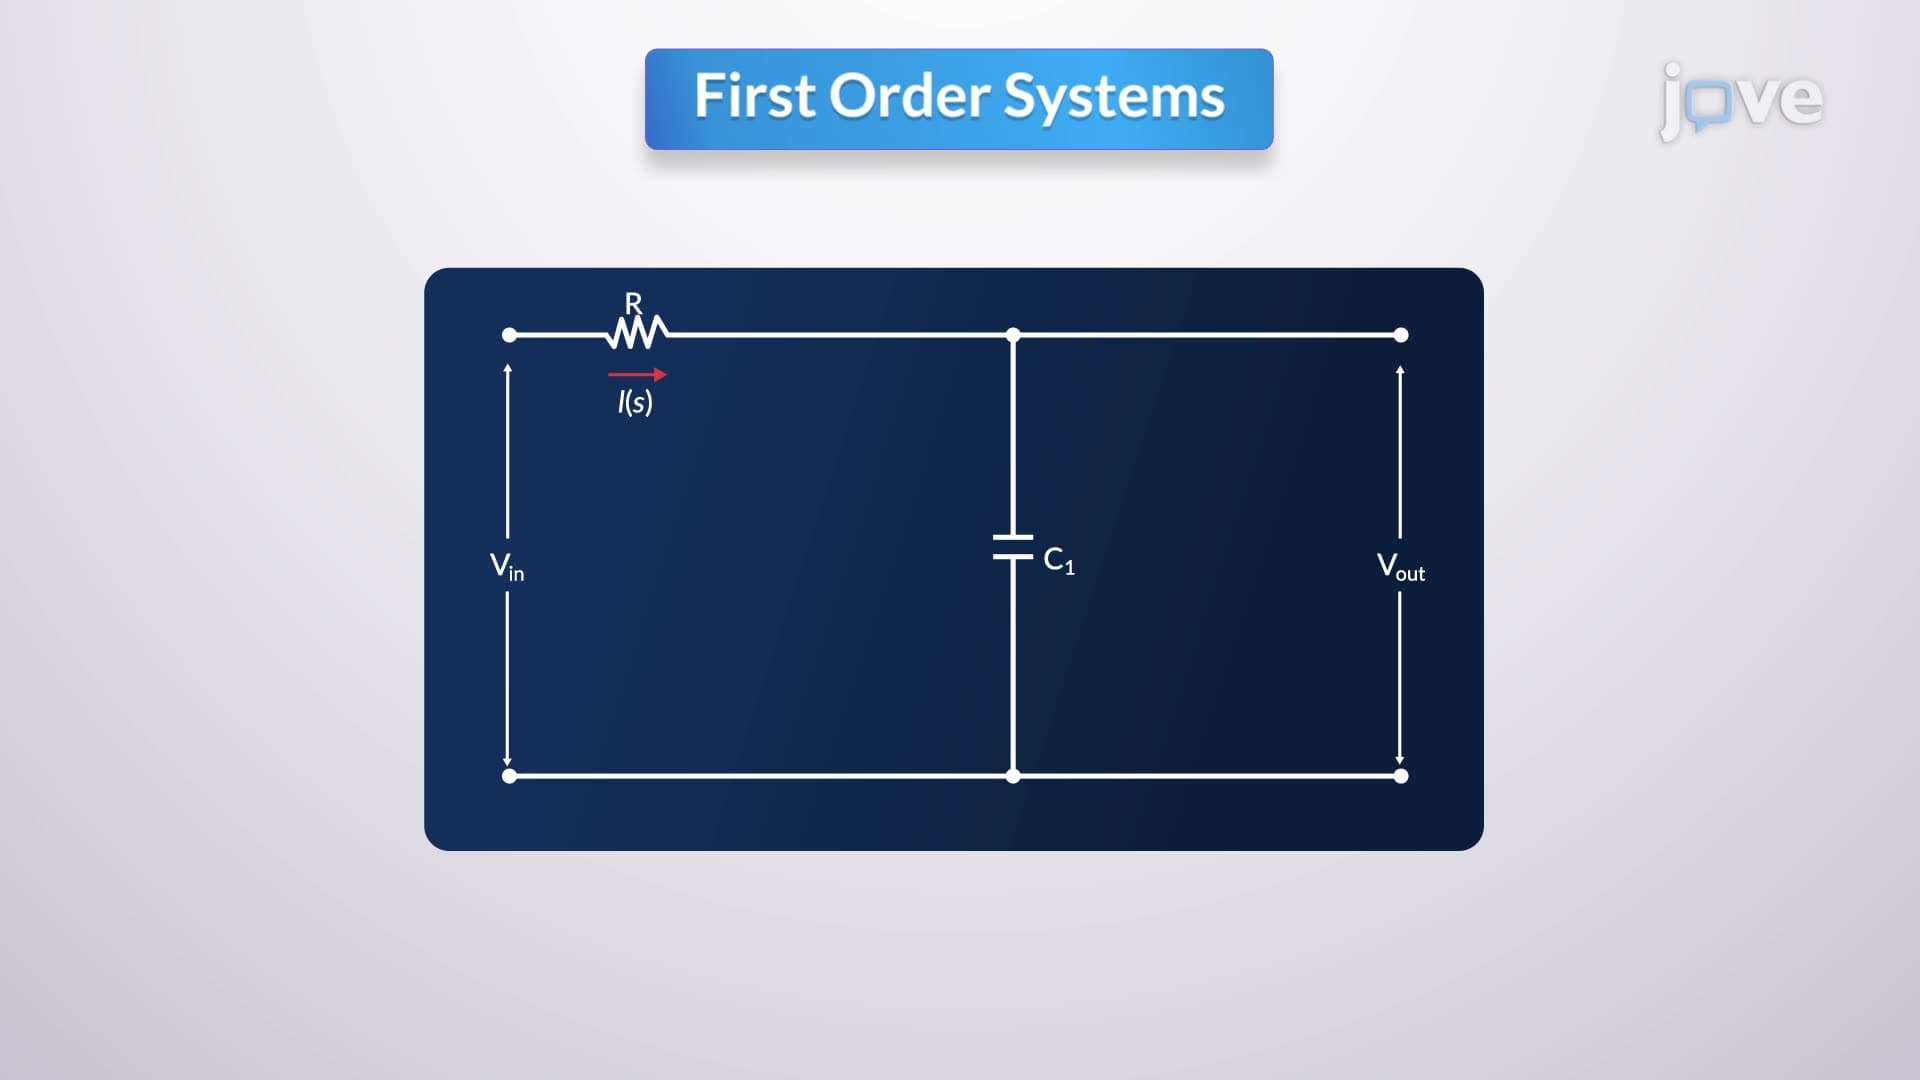
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:27
State Space Representation
Consider an RLC circuit, a...