Related Experiment Video
Updated: Nov 7, 2025

Surrogate Model Development for Digital Experiments in Welding
Published on: March 28, 2025
Proportional Integral Derivative Control in Spark Plasma Sintering Simulations
Runjian Jiang1, Elisa Torresani1, Guodong Cui2
1Powder Technology Laboratory, San Diego State University, San Diego, CA 92182, USA.

Abstract:
The prediction of microstructure evolution and densification behavior during the spark plasma sintering (SPS) process largely depends on accurate temperature regulation. A loop feedback control algorithm called proportional integral derivative (PID) control is a practical simulation tool, but its coefficients are often determined by an inefficient "trial and error" method. This paper is devoted to proposing a numerical method based on the principles of variable coefficients to construct an optimal linear PID controller in SPS electro-thermal simulations. Different types of temperature profiles were applied to evaluate the feasibility of the proposed method. Simulation results showed that, for temperature profiles conventionally used in SPS cycles, the PID output keeps pace with the desired profile. Characterized by an imperfect time delay and overshoot/undershoot, the constructed PID controller needs further advancement to provide a more satisfactory temperature regulation for non-continuous temperature profiles. The first step towards a numerical rule for the optimal PID controller design was undertaken in this work. It is expected to provide a valuable reference for the advanced electro-thermal modeling of SPS.

Related Concept Videos
 01:24
PI Controller: Design
 01:19
PID Controller
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
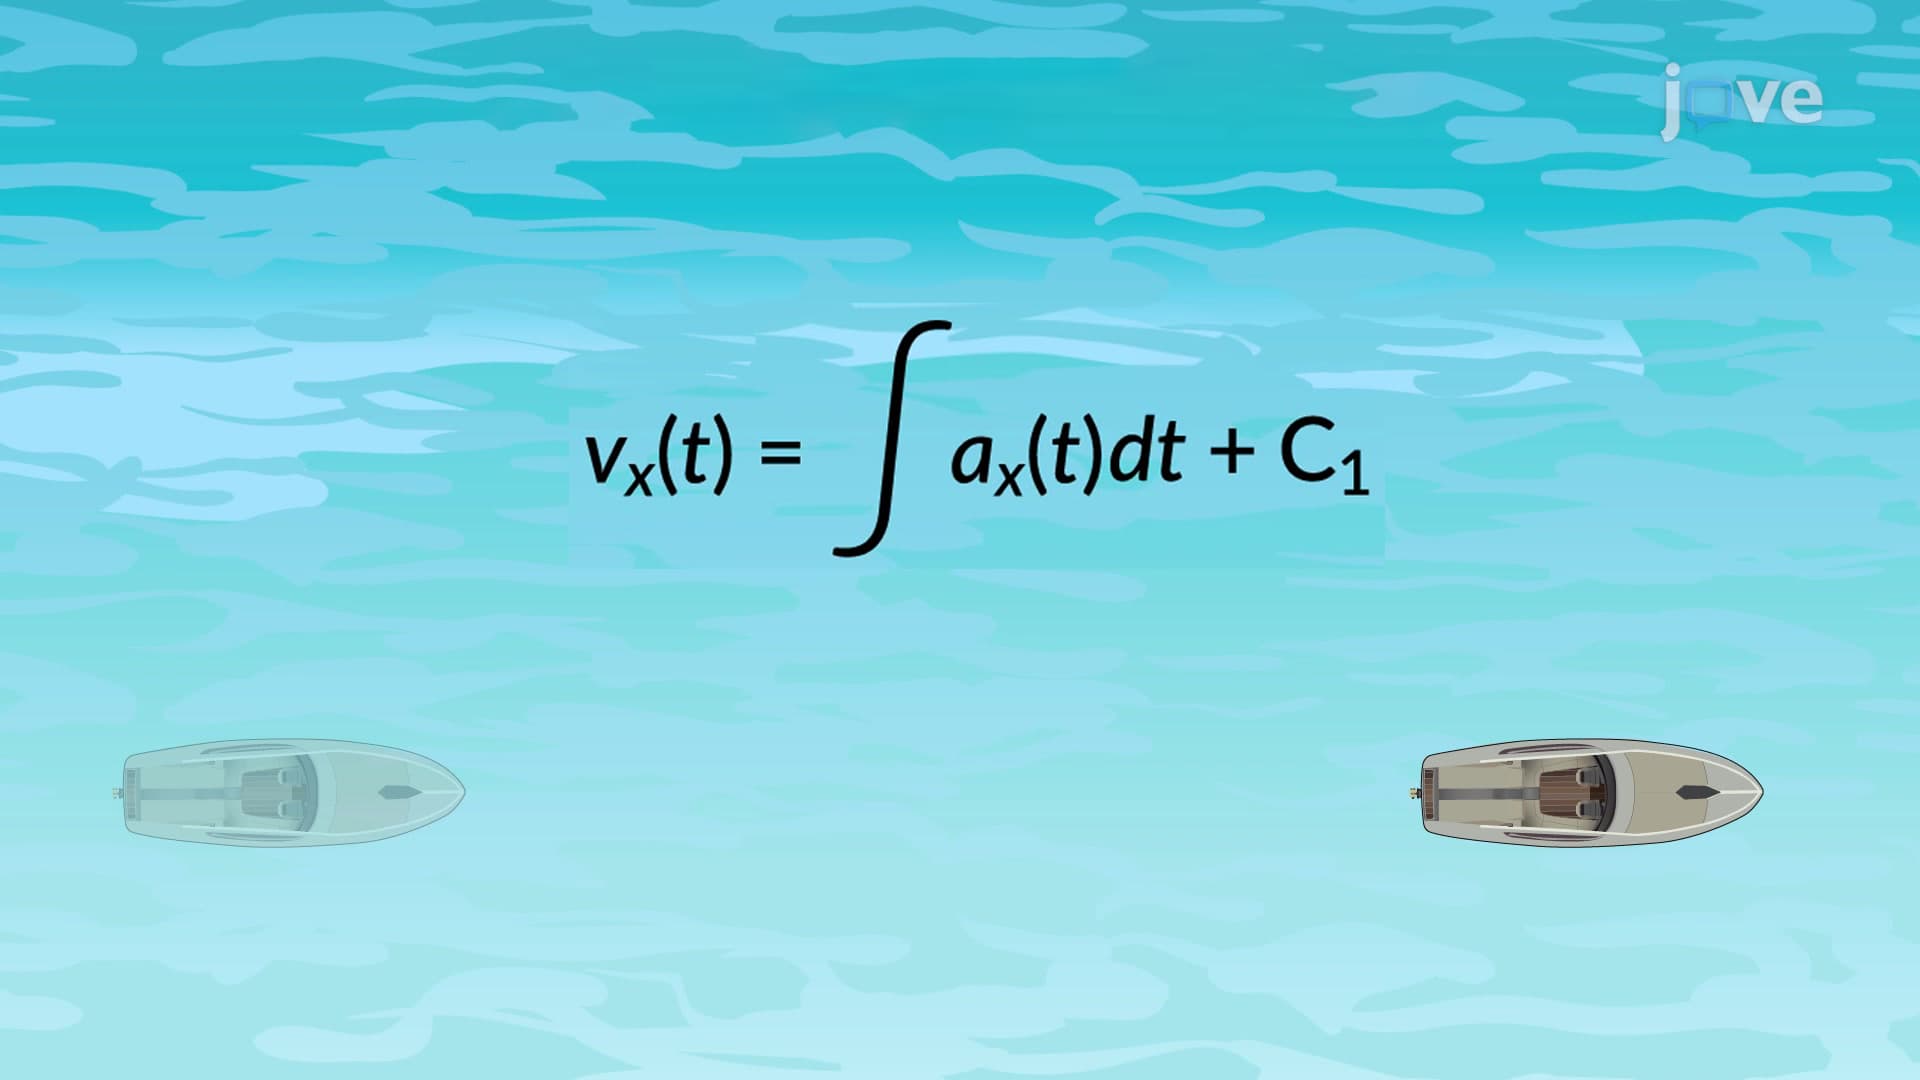 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:13
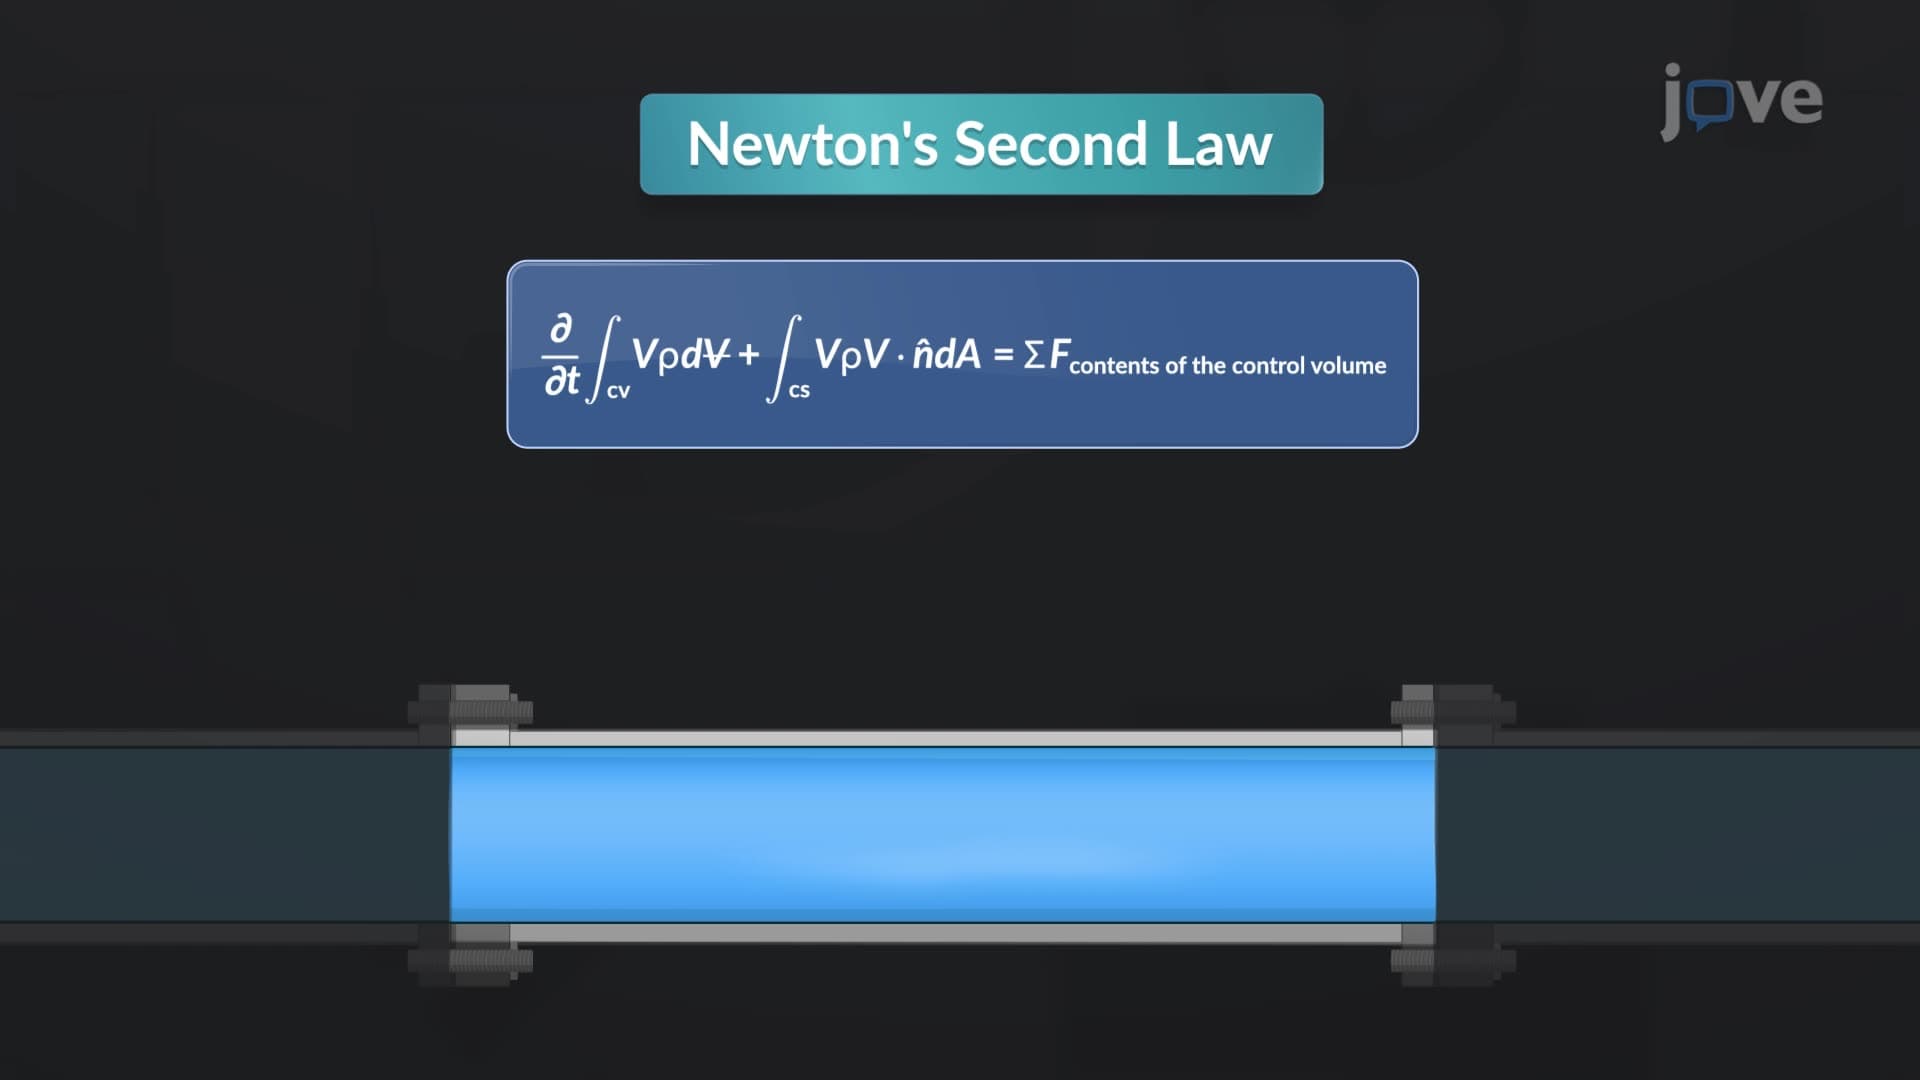
Linear Momentum in Control Volume