Related Experiment Video
Updated: Nov 7, 2025

Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
Automated fiducial marker detection and localization in volumetric computed tomography images: a three-step hybrid
Milovan Regodić1,2, Zoltan Bardosi1, Wolfgang Freysinger1
1Medical University of Innsbruck, Department of Otorhinolaryngology, Innsbruck, Austria.

Abstract:
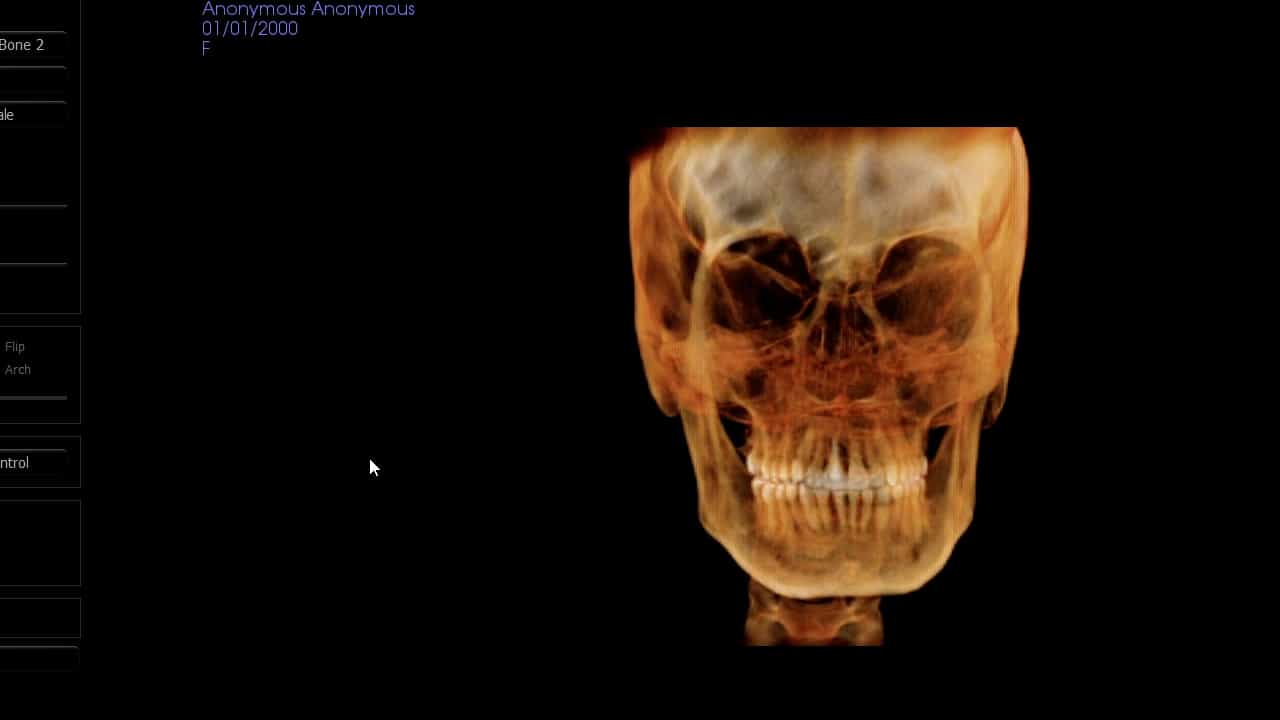
Purpose: Automating fiducial detection and localization in the patient's pre-operative images can lead to better registration accuracy, reduced human errors, and shorter intervention time. Most current approaches are optimized for a single marker type, mainly spherical adhesive markers. A fully automated algorithm is proposed and evaluated for screw and spherical titanium fiducials, typically used in high-accurate frameless surgical navigation. Approach: The algorithm builds on previous approaches with morphological functions and pose estimation algorithms. A 3D convolutional neural network (CNN) is proposed for the fiducial classification task and evaluated for both traditional closed-set and emerging open-set classifiers. A proposed digital ground-truth experiment, with cone-beam computed tomography (CBCT) imaging software, is performed to determine the localization accuracy of the algorithm. The localized fiducial positions in the CBCT images by the presented algorithm were compared to the actual known positions in the virtual phantom models. The difference represents the fiducial localization error (FLE). Results: A total of 241 screws, 151 spherical fiducials, and 1550 other structures are identified with the best true positive rate 95.9% for screw and 99.3% for spherical fiducials at 8.7% and 3.4% false positive rate, respectively. The best achieved FLE mean and its standard deviation for a screw and spherical marker are 58 (14) and , respectively. Conclusions: Accurate marker detection and localization were achieved, with spherical fiducials being superior to screws. Large marker volume and smaller voxel size yield significantly smaller FLEs. Attenuating noise by mesh smoothing has a minor effect on FLE. Future work will focus on expanding the CNN for image segmentation.