Related Experiment Video
Updated: Nov 5, 2025

Characterization of SiN Integrated Optical Phased Arrays on a Wafer-Scale Test Station
Published on: April 1, 2020
Experimental demonstration of pseudo-pilots-aided Gaussian basis expansion-based phase noise suppression scheme for

Abstract:
In this paper, we propose a novel phase noise suppression scheme called pseudo-pilots-aided Gaussian basis expansion (PS-GBE) for coherent optical orthogonal frequency division multiplexing (CO-OFDM) system. Integrating with the pseudo-pilots, the Gaussian basis can suppress and fit phase noise effectively with high spectral efficiency (SE). We experimentally demonstrate the proposed scheme in 200-Gb/s optical QPSK-OFDM superchannel and 400-Gb/s optical 16QAM-OFDM superchannel. According to the experimental results, the proposed PS-GBE has a phase noise suppression performance similar to the GBE scheme. However, different from the GBE scheme, fewer pilots are needed for phase noise estimation in PS-GBE. Hence, the proposed PS-GBE can achieve higher SE. Compared to the pseudo-pilots-aided orthogonal basis expansion-based (PS-OBE) phase noise suppression and traditional common phase noise compensation (CPEC) methods, the proposed PS-GBE can get a significant performance enhancement. In the QPSK-OFDM system, a Q-factor improvement of 1.1 dB is obtained compared to the PS-OBE method. In the 16QAM-OFDM system, the BER is enhanced from 1.00E-03 to 2.05E-04. Further simulation results indicate that our proposed PS-GBE scheme can effectively increase laser linewidth tolerance. The proposed scheme can be applied to CO-OFDM and extended to coherent optical filterbank multicarrier (CO-FBMC) and coherent optical single carrier frequency domain multiplexing (CO-SCFDM) transmission system.
More Related Videos
 09:23
Quantum State Engineering of Light with Continuous-wave Optical Parametric Oscillators
Published on: May 30, 2014
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:20
Power Factor Correction
 01:16
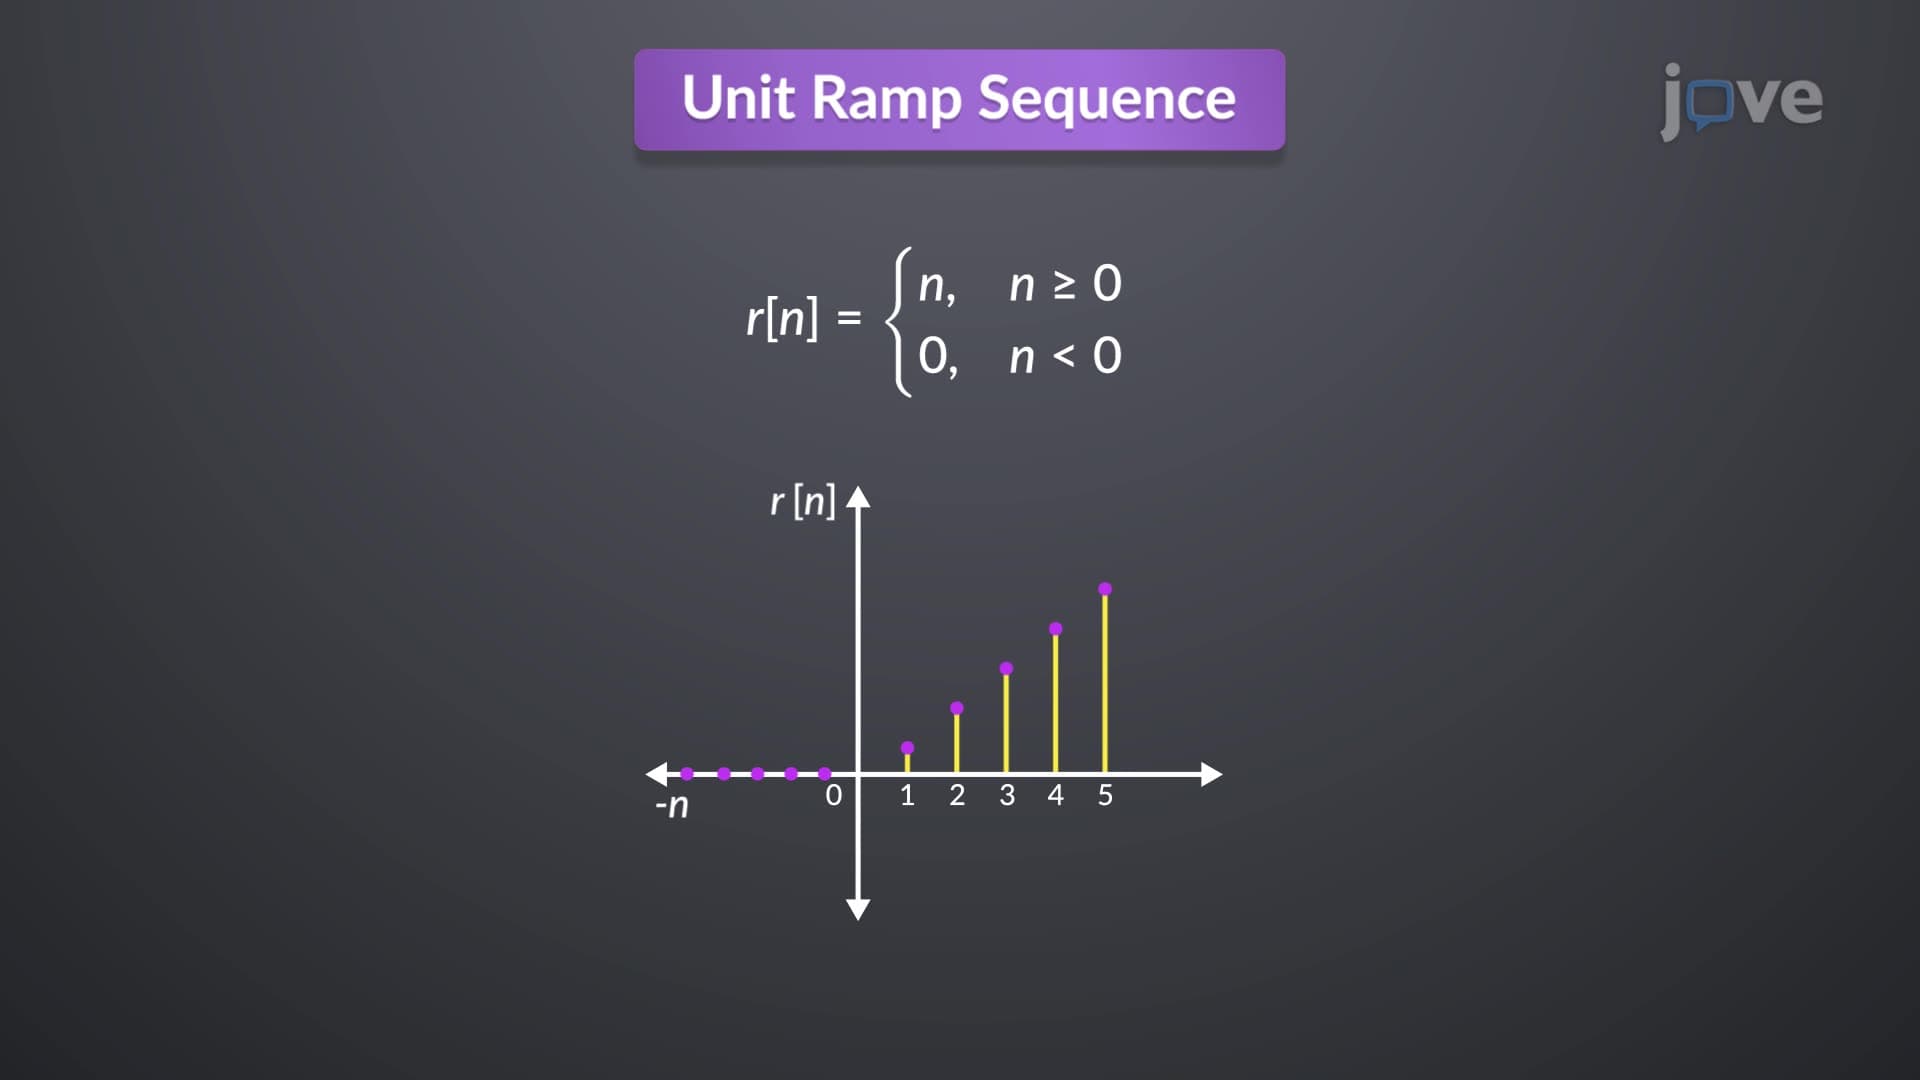
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...