Related Experiment Video
Updated: Nov 5, 2025
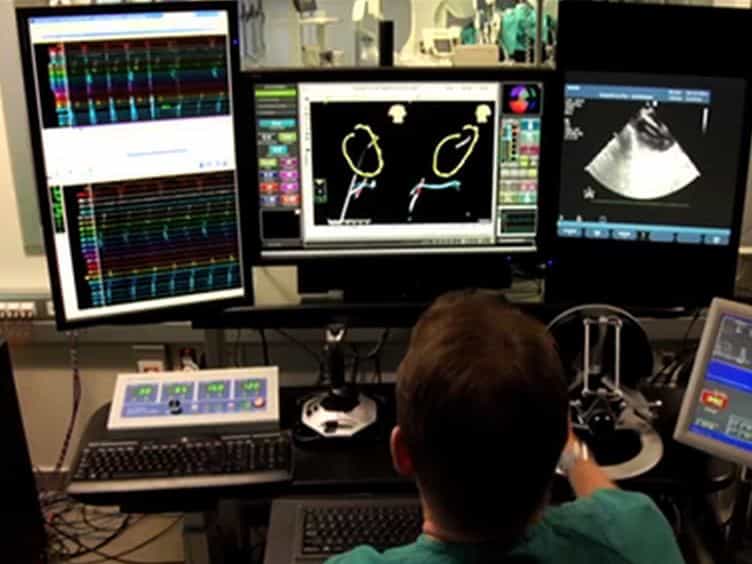

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Contact Stability and Contact Safety of a Magnetic Resonance Imaging-Guided Robotic Catheter Under Heart Surface
Ran Hao1, E Erdem Tuna1, M Cenk Çavuşoğlu1
1Department of Electrical, Computer, and Systems Engineering, Case Western Reserve University, Cleveland, OH 44106.

Abstract:
Contact force quality is one of the most critical factors for safe and effective lesion formation during catheter based atrial fibrillation ablation procedures. In this paper, the contact stability and contact safety of a novel magnetic resonance imaging (MRI)-actuated robotic cardiac ablation catheter subject to surface motion disturbances are studied. First, a quasi-static contact force optimization algorithm, which calculates the actuation needed to achieve a desired contact force at an instantaneous tissue surface configuration is introduced. This algorithm is then generalized using a least-squares formulation to optimize the contact stability and safety over a prediction horizon for a given estimated heart motion trajectory. Four contact force control schemes are proposed based on these algorithms. The first proposed force control scheme employs instantaneous heart position feedback. The second control scheme applies a constant actuation level using a quasi-periodic heart motion prediction. The third and the last contact force control schemes employ a generalized adaptive filter-based heart motion prediction, where the former uses the predicted instantaneous position feedback, and the latter is a receding horizon controller. The performance of the proposed control schemes is compared and evaluated in a simulation environment.
Related Concept Videos
 01:21
Imaging Studies for Cardiovascular System IV: CMRI
 01:24
Magnetic Resonance Imaging