Related Experiment Video
Updated: Nov 4, 2025
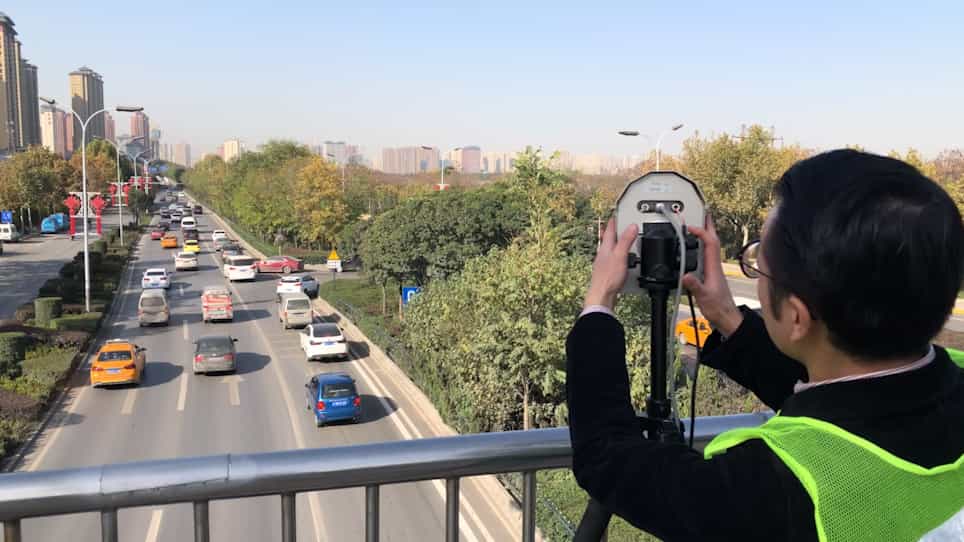
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
A unifying view on traffic conflicts and their connection with crashes
1Purdue University, Lyles School of Civil Engineering, United States.

Abstract:
After decades of research on traffic conflicts and other crash surrogate events, defining these events and conclusively connecting them with crashes continue to be the most important tasks. This paper aims to help establish a consensus on these two fundamental matters by discussing the underlying concepts by which they can be connected in a consistent construct justified with theory and empirical evidence. The importance of insight into a safety-relevant event beyond what is externally observable is emphasized by considering two distributions of crash nearness: (1) values observed by external observers and (2) driver-preferred values that are usually unobservable. Traffic encounters and traffic conflicts are discussed here in the context of crash possibility illustrated with these two distributions. The difference between the preferred and observed crash nearness values is introduced as the delay of response to an error that violates the crash nearness preference. Traffic conflicts caused by driver errors that violate the driver populace's minimum crash nearness are recommended for safety analysis if only external observations are available. The conditions of properly detecting such traffic conflicts and estimating the probability of crash are identified and their validity is emphasized based on the past SHRP2 study. The mentioned study identified two additional conditions for proper identification of traffic conflicts: (1) speeds sufficiently high to induce driver responses consistent with the theory and with Lomax distribution and (2) elimination of self-clearing encounters such as a preceding vehicle exiting a lane in rear-end interactions. The most encouraging finding of this study is the mentioned sufficiently high speeds that tend to coincide with collision outcomes sufficiently serious to be reportable to the authorities. Another encouraging element is the insight about preferred crash nearness values that may be brought by autonomous vehicles. The biggest challenge in applying EV modeling today is using proper safety-relevant events to ensure that the tail of a distribution estimated based on observed events is consistent with the distribution tail that represents a crash. Autonomous vehicles may help eliminate this challenge since their preferred crash nearness values should be known.

Related Concept Videos
 01:05
Collisions in Multiple Dimensions: Introduction
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:41
Social Traps
 01:15
Elastic Collisions: Case Study
 01:00
Elastic Collisions: Introduction
 01:19
Types of Collisions - II