Related Experiment Video
Updated: Nov 4, 2025


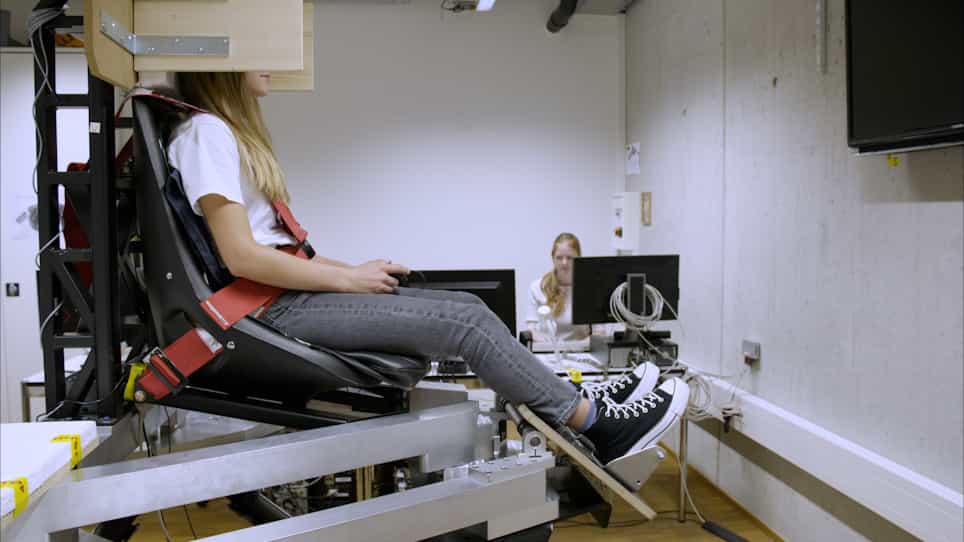
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
The interaction of global motion and global form processing on the perception of implied motion: An equivalent noise
Mahesh R Joshi1, Anita J Simmers2, Seong T Jeon2
1Eye and Vision Research Group, School of Health Professions, University of Plymouth, Plymouth, United Kingdom.

Abstract:
Global motion and global form are proposed to be processed through functionally differentiated independent channels along dorsal (motion) and ventral (form) pathways. However, more recent studies show significant interactions between these pathways by inducing the perception of motion (implied motion) from presenting the independent frames of static Glass patterns. The mechanisms behind such interaction are not adequately understood with studies showing a larger contribution of either a motion or form processing mechanism. In the current study, we adapted the equivalent noise paradigm to disentangle the effect of internal noise (local processing) and sampling efficiency (global processing) on global motion, global form, and the interaction of both on the perception of implied motion using physically equivalent stimuli. Six visually normal observers discriminated the direction or orientation of random dot kinematograms (RDK), static Glass patterns (Glass), and dynamic Glass patterns (dGlass) whose directions/orientations were determined by the means of normal distributions with a range of direction/orientation variances that served as external noise. Thresholds (τ) showed a consistent pattern across observers and external noise levels, where τGlass > τdGlass > τRDK. Nested model comparisons where the thresholds were related to the external noise, internal noise, and the sampling efficiency revealed that the difference in performance between the tasks was best described by the change in sampling efficiency with invariable internal noise. Our results showed that the higher thresholds for implied motion compared to real motion could be due to inefficient pooling of local dipole orientation cues at global processing stages involving motion mechanisms.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:01
Perception of Sound Waves
The pitch of a sound depends on the frequency and the pressure amplitude of the source. Two sounds of the same...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...