Related Experiment Video
Updated: Nov 4, 2025
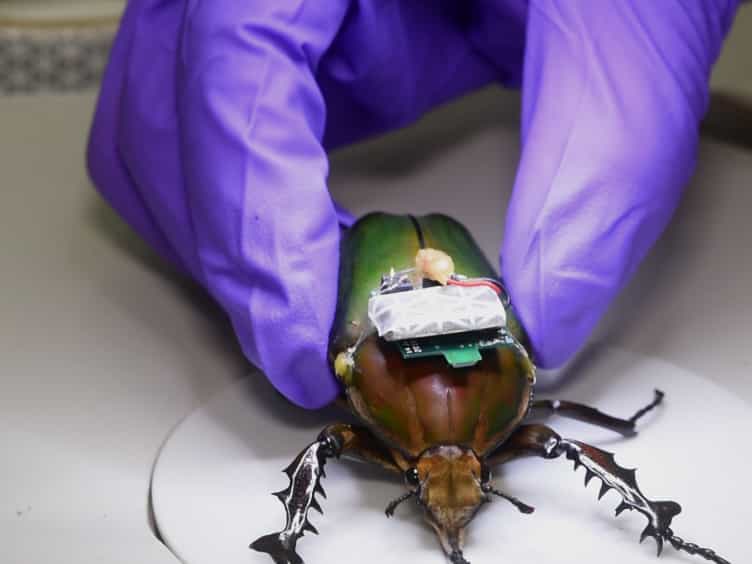

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
A controllable dual-catapult system inspired by the biomechanics of the dragonfly larvae's predatory strike
Sebastian Büsse1, Alexander Koehnsen2, Hamed Rajabi2
1Department of Functional Morphology and Biomechanics, Institute of Zoology, Kiel University, Am Botanischen Garten 9, 24118 Kiel, Germany. sbuesse@zoologie.uni-kiel.de.

Abstract:
The biomechanics underlying the predatory strike of dragonfly larvae is not yet understood. Dragonfly larvae are aquatic ambush predators, capturing their prey with a strongly modified extensible mouthpart. The current theory of hydraulic pressure being the driving force of the predatory strike can be refuted by our manipulation experiments and reinterpretation of former studies. Here, we report evidence for an independently loaded synchronized dual-catapult system. To power the ballistic movement of a single specialized mouthpart, two independently loaded springs simultaneously release and actuate two separate joints in a kinematic chain. Energy for the movement is stored by straining an elastic structure at each joint and, possibly, the surrounding cuticle, which is preloaded by muscle contraction. As a proof of concept, we developed a bioinspired robotic model resembling the morphology and functional principle of the extensible mouthpart. Understanding the biomechanics of the independently loaded synchronized dual-catapult system found in dragonfly larvae can be used to control the extension direction and, thereby, thrust vector of a power-modulated robotic system.
Related Concept Videos
 02:39
Predator-Prey Interactions
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...