Related Experiment Video
Updated: Nov 4, 2025
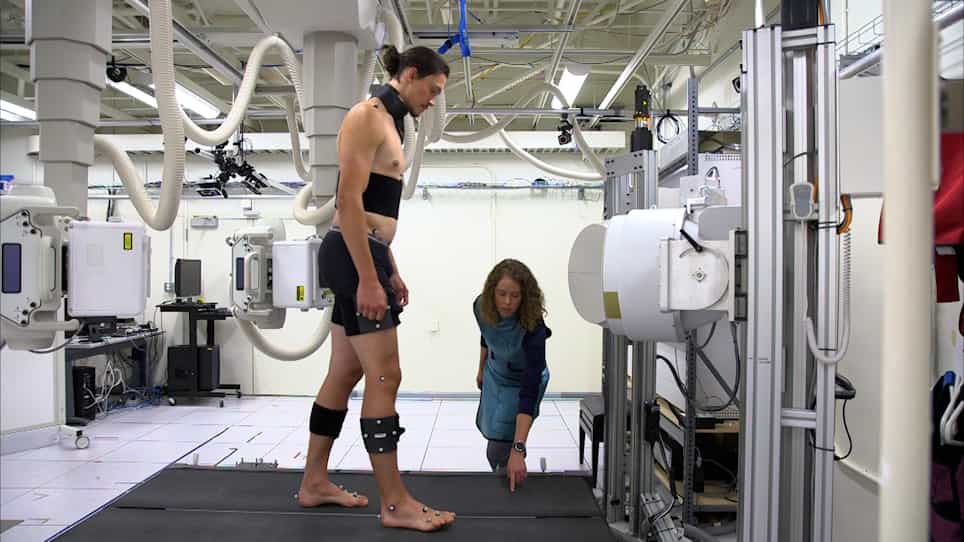

In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
A marker registration method to improve joint angles computed by constrained inverse kinematics
James J Dunne1,2, Thomas K Uchida3, Thor F Besier4
1Departments of Mechanical Engineering and Bioengineering, Stanford University, Stanford, California, United States of America.

Abstract:
Accurate computation of joint angles from optical marker data using inverse kinematics methods requires that the locations of markers on a model match the locations of experimental markers on participants. Marker registration is the process of positioning the model markers so that they match the locations of the experimental markers. Markers are typically registered using a graphical user interface (GUI), but this method is subjective and may introduce errors and uncertainty to the calculated joint angles and moments. In this investigation, we use OpenSim to isolate and quantify marker registration-based error from other sources of error by analyzing the gait of a bipedal humanoid robot for which segment geometry, mass properties, and joint angles are known. We then propose a marker registration method that is informed by the orientation of anatomical reference frames derived from surface-mounted optical markers as an alternative to user registration using a GUI. The proposed orientation registration method reduced the average root-mean-square error in both joint angles and joint moments by 67% compared to the user registration method, and eliminated variability among users. Our results show that a systematic method for marker registration that reduces subjective user input can make marker registration more accurate and repeatable.

Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...