Learning Actions From Natural Language Instructions Using an ON-World Embodied Cognitive Architecture
Related Experiment Video
Updated: Nov 4, 2025
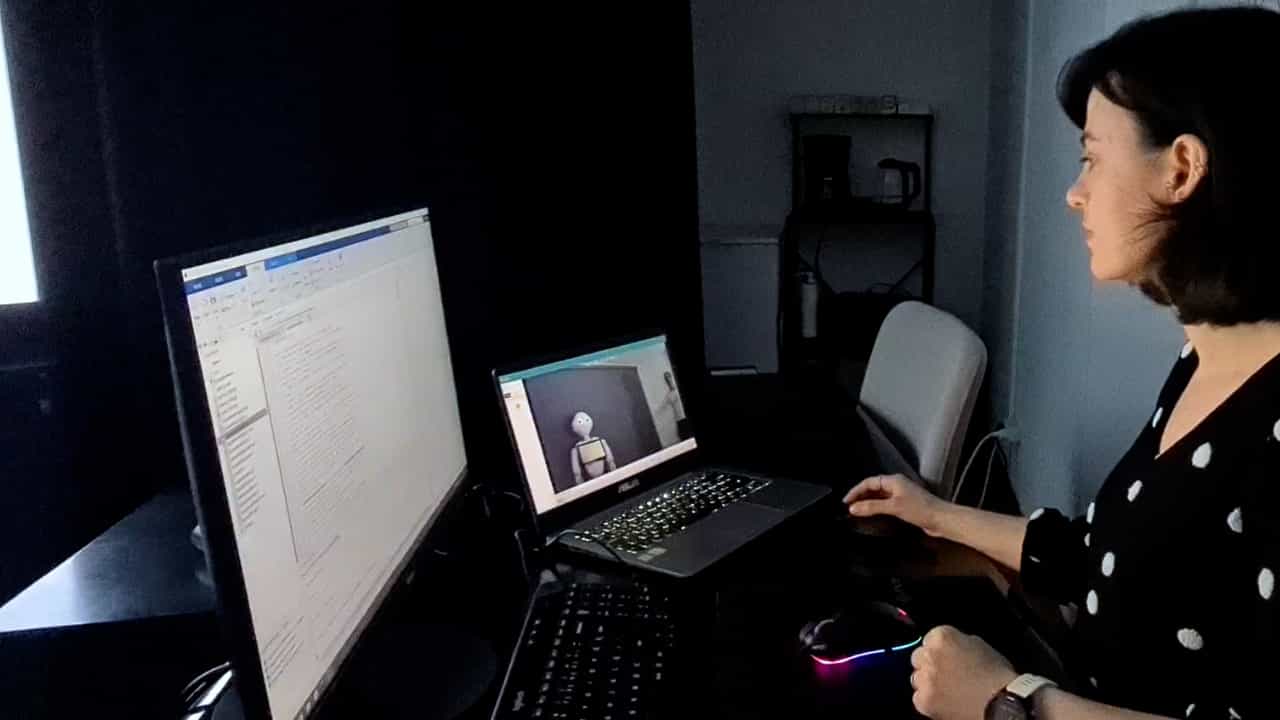
Author Spotlight: A Novel Setup to Conduct Naturalistic Laboratory Experiments with Real Human Actors in Scenarios
Published on: August 4, 2023
Ioanna Giorgi1, Angelo Cangelosi1, Giovanni L Masala2
1Department of Computer Science, The University of Manchester, Manchester, United Kingdom.

Abstract:
Endowing robots with the ability to view the world the way humans do, to understand natural language and to learn novel semantic meanings when they are deployed in the physical world, is a compelling problem. Another significant aspect is linking language to action, in particular, utterances involving abstract words, in artificial agents. In this work, we propose a novel methodology, using a brain-inspired architecture, to model an appropriate mapping of language with the percept and internal motor representation in humanoid robots. This research presents the first robotic instantiation of a complex architecture based on the Baddeley's Working Memory (WM) model. Our proposed method grants a scalable knowledge representation of verbal and non-verbal signals in the cognitive architecture, which supports incremental open-ended learning. Human spoken utterances about the workspace and the task are combined with the internal knowledge map of the robot to achieve task accomplishment goals. We train the robot to understand instructions involving higher-order (abstract) linguistic concepts of developmental complexity, which cannot be directly hooked in the physical world and are not pre-defined in the robot's static self-representation. Our proposed interactive learning method grants flexible run-time acquisition of novel linguistic forms and real-world information, without training the cognitive model anew. Hence, the robot can adapt to new workspaces that include novel objects and task outcomes. We assess the potential of the proposed methodology in verification experiments with a humanoid robot. The obtained results suggest robust capabilities of the model to link language bi-directionally with the physical environment and solve a variety of manipulation tasks, starting with limited knowledge and gradually learning from the run-time interaction with the tutor, past the pre-trained stage.
More Related Videos
 11:54
Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
 11:14
A Novel Experimental and Analytical Approach to the Multimodal Neural Decoding of Intent During Social Interaction in Freely-behaving Human Infants
Published on: October 4, 2015
Related Concept Videos
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:22
Purposive Learning
 01:12
Observational Learning
 01:18
Introduction to Learning
In contrast to learned behaviors, unlearned behaviors such as crying, sexual...
 01:27
Language and Cognition
 01:20
Introduction to Cognitive Psychology
This field emerged in the mid-20th century, following a period dominated by behaviorism, which...