Related Experiment Video
Updated: Nov 3, 2025


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Inertial Sensor-Based Step Length Estimation Model by Means of Principal Component Analysis
Melanija Vezočnik1, Roman Kamnik2, Matjaz B Juric1
1Faculty of Computer and Information Science, University of Ljubljana, Večna Pot 113, 1000 Ljubljana, Slovenia.

Abstract:
Inertial sensor-based step length estimation has become increasingly important with the emergence of pedestrian-dead-reckoning-based (PDR-based) indoor positioning. So far, many refined step length estimation models have been proposed to overcome the inaccuracy in estimating distance walked. Both the kinematics associated with the human body during walking and actual step lengths are rarely used in their derivation. Our paper presents a new step length estimation model that utilizes acceleration magnitude. To the best of our knowledge, we are the first to employ principal component analysis (PCA) to characterize the experimental data for the derivation of the model. These data were collected from anatomical landmarks on the human body during walking using a highly accurate optical measurement system. We evaluated the performance of the proposed model for four typical smartphone positions for long-term human walking and obtained promising results: the proposed model outperformed all acceleration-based models selected for the comparison producing an overall mean absolute stride length estimation error of 6.44 cm. The proposed model was also least affected by walking speed and smartphone position among acceleration-based models and is unaffected by smartphone orientation. Therefore, the proposed model can be used in the PDR-based indoor positioning with an important advantage that no special care regarding orientation is needed in attaching the smartphone to a particular body segment. All the sensory data acquired by smartphones that we utilized for evaluation are publicly available and include more than 10 h of walking measurements.
More Related Videos


Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:15
Kinematic Equations: Problem Solving
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
PI Controller: Design
 01:10
Relative Motion Analysis - Acceleration
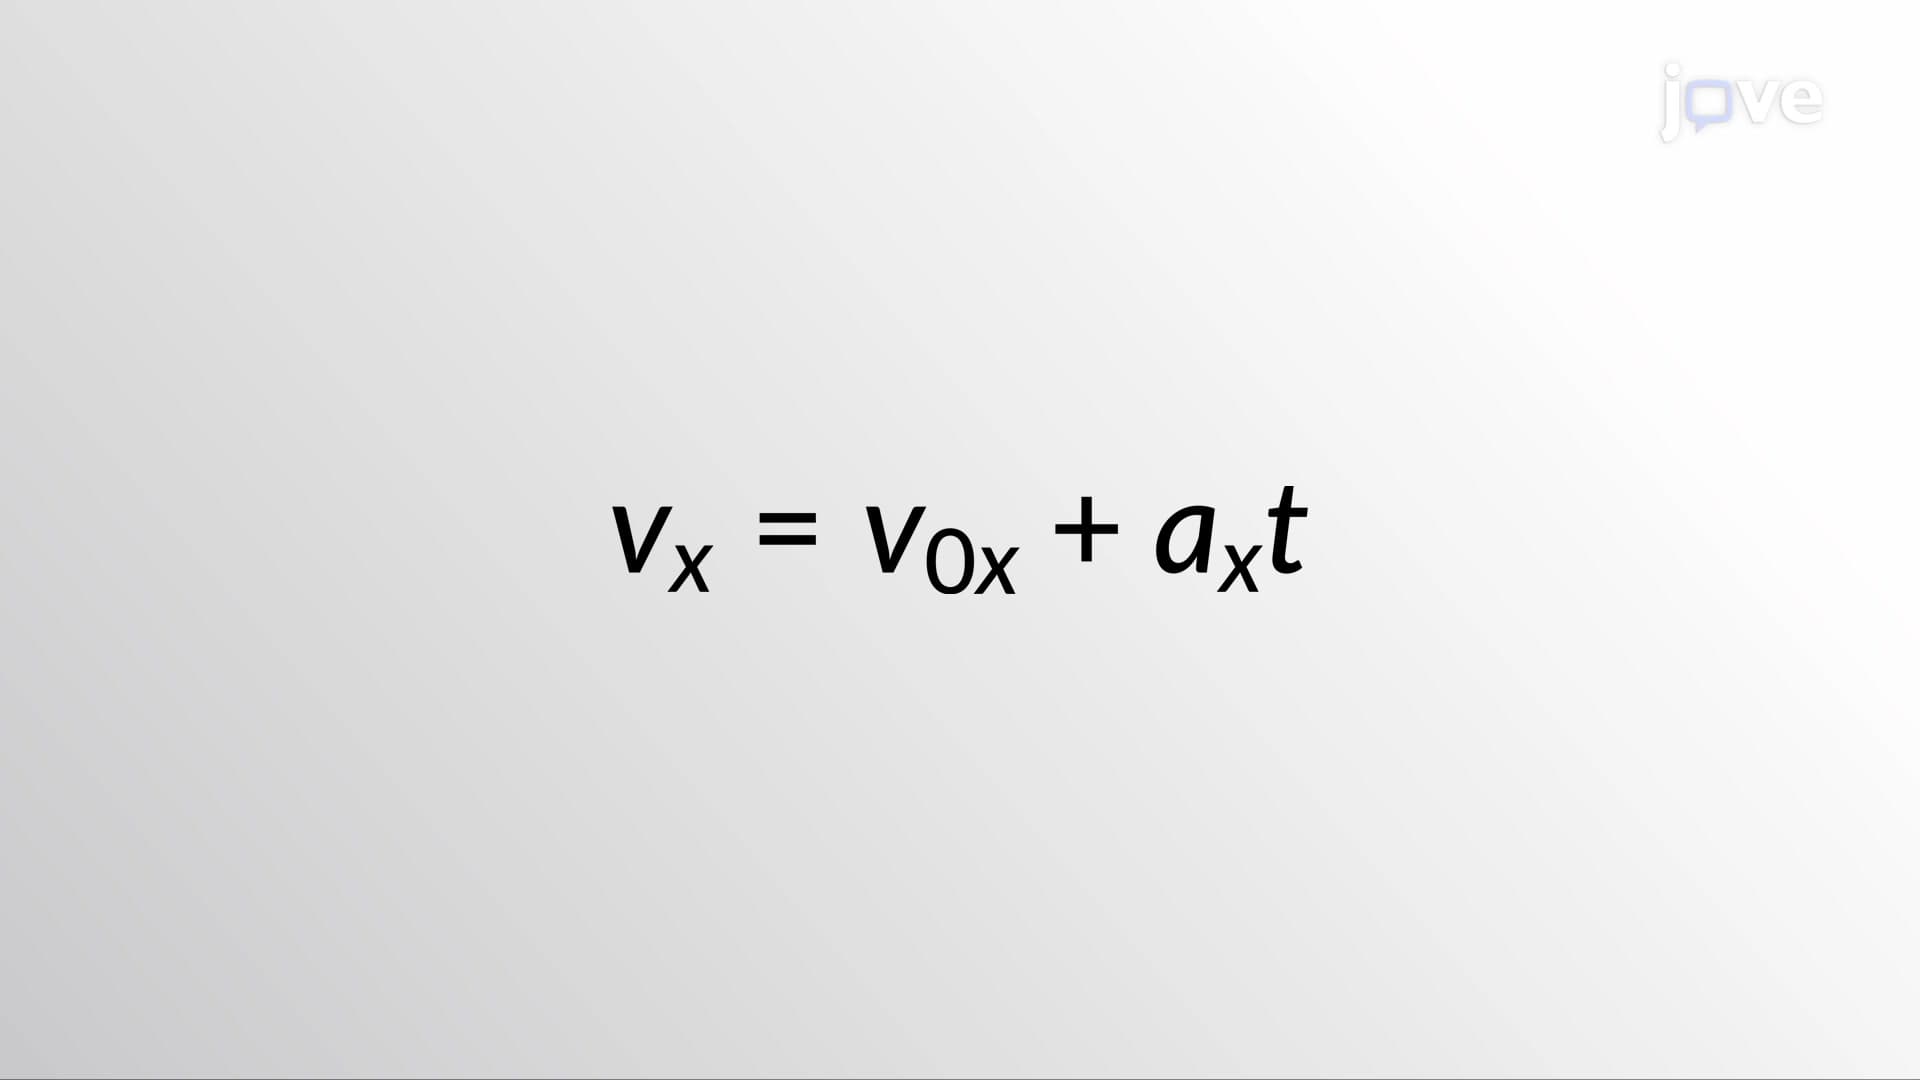 01:26
Kinematic Equations - I